
Advantech introduces UniCAM multi-camera integration on NVIDIA Jetson Thor
UniCAM combines cameras from different manufacturers on the AFE-A702 robot controller, with shared configuration and ROS 2 integration.
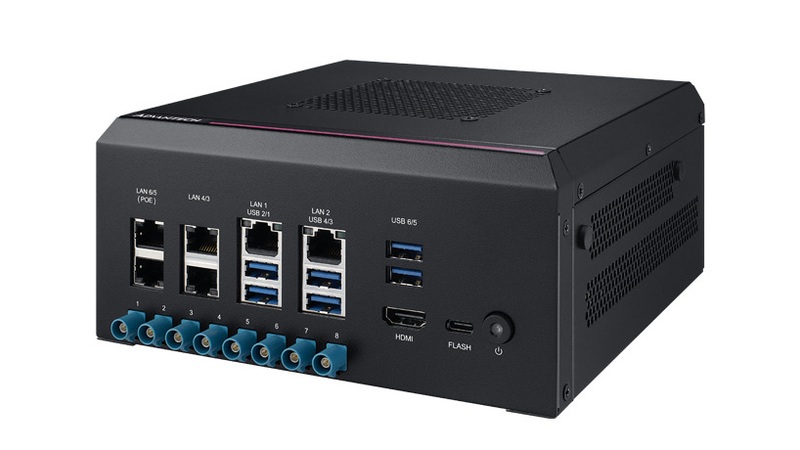
Advantech has introduced UniCAM, a GMSL2 camera-integration system running on its NVIDIA Jetson Thor-powered AFE-A702 robot controller. Presented at NVIDIA GTC Berlin on 20–22 October, the architecture lets robotics developers combine supported cameras from different manufacturers within a shared configuration and hardware-synchronisation system.
Multi-camera robots need image streams to arrive with consistent timing while serving different perception functions, such as depth measurement and object recognition. Camera vendors commonly supply their own drivers and low-level configurations. UniCAM centralises the management of camera settings and shared hardware resources, reducing repeated driver adaptation and Device Tree changes when developers combine sensors.
The GTC configuration brings together five models: Stereolabs ZED X and ZED X Nano, RealSense D457, Orbbec Gemini 335LG and Leopard Imaging LI-VENUS-ISX031-GMSL2. They cover stereo vision, depth sensing and 2D imaging. Advantech says the architecture preserves vendor SDKs, algorithms and camera functions while supporting NVIDIA Isaac ROS and the Argus camera framework.
Advantech Robotic Suite detects supported cameras and configures their device settings for ROS 2 applications. Initial support focuses on Jetson Thor; the roadmap extends to Jetson AGX Orin and Orin NX, followed by Intel IPU7 and Qualcomm Dragonwing IQ9. The AFE-A702 supplies the controller hardware for the initial implementation, combining compute with interfaces for cameras and other robot sensors.