AGIBOT launches Lingxi X1 developer humanoid and open-source roadmap
AGIBOT has introduced Lingxi X1, a compact humanoid developer platform, alongside the wheeled X1-W at its 18 August product event.
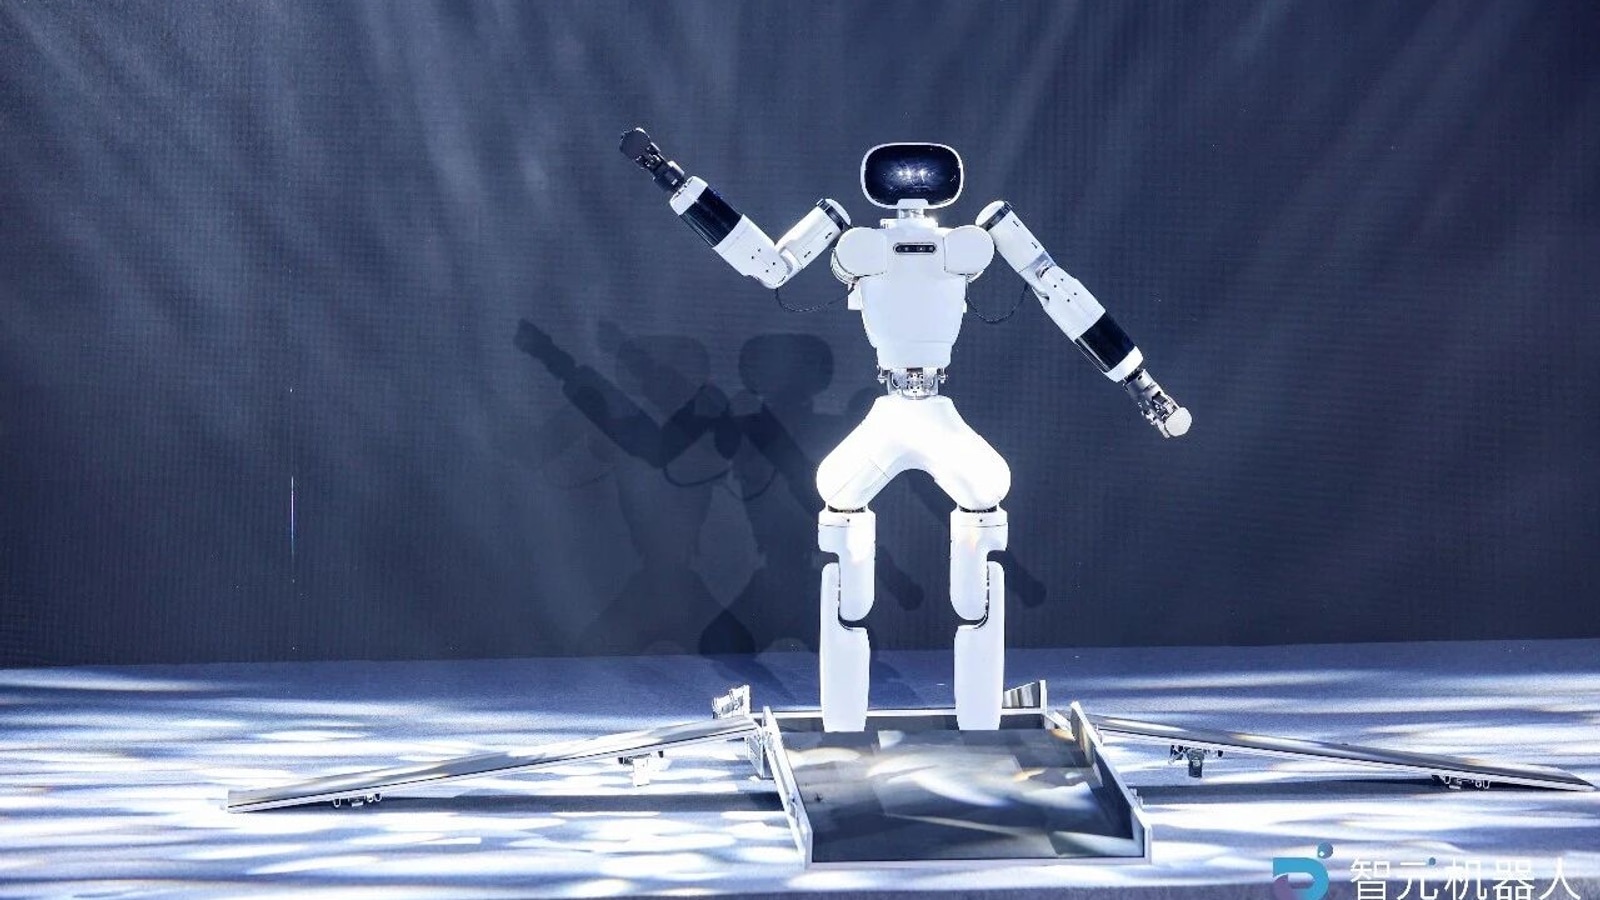
AGIBOT has introduced Lingxi X1, a compact humanoid developer platform, alongside the wheeled X1-W at its 18 August product event. Developed by the company’s X-Lab, X1 combines lightweight modular hardware with plans to release mechanical designs, middleware and basic motion-control software progressively from September.
The robot uses hybrid serial-parallel arms and differential shoulder joints, with each arm weighing 2.5 kg. Two modular PowerFlow joint designs support control of more than 30 degrees of freedom, while an adaptive gripper uses a single active degree of freedom to grasp differently shaped objects.
X1-W is aimed at lower-cost robot data collection. It sits within AGIBOT’s wider AIDEA programme, which links teleoperation and demonstrations to annotation, model training, evaluation and deployment.
AGIBOT also plans to open-source its ROS-compatible AimRT communications framework at the end of September. These are announced release plans: the launch does not establish that the complete X1 hardware and software stack was already publicly available.