
Allegro expands humanoid power and position sensing portfolio
The portfolio combines 48V power regulation with compact joint sensors, supported by a disclosed collaboration on Sarcomere’s Scorpion gripper.
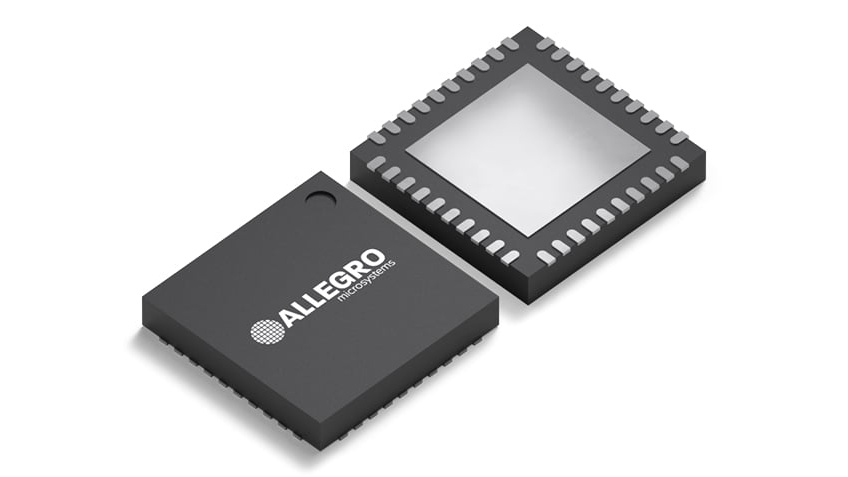
Allegro MicroSystems has expanded its humanoid robotics component portfolio with a 48V power-management chip and position sensors for large joints and dexterous hands. The 20 October announcement combines its A81481 power-management IC with A17802/A17803 inductive sensors, the CT310 tunnel-magnetoresistance sensor and the A33023 Hall-effect angle sensor.
The A81481 regulates power directly from a 48V bus. Its 6×6 mm package integrates two buck regulators, five low-dropout outputs and safety diagnostics, including a triple-watchdog architecture. Allegro says eliminating separate pre-regulators and consolidating those functions can reduce system footprint and bill-of-materials cost by roughly 50%.
Higher-voltage power distribution helps reduce cabling weight and resistive losses, while joint electronics still need lower, regulated supply voltages. Integrating the conversion and diagnostics is intended to save board space inside compact enclosures. The design draws on Allegro’s automotive power-control experience as the company adapts its components for robot architectures.
For shoulders, hips and knees, the A17802 and A17803 measure joint position while compensating for changing mechanical air gaps and rejecting stray magnetic fields. For smaller hands and fingers, the CT310 offers sub-degree accuracy in a 2×2 mm package. The A33023 combines angle sensing with low latency, digital output options and diagnostics for applications requiring functional-safety support.
Allegro also disclosed work with Sarcomere Dynamics to integrate its motion controllers, sensors and power ICs into the Scorpion gripper. The partners plan to extend that collaboration to ARTUS Dex, Sarcomere’s next-generation 24-degree-of-freedom robotic hand. The relationship gives the component portfolio an identified manipulation application, spanning power delivery, actuator control and position feedback within the same end effector.