
Bonsai Robotics launches Bonsai World simulation for outdoor autonomy
Satellite imagery becomes 3D training environments in a simulation system built around Bonsai’s farm-machinery data and mixed-fleet autonomy platform.
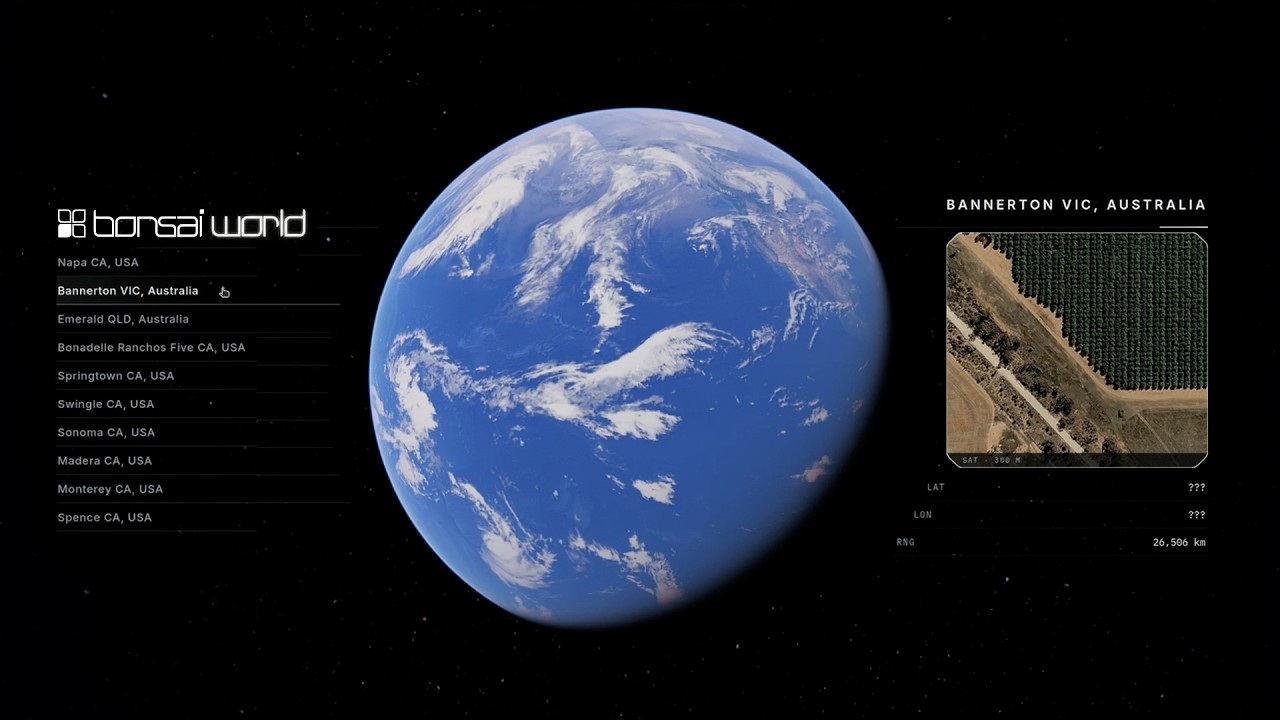
Bonsai Robotics introduced Bonsai World on 2 October 2026, adding simulation and world modelling to its autonomy software for agricultural and other off-road machines. The system converts satellite imagery into structured 3D environments and generates ground-level views for training and evaluation before equipment reaches a site. It can introduce dust, debris, animals, vehicles and terrain changes to test conditions absent from a machine’s recorded experience.
The application sits within Bonsai Intelligence, which controls the company’s Amiga robots and retrofitted equipment from other manufacturers. Bonsai reports more than 50 million real-world samples collected across over one million acres. Gemini interprets satellite imagery, while the world model builds on NVIDIA Cosmos and Bonsai’s own field data; Google Cloud A2 instances with NVIDIA A100 GPUs support training, and G4 instances with RTX PRO 6000 Blackwell GPUs run inference and environment generation.
Bonsai’s March technical account of its autonomy stack described semantic occupancy and elevation mapping to distinguish traversable brush from obstacles and assess slopes for different machines. Its vision-language-action work addresses vehicle movement and implement control together, including positioning hydraulic tree-shaker arms around trunks and irrigation equipment. That combination requires models to interpret contact, terrain and visibility as well as navigate a route.
The hardware base broadened through Bonsai’s July 2025 acquisition of farm-ng, bringing the modular Amiga platform into the business alongside its retrofit software. In February 2026, Amiga weeding and spraying integrations included WEED-IT, OnTarget Spray Systems and Interlink Sprayers, plus an Amiga Max carrying Carbon Robotics’ LaserWeeder for field demonstrations. Existing OMC and Flory orchard integrations provide additional machine types for the shared autonomy platform.