
CoreWeave launches ready-to-run robotics and autonomy simulation workloads
Physical AI Launchables packages tested environments for simulation, synthetic data, evaluation and robot-policy training.
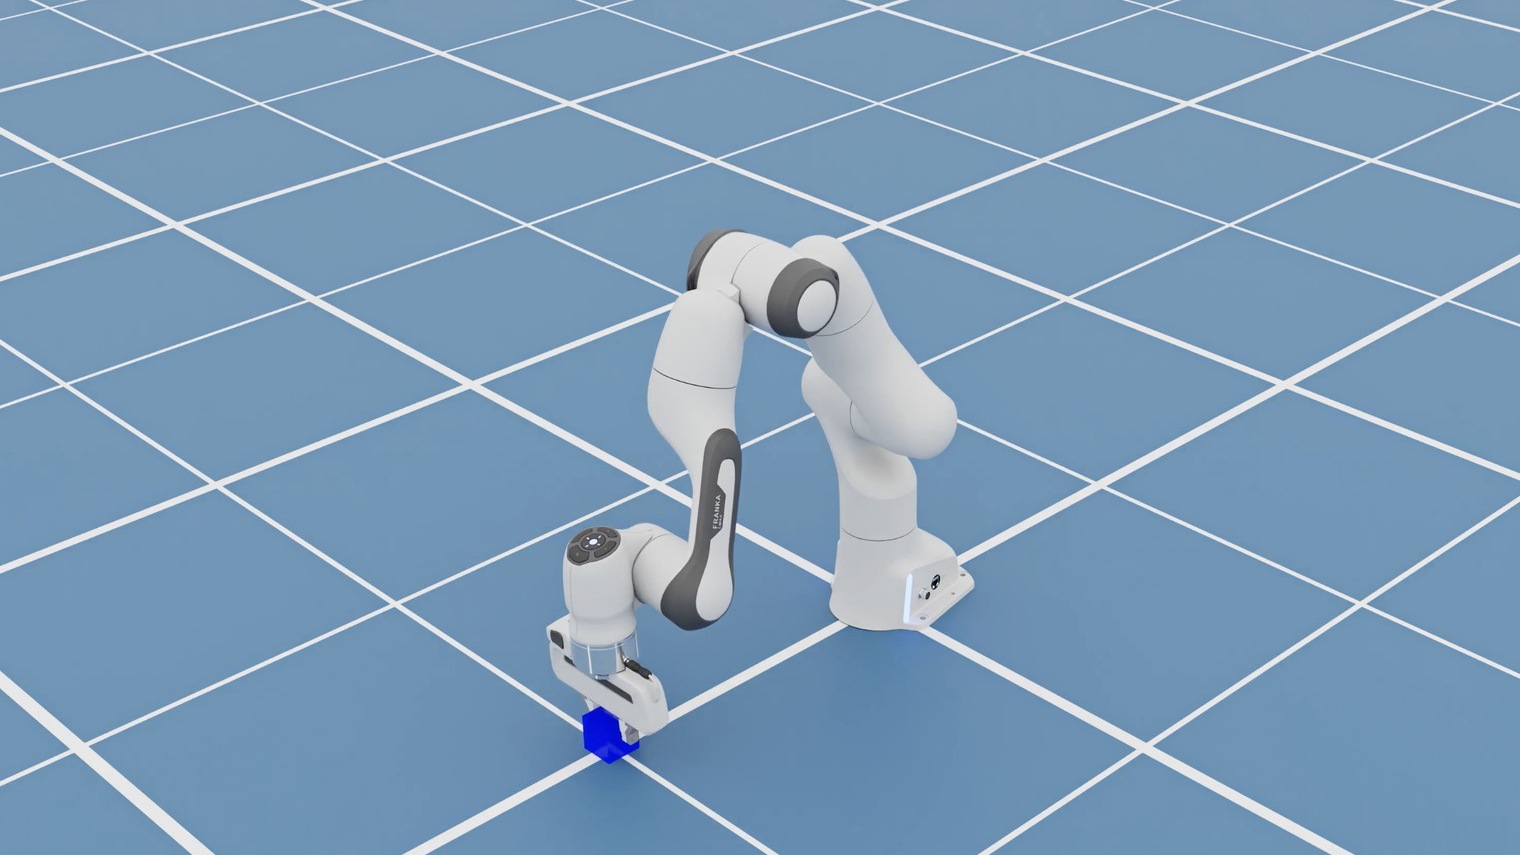
CoreWeave has launched Physical AI Launchables, a catalogue of tested workload templates for robotics, autonomous vehicles and simulation. Announced at NVIDIA GTC Berlin on 21 October, the service packages development environments, execution commands and output collection so teams can run experiments on CoreWeave infrastructure using their own scenes, data and models.
The initial catalogue covers NVIDIA Isaac Sim, CARLA, MuJoCo, NVIDIA AlpaSim and NVIDIA Cosmos 3. Templates include Franka-arm pick-and-place, labelled warehouse scenes, vehicle dynamics, driving-scenario evaluation and GPU-parallel reinforcement learning. Each tool also has a blank template that supplies the tested environment for a developer's own workload.
CoreWeave's implementation guide shows how teams can change scene settings, scenarios, duration, parallelism and the model under test. More substantial changes can be made in the template's application code. The company demonstrates variations of a pick-and-place scene involving camera position, lighting, payload weight, placement targets and robot embodiment.
Templates declare their resource needs and return reports, metrics, media and diagnostics through a common interface. Execution status is recorded separately from evaluation results, allowing a workflow to distinguish a completed computing job from a policy that met its task criteria. Where a workload permits, CPU preparation and post-processing are separated from the GPU stage to limit the time accelerated capacity remains allocated.
The launch includes skills for coding agents such as Claude Code and Codex to submit jobs, monitor progress and inspect results. Cosmos Data Factory skills add video, image and text augmentation, automatic labelling, curation and retrieval. These tools extend CoreWeave's cloud offering into the repeated simulation-and-evaluation work used to develop robot and autonomous-driving models.