
NVIDIA releases Isaac GR00T N1 open humanoid foundation model
NVIDIA introduced Isaac GR00T N1 on 18 March 2025 as a customizable foundation model for humanoid robot control and manipulation, releasing a two-billion-parameter model alongside developer materials.
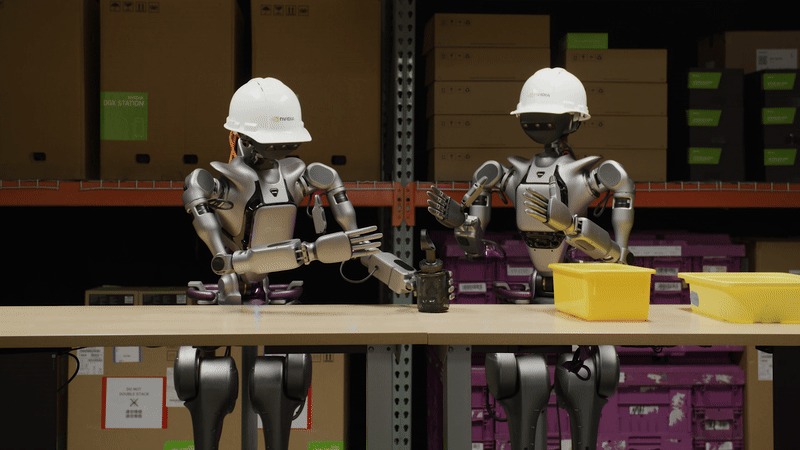
NVIDIA introduced Isaac GR00T N1 on 18 March 2025 as a customizable foundation model for humanoid robot control and manipulation, releasing a two-billion-parameter model alongside developer materials. Its dual-system design used a vision-language component for interpreting tasks and a diffusion-transformer component for producing robot actions. NVIDIA demonstrated object handling and coordinated dual-arm behaviours on platforms including Fourier GR-1 and 1X NEO.
Training combines teleoperated robot demonstrations, internet video and synthetic trajectories generated in simulation. The released weights can be adapted to a robot’s embodiment and tasks through post-training. Across NVIDIA’s three simulation evaluation suites using 100 demonstrations per task, GR00T N1 achieved an average 45.0% success rate, compared with 33.4% for the Diffusion Policy baseline; these figures describe the reported benchmark configuration.
NVIDIA also released supporting development tools and sample data within its Isaac robotics stack. Alongside the model, it announced work with Google DeepMind and Disney Research on Newton, a physics engine intended to improve robot simulation and learning. The combination connects pretrained robot policies with tools for generating training experience and adapting behaviours before testing on physical hardware.