
Sharpa publishes 300-hour SharpaDex tactile manipulation dataset
SharpaDex v1.0 provides synchronised vision, fingertip tactile signals and language annotations for bimanual robot learning.
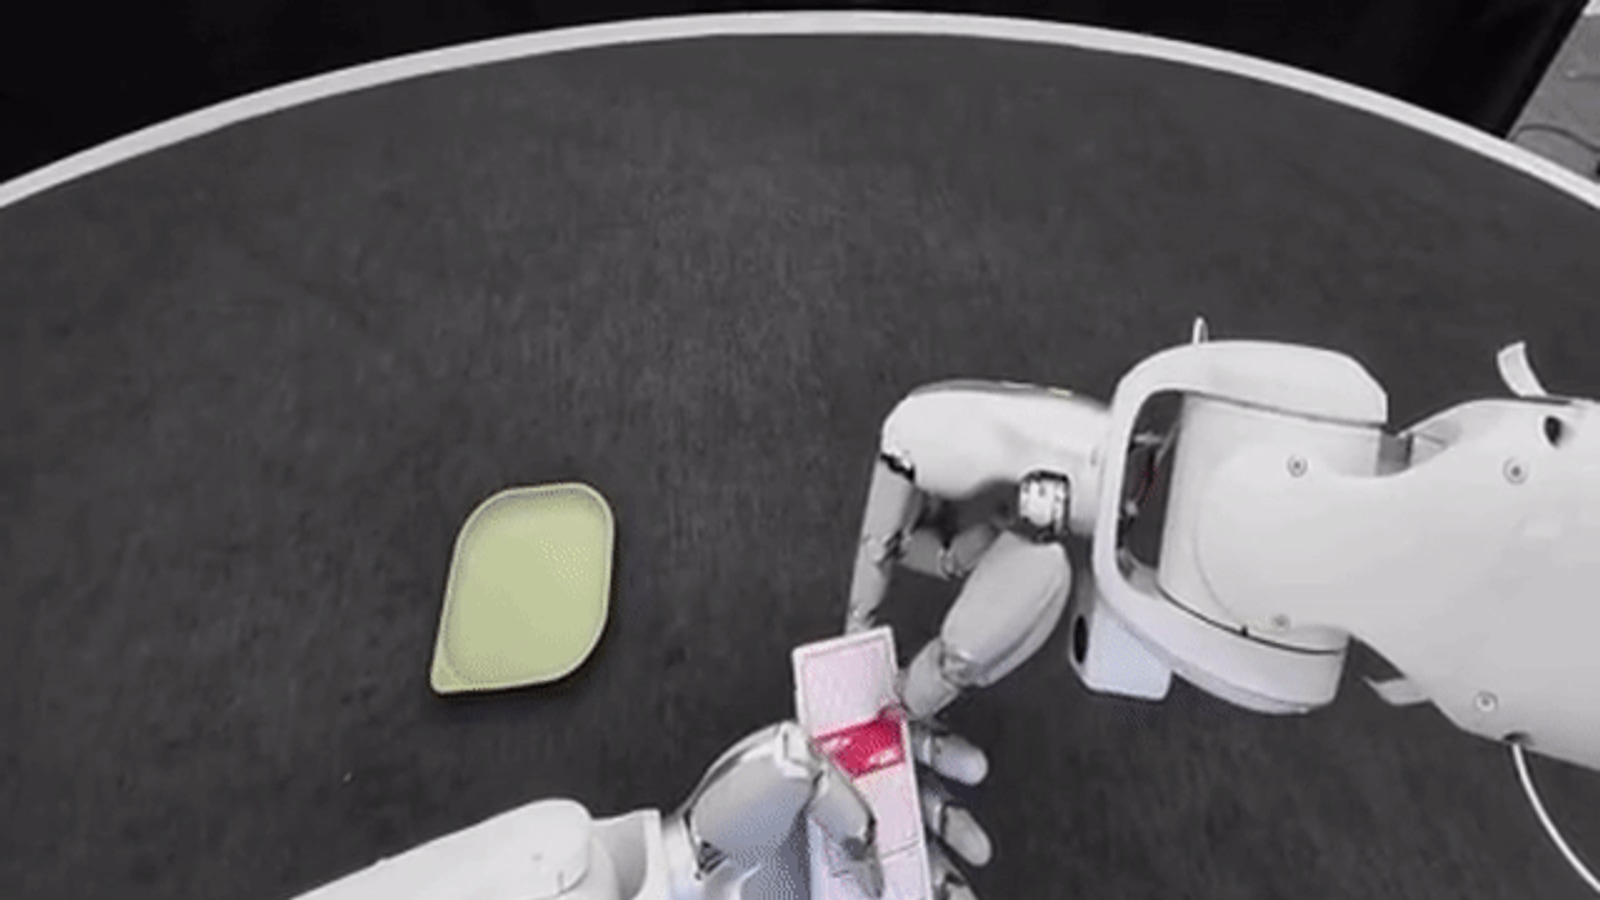
Sharpa has made SharpaDex v1.0 available on Hugging Face, providing approximately 300 hours of real-robot demonstrations across 59 manipulation tasks. Its late-September release contains 28,993 episodes and more than 32 million frames recorded at 30 frames per second. The tasks cover assembly, tools, packaging, cleaning and deformable objects using two arms and dexterous hands.
The collection system uses two seven-degree-of-freedom arms, two 22-degree-of-freedom hands and four RGB cameras. Episodes synchronise robot states, actions and torque with camera streams and tactile observations from ten fingertips. Numeric force and torque signals are accompanied by tactile video, enabling policies to learn from contact alongside visual information.
The 30 September repository snapshot organises recordings into 495 collection sessions and provides both LeRobot v3.0 and v2.1 exports. Global task descriptions and frame-aligned subtask annotations support language-conditioned and hierarchical learning. The dataset includes 45 skill labels, with complete trajectories available for studying the sequence of actions needed to finish a task.
The release follows Sharpa’s September introduction of D01, W02 and AE01 at IROS. Those products address robot execution, tactile manipulation and operator demonstration capture respectively. SharpaDex supplies a public training collection alongside that hardware programme, allowing developers to inspect synchronised visual, action and contact data across a wider range of manipulation tasks.