
Tangent introduces TR02 three-finger hand for tactile manipulation
A third finger and a usable palm extend Tangent’s fingertip-tracking architecture into stable power grasps and in-hand manipulation.
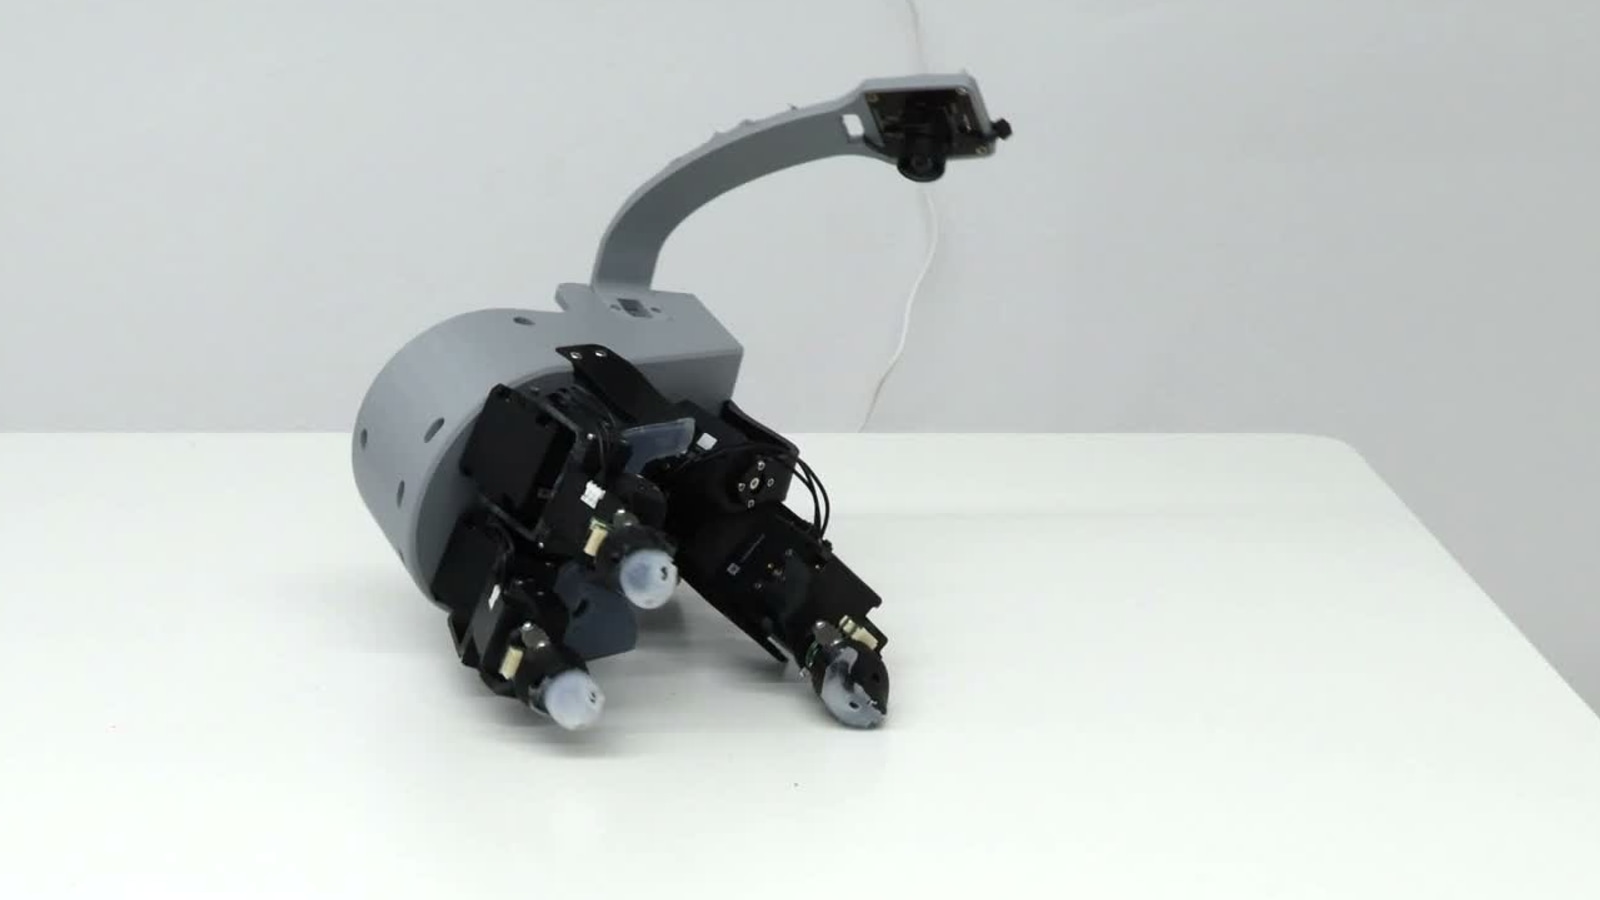
Tangent Robotics has introduced TR02, a three-finger robotic hand with 10 degrees of freedom, integrated tactile sensing and a palm designed to support larger objects. Presented in June 2026, the hand extends the company’s two-finger TR01 architecture with more stable grasps, object repositioning within the hand and transitions between fingertip and enveloping grasps.
TR02 assigns four degrees of freedom to the thumb and three each to the index and middle fingers. Its seven-degree-of-freedom thumb-index chain is designed to reproduce a human operator’s relative fingertip position and orientation. Tracking of the middle finger receives a lower weight, allowing it to stabilise an object while the thumb and index perform the more precise manipulation. The palm provides another contact surface when the fingers draw an object inward.
Three Popcorn sensors, one on each fingertip, and an offset palm camera supply observations for policies trained from teleoperation. Tangent’s April sensor work places optical force sensing at the base of the fingertip, allowing contact information to be collected across its surface. TR02 retains this sensing approach while increasing the number of independent contacts available during a grasp.
The launch follows Tangent’s May demonstrations of autonomous TR01 skills, including component assembly and object manipulation. Those diffusion policies used transformer backbones running at 15 Hz, vision at 15 Hz and tactile inputs at 240 Hz. Each task used 30–40 complete teleoperated demonstrations plus a similar number of shorter corrective examples. Tangent planned to begin evaluating learned TR02 manipulation policies in the weeks after the hardware introduction.