WUJI demonstrates sim-to-real pen spinning and glove control on Hand 2
A simulation-trained reinforcement-learning policy spins a tracked pen on WUJI Hand 2, alongside human-guided manipulation through WUJI Glove.
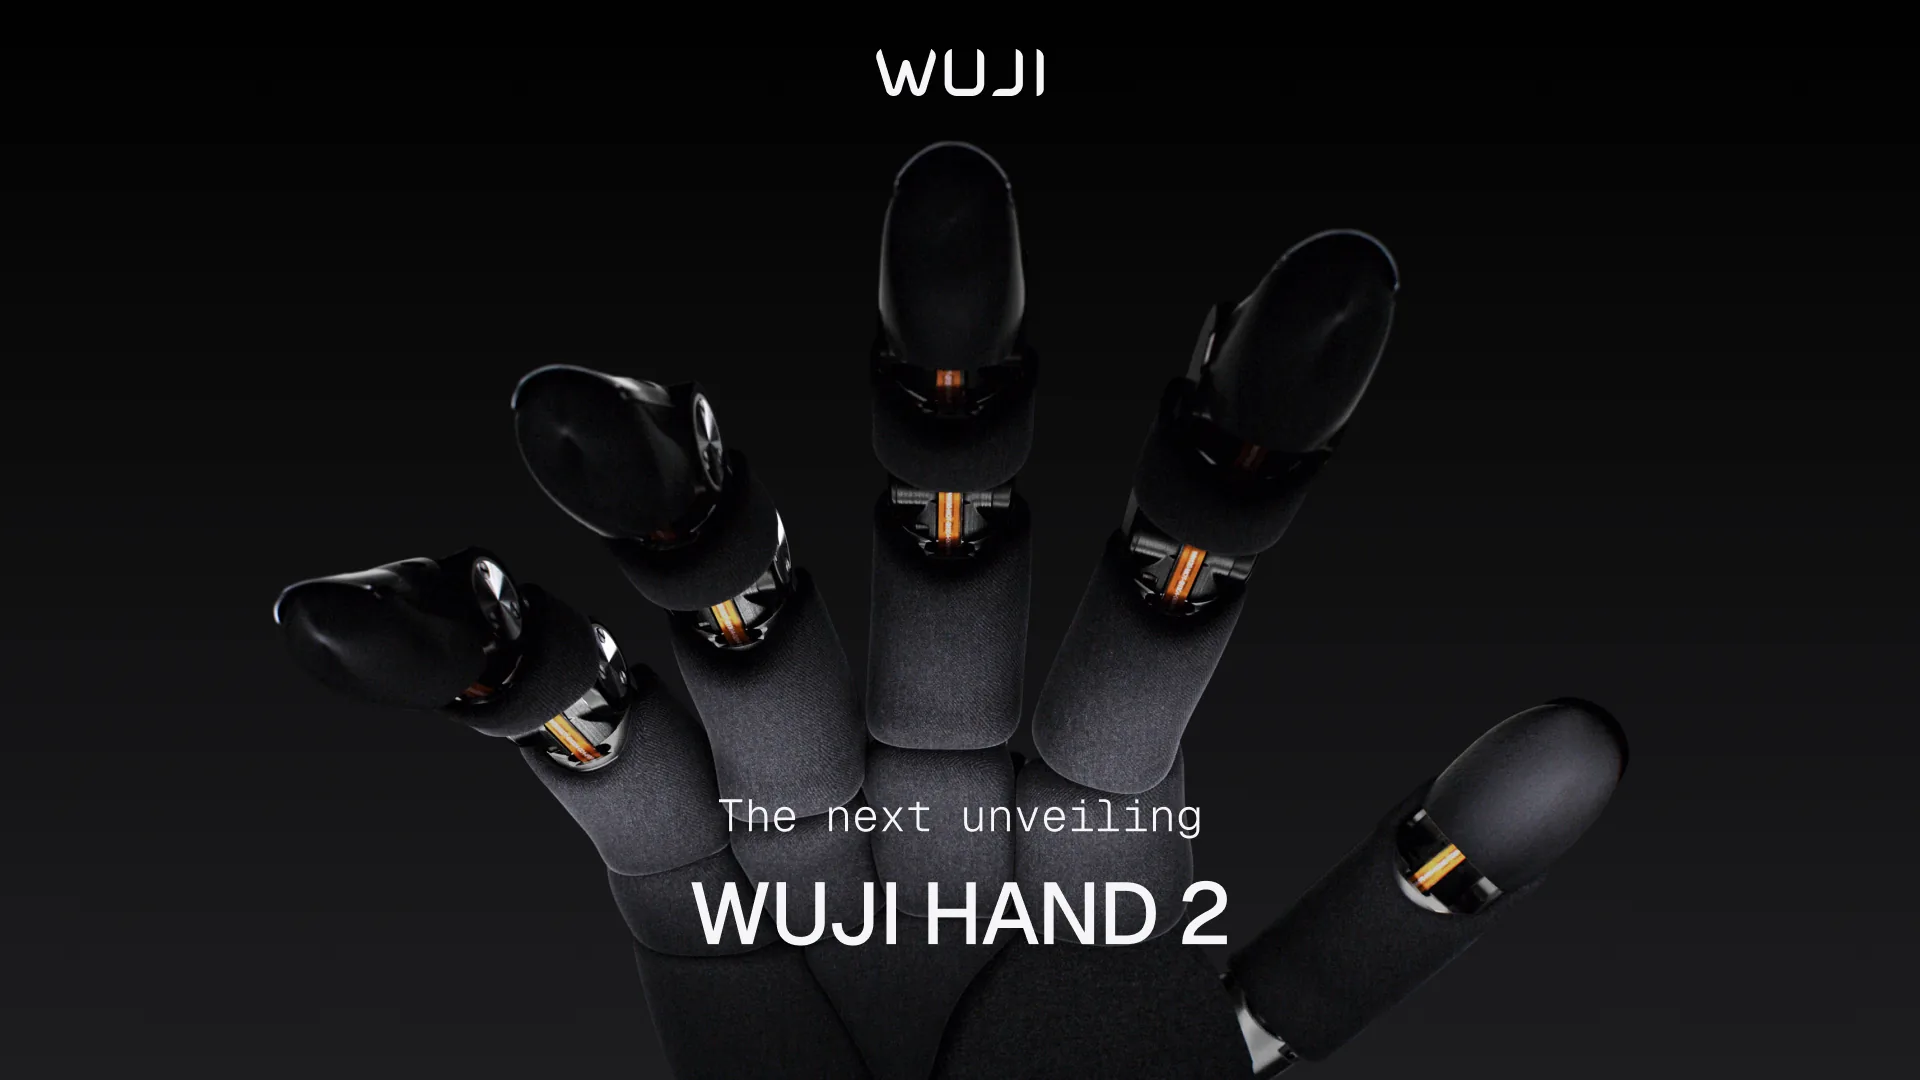
Shenzhen-based WUJI Technology has demonstrated a reinforcement-learning policy trained in simulation performing pen spinning on its 20-degree-of-freedom Hand 2, alongside a separate glove-based teleoperation system shown around IROS 2026. The WUJI MJLab release provides training code, motion data and deployment tools for in-hand manipulation, including 40 reference clips divided into five pen-spinning groups covering single-axis and continuous multi-axis rotation. The policy is trained with PPO using MuJoCo-based simulation and transferred to the physical robotic hand.
The real-world setup uses a specially constructed 250 mm pen with visual markers, an external industrial camera and a wrist reference marker to estimate object position. The trained policy runs closed-loop at 50 Hz, updating finger commands based on observed motion; this is not an uninstrumented demonstration relying solely on fingertip sensing. Hand 2 has 20 independently actuated joints, four per finger, with back-drivable direct-drive rotary mechanisms and a separate hardware control rate of up to 1,000 Hz. WUJI's product specification also lists hybrid force-position control and support for ROS 2, MuJoCo and Isaac Sim.
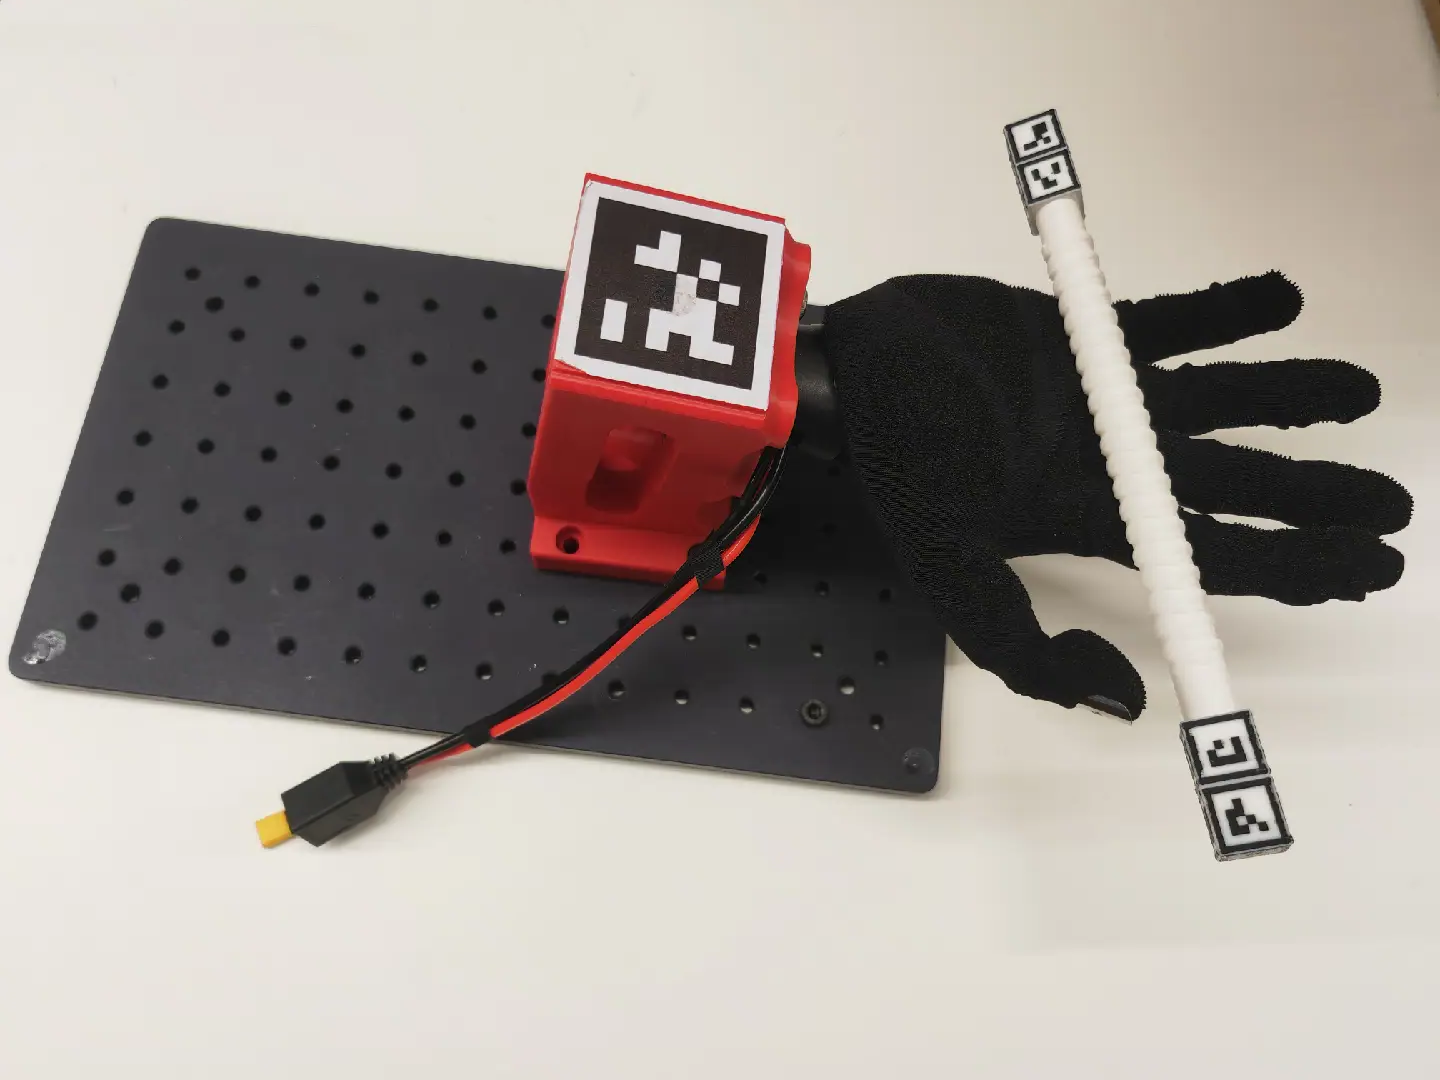
WUJI Glove offers another control pathway: five electromagnetic fingertip trackers capture an operator's hand pose at 120 Hz for mapping onto robotic joints, while 526 palm pressure points record human contact for manipulation-data collection. These human-guided demonstrations are distinct from the autonomous pen-spinning policy, and glove pressure sensing does not itself establish closed-loop robot grasp-force regulation. The open-source MJLab repository includes pretrained policies, motion clips and printable pen hardware under Apache 2.0, providing a reproducible test environment for researchers working on dexterous manipulation.