
Verified Events
DateTypeCompanyHeadlineSegment
Sharpa coauthors Embodied Playground long-horizon robotics benchmark
- The suites cover launching, Tower of Hanoi, interlocking assembly, cube manipulation and household tasks.
- EP-Easy and EP-Hard each contain 50 tasks; EP-20 provides a compact diagnostic subset.
- The released environment SDK supports MuJoCo, Isaac Lab and ManiSkill with declared observation/tool-access levels.
Industrial Next study evaluates WUJI HAND 2 conveyor pick-and-sort
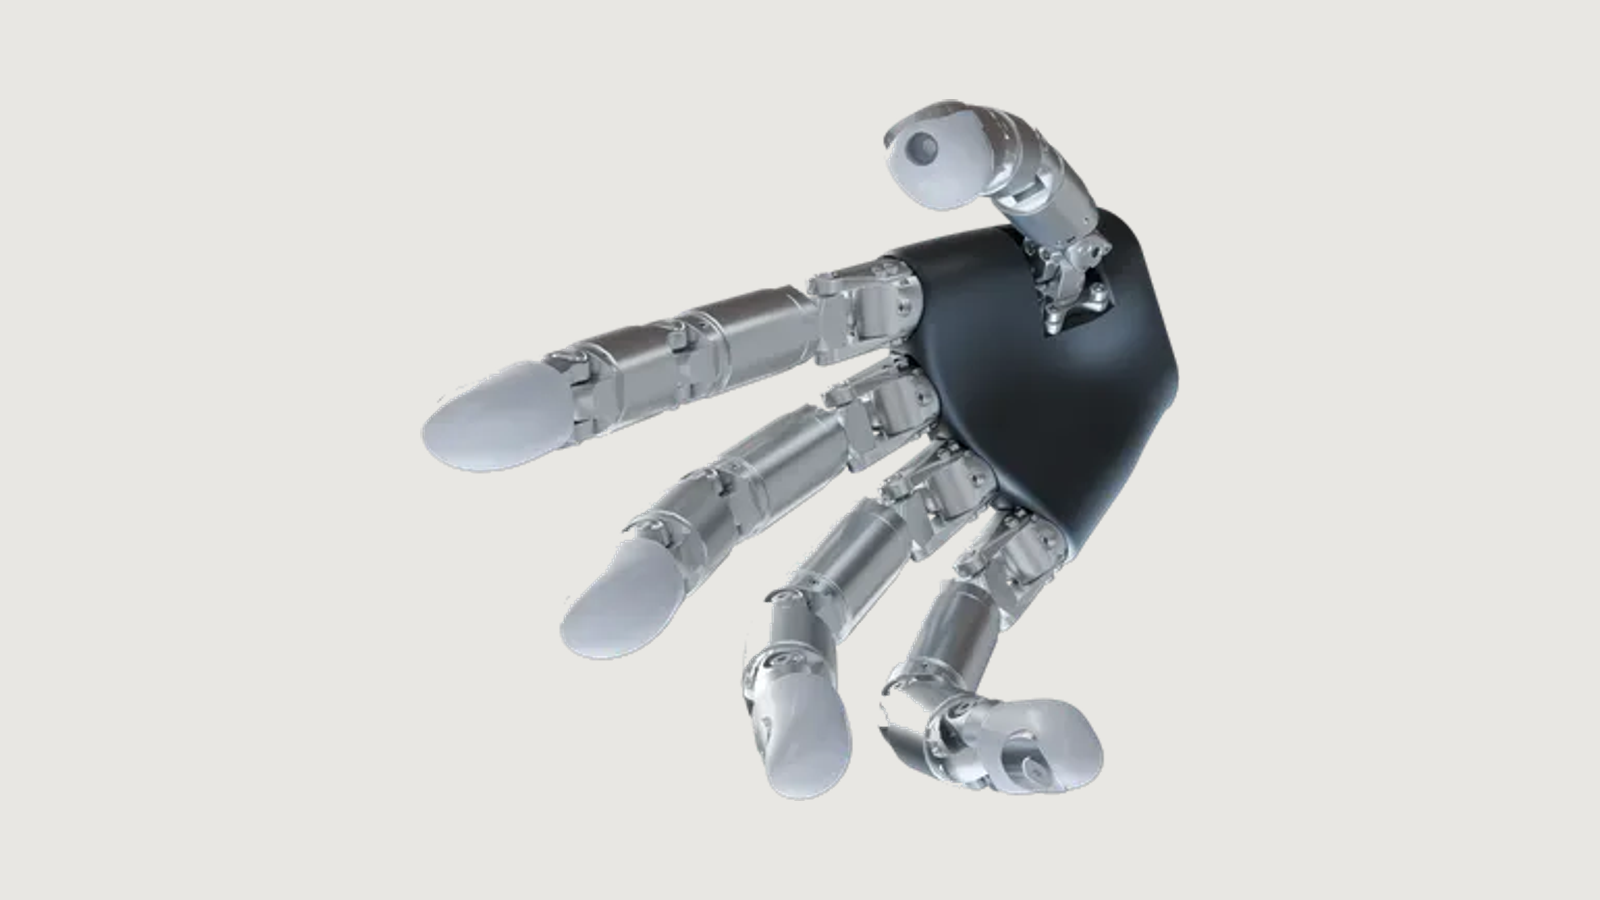
- Wuji Hand 2 performs pick-and-place color sorting from a moving conveyor using the right Flexiv Rizon 4S arm; the static left arm supplies another camera view.
- The 500M flow-matching policy succeeds in 26 of 50 real-only trials and 43 of 50 trials after co-training with 100 real and approximately 1,500 grounded simulated trajectories.
- Researchers teleoperate Hand 2 fingers with a Manus glove and map Vive-tracked wrist motion to the arm during real demonstration collection.
WUJI HAND 2 gains open-source cube-reorientation and pen-spinning tools
- Hand 2 cube reorientation includes standard and 50 Hz tasks, with separate hardware mounting and deployment configurations.
- Reference-tracking pen spinning includes 40 motion clips, five recipes and five matched pretrained checkpoint sets.
- The release bundles ONNX policies, hand mounting jigs, cube and pen CAD files, assembly drawings and tag assets.
Sharpa Wave completes autonomous cube solves in UC San Diego’s FINGR study
- FINGR achieved 297 successful layer turns out of 300 attempts, compared with 79.7% success for the base flow policy.
- The Sharpa Wave and xArm7 system demonstrated dexterous manipulation by solving all ten scrambled 2×2×2 cubes in approximately 137 seconds on average, including pickup, table-supported changes of grasp and final placement.
- The released dataset contains 36 operator-recorded sequences and 576 turns, with tactile measurements, joint states, tracked cube geometry and turn annotations.