
Viam BoxBot
About
About Viam BoxBot
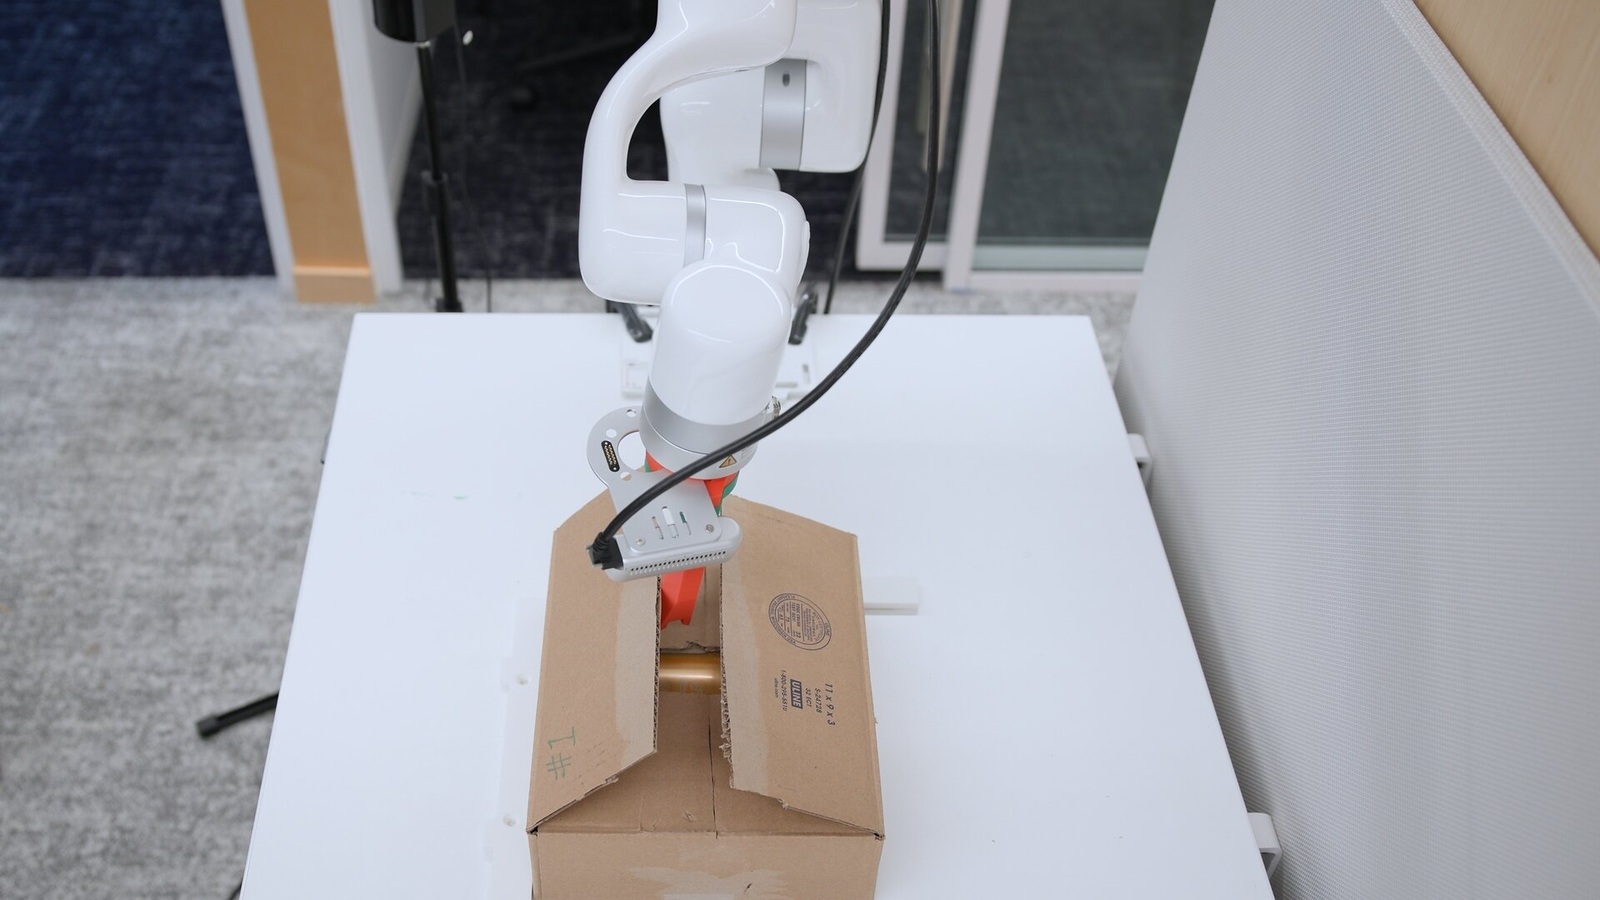
Viam BoxBot is an ongoing manipulation research project built around a robot arm. Image-based visual servoing guides a cutting tool along narrow tape seams, while a fine-tuned SmolVLA policy handles the contact-rich task of opening and adjusting box flaps.
Viam reports collecting 125 teleoperated demonstrations in about five hours over four days. The policy runs locally on a Jetson Orin Nano, and the implementation, model and dataset are available through Viam’s Hugging Face organization.
Capabilities
Source-backed capabilities
- Remote and shared control
Demonstrated - 2026-09-22 - Two engineers collected 125 teleoperated demonstrations in about five hours over four days using a VR controller.
Source
Research
- BoxBot SmolVLA Box-Opening Policy
2026-09-22 - Research Publication - Open VLA policy and demonstrations for BoxBot’s flap-opening stage.
Source
Timeline
- Viam unveils BoxBot open box-manipulation research system
2026-09-22 - Demonstration - Two engineers collected 125 teleoperated demonstrations in about five hours over four days using a VR controller. The learned flap-opening policy runs locally on an NVIDIA Jetson Orin Nano, while tape cutting uses image-based visual servoing. Viam published the model and dataset on Hugging Face for reproduction and benchmarking.
Source