
Aether AI
About
About Aether AI
Aether AI develops an intelligence layer that represents physical state, actions, mechanisms and consequences explicitly. Founded by causal-discovery researcher Biwei Huang and based in San Diego, its initial focus is Physical AI and robotics. Its models are intended to support reasoning under interventions and recovery when observed outcomes differ from predictions. The broader company also discusses scientific applications, which do not by themselves establish deployed robotics capabilities.
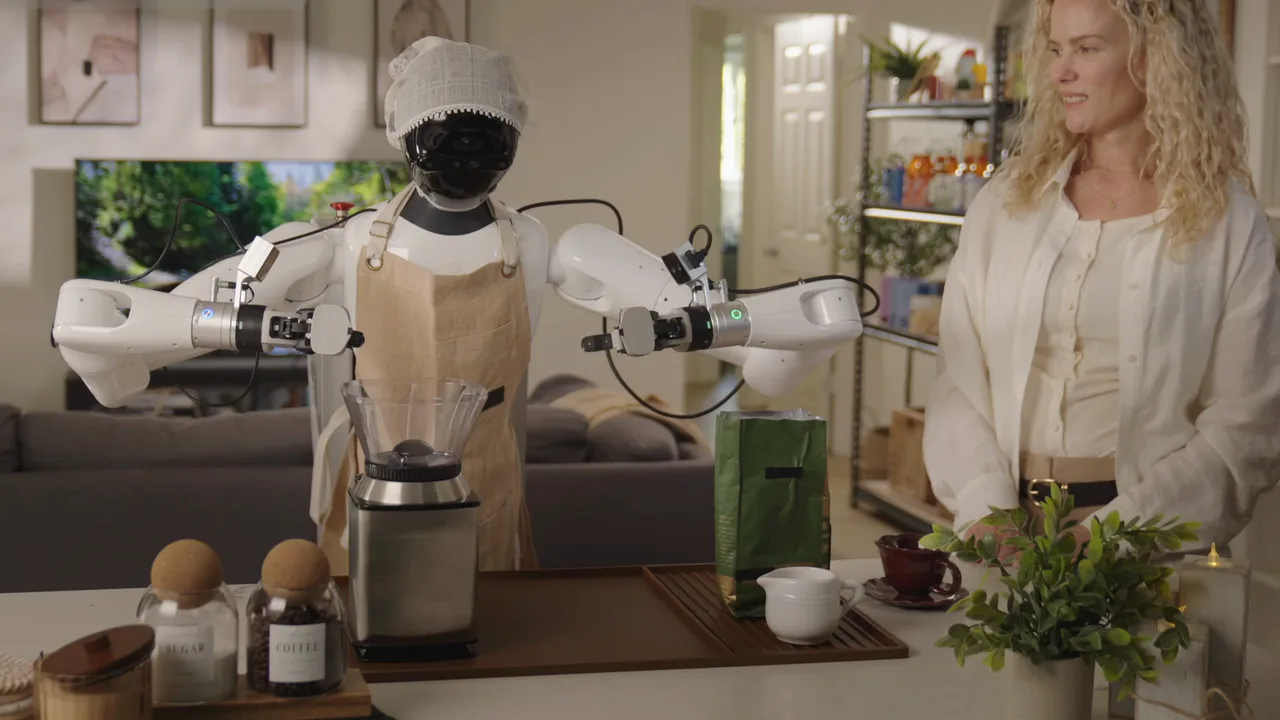
CausalWM predicts intermediate motion and geometry before generating future video. CRIS-0 adds a robot agent that decomposes a small set of demonstrations into verifiable stages and coordinates navigation, rule-based tools, learned policies and world-model predictions. The October 2026 technical release shows physical household-task demonstrations and disturbance recovery. The exact robot model is not identified, and these research demonstrations do not establish commercial deployment. Aether previously disclosed a $20 million seed financing for research, infrastructure, hiring and initial commercialization.
Articles
Funding
- 2026-06-18 - Seed - $20M - Aether AI raises $20M seed for causal world models
Aether AI raised a $20 million seed round to develop causal world models for physical-AI and robotics applications. - source: thesaasnews.com
Investors
- Inno Angel Fund - Participant - VC - 1 funding event - first seen 2026-06-18
- MPCi - Lead - Unknown - 1 funding event - first seen 2026-06-18
- SWC Global - Participant - VC - 1 funding event - first seen 2026-06-18
- Unity Ventures - Participant - VC - 1 funding event - first seen 2026-06-18
Team
- Biwei Huang - Founder - Her causality research background underpins Aether AI’s causal world-model approach for physical AI.
Research
- Aether AI introduces CausalWM embodied causal world model
2026-09-19 - Research Publication - Aether reports a 66.04 TWB score on TriWorldBench and top robot-domain performance on PAI-Bench. The training approach combines video pretraining, causal chain-of-thought mid-training and reinforcement-learning post-training.
Source
Timeline
Events
- 2026-10-08 - Demonstration - Aether AI demonstrates CRIS-0 causal robotic intelligence system
The agent decomposes a small set of demonstrations into verifiable stages and selects rule-based functions, learned policies, navigation and world-model tools. When verification fails, the system can re-grasp, revisit a prior stage, replan or revise a failing tool implementation. Future-video samples generated by the world model are presented separately from the physical robot demonstrations.
Source - 2026-09-19 - Research Publication - Aether AI introduces CausalWM embodied causal world model
Aether reports a 66.04 TWB score on TriWorldBench and top robot-domain performance on PAI-Bench. The training approach combines video pretraining, causal chain-of-thought mid-training and reinforcement-learning post-training.
Source - 2026-06-18 - Funding - Aether AI raises $20M seed for causal world models
MPCi led the seed round, with Inno Angel Fund, SWC Global and Unity Ventures participating. Founder Biwei Huang is an assistant professor at UC San Diego and researches causal discovery and machine learning. The funding supports causal-model R&D, engineering infrastructure, scientific hiring and initial Physical AI deployments.
Source
Context
Comparable profiles
- MAUM.AI
stack adjacency - Embodied AI World Models
- XIRRA
stack adjacency - Embodied AI World Models
- XYZ Embodied AI
stack adjacency - Embodied AI Model Layer · Embodied AI World Models
- ForgeAI
stack adjacency - Embodied AI Model Layer · Embodied AI World Models
- Alibaba Group
stack adjacency - Foundation Model
- Veeda AI
stack adjacency - Embodied AI World Models
- AstraQua
stack adjacency - Foundation Model
- Flexion
stack adjacency - Embodied AI Model Layer
- MindOn
stack adjacency - Embodied AI Model Layer
- Intelligence Factory
stack adjacency - Embodied AI Model Layer
- ACE Robotics (大晓机器人)
stack adjacency - Embodied AI Model Layer
- Simple AI / 深朴智能
stack adjacency - Embodied AI World Models
Shared workflows
- Physical Intelligence
workflow adjacency - Embodied World Model Training
- Ropedia
workflow adjacency - Embodied World Model Training
- Reactor
workflow adjacency - Embodied World Model Training
- Stanhope AI
workflow adjacency - Embodied World Model Training
Context tags
- Embodied AI world models - Stack Layer - Causal world models for physical AI and robotics.
- Embodied world model training - Workflow - Seed round funds causal world-model work for robots.
- Foundation model - Stack Layer - World-model foundation infrastructure.
- Embodied AI model layer - Stack Layer - Model layer for physical-AI reasoning.