
Nature Will
About
About Nature Will
Nature Will develops the model and learning infrastructure between perception and physical action, focusing on general dexterous manipulation rather than manufacturing a complete robot. Led by founder and CEO Ning Ding, it builds data acquisition and governance, foundation-model training, simulation, real-world evaluation and post-training into a single research stack. Human hand-use experience is converted into language-conditioned action supervision before adaptation with robot data.
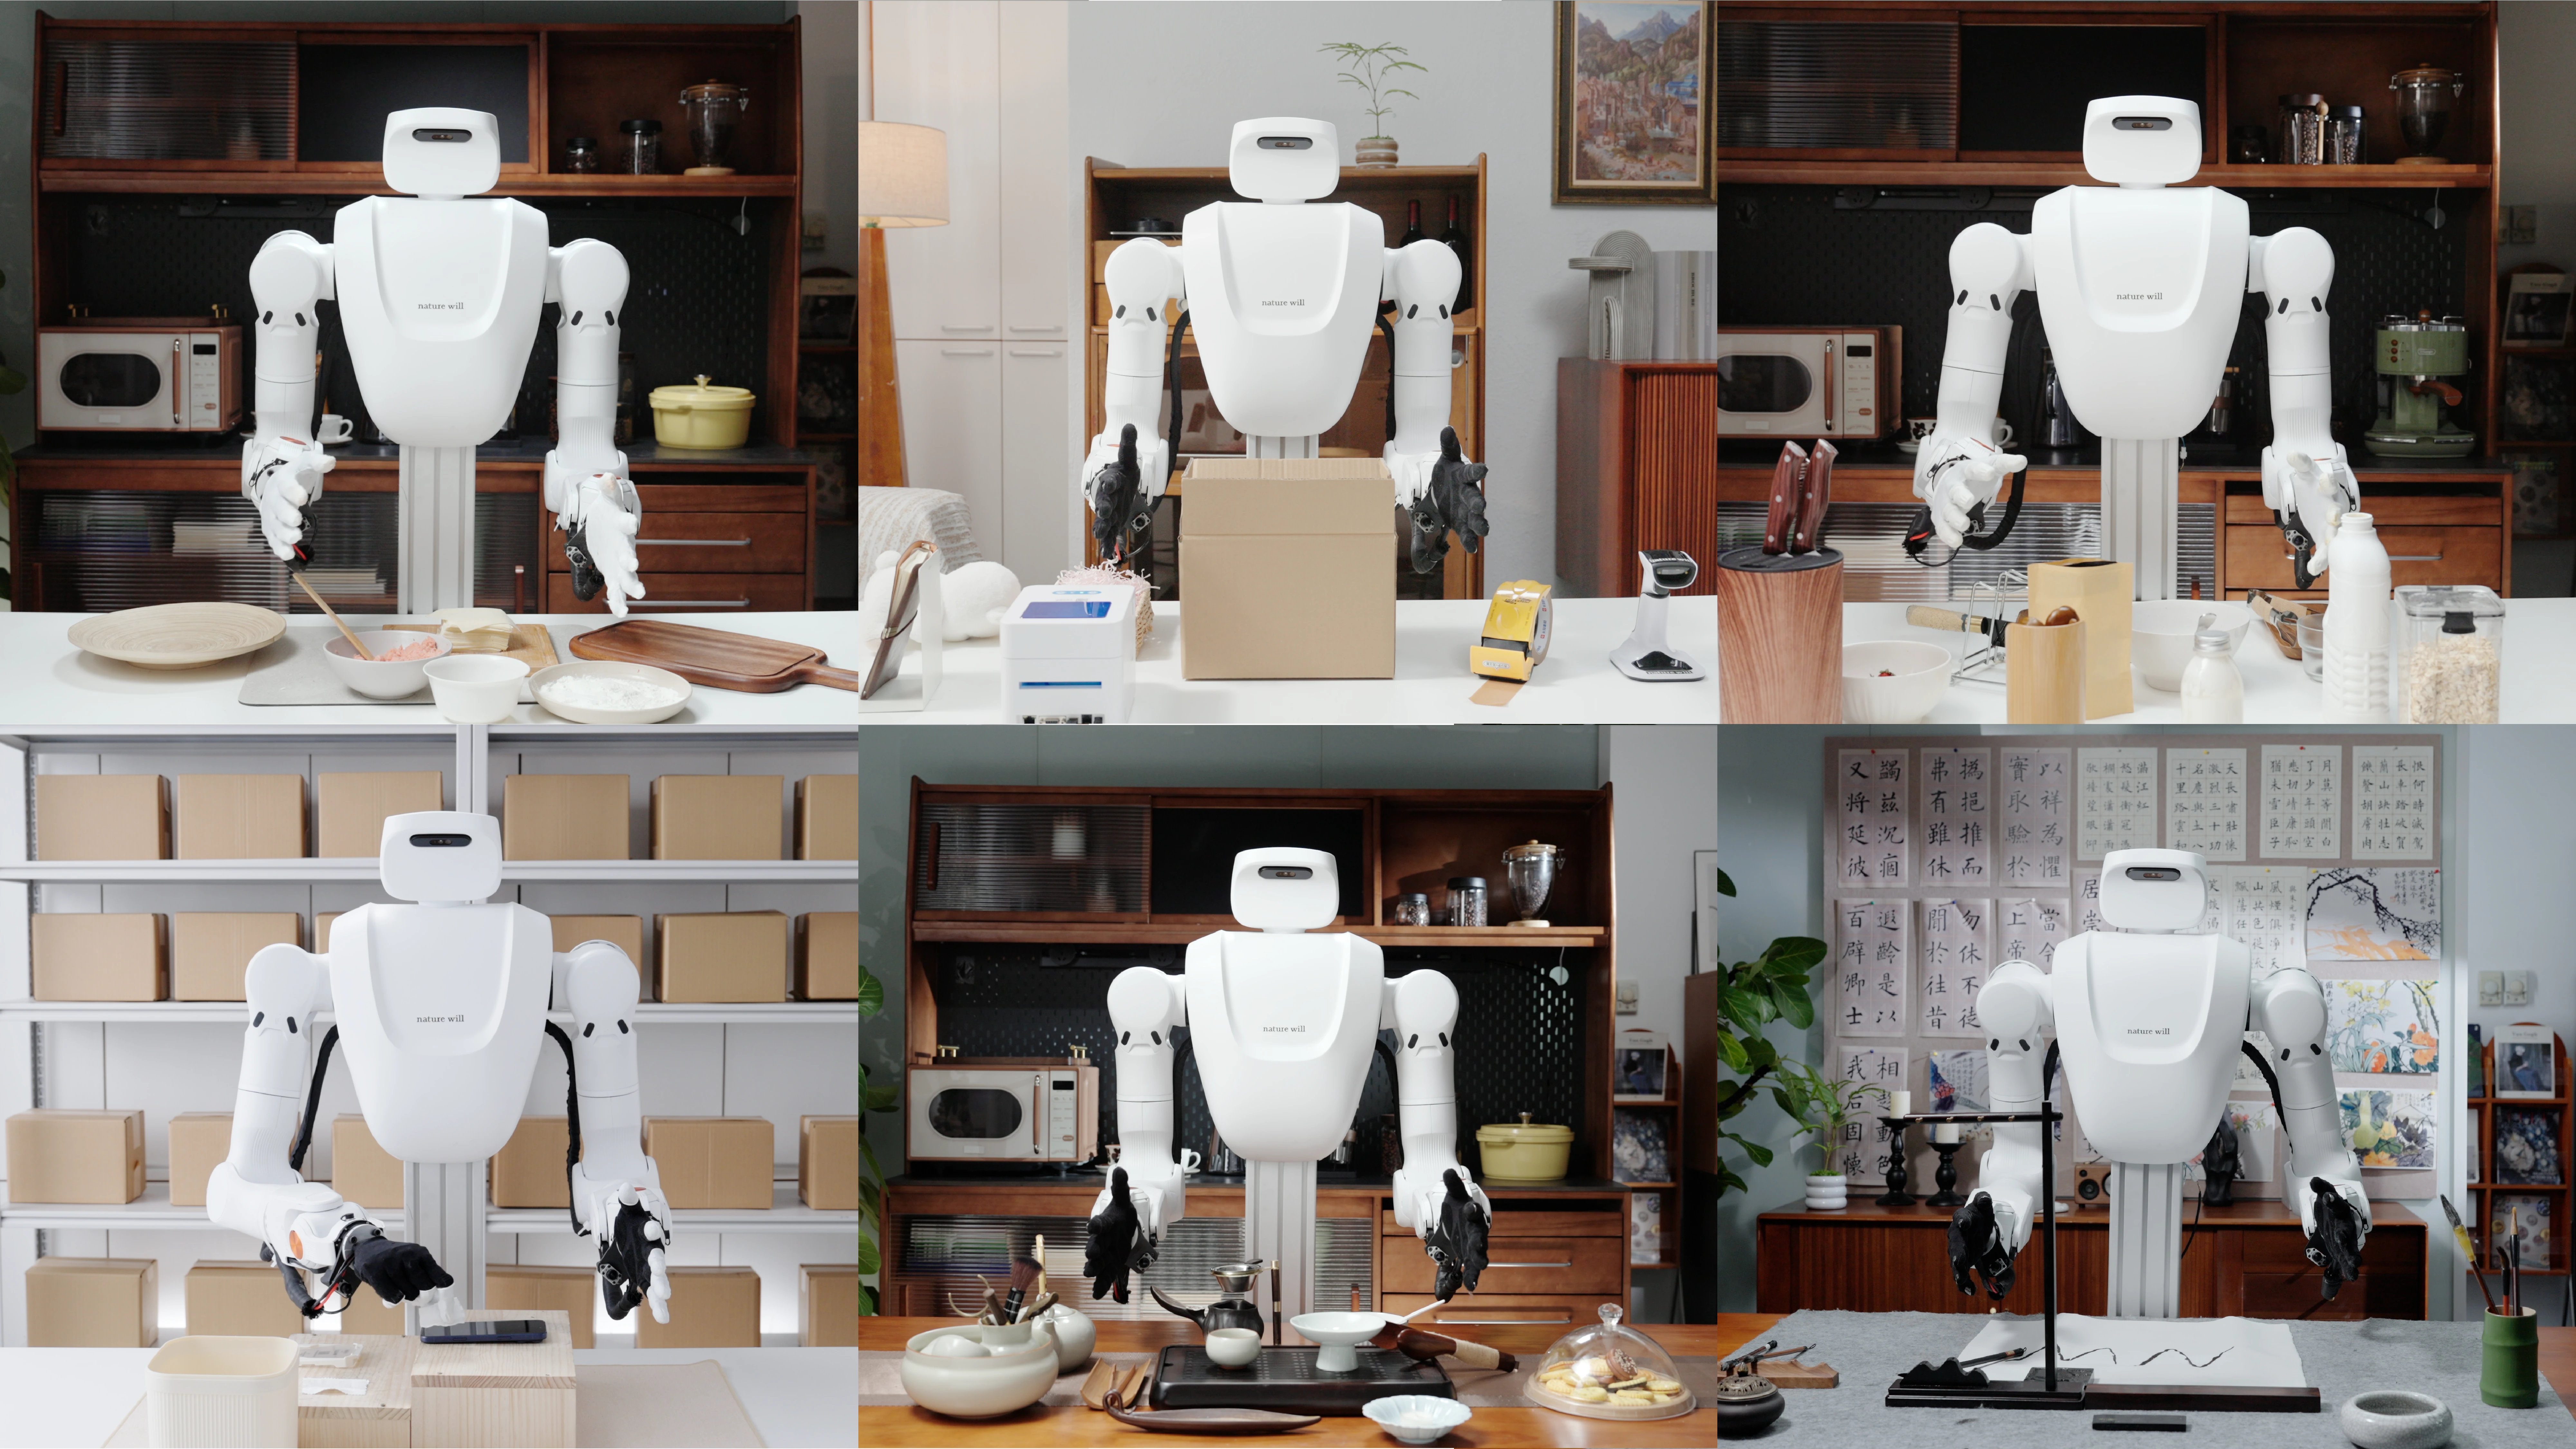
Its first announced physical foundation model, Natura-1, is a 50-billion-parameter mixture-of-experts model trained on more than one million hours of egocentric human experience. The company demonstrates a 100-millisecond control loop with 20-degree-of-freedom hands on a ROKAE dual-arm platform. Reported benchmark scores, long-horizon workflows and generalization demonstrations are company evaluations; the gripper baselines use a different ARX platform. A model announcement and demonstrations do not establish a commercial fleet or operational deployment.
Articles
Funding
- 2026-04-27 - Angel - Nature Will raises angel financing for physical-intelligence models at reported CNY4B valuation
valuation: CNY 4B (~$586.2M) - Nature Will completed an angel round with IDG Capital, Frees Fund and ZhenFund among the investors, at a reported CNY4 billion valuation. The financing amount and pre-money or post-money valuation basis were not disclosed. - source: taibo.cn
Investors
- Frees Fund - Participant - VC - 1 funding event - first seen 2026-04-27
- IDG Capital - Participant - VC - 1 funding event - first seen 2026-04-27
- ZhenFund - Participant - VC - 1 funding event - first seen 2026-04-27
Team
- Ning Ding - Founder and Chief Executive Officer
Research
- Nature Will introduces Natura-1 dexterous physical foundation model
2026-10-13 - Research Publication - The model takes language and vision inputs and controls 20-degree-of-freedom hands in a 100-millisecond loop after robot-data post-training. Company tests use ROKAE AR5 arms with Wuji hands and report scores of 53.4 Base and 59.1 Agentic; gripper baselines run on a different ARX platform. Demonstrations include long-horizon tool use, calligraphy and manipulation of deformable materials under unfamiliar instructions.
Source
Timeline
Events
- 2026-10-13 - Research Publication - Nature Will introduces Natura-1 dexterous physical foundation model
The model takes language and vision inputs and controls 20-degree-of-freedom hands in a 100-millisecond loop after robot-data post-training. Company tests use ROKAE AR5 arms with Wuji hands and report scores of 53.4 Base and 59.1 Agentic; gripper baselines run on a different ARX platform. Demonstrations include long-horizon tool use, calligraphy and manipulation of deformable materials under unfamiliar instructions.
Source - 2026-04-27 - Funding - Nature Will raises angel financing for physical-intelligence models at reported CNY4B valuation
Founder Ning Ding is a Tsinghua electronic-engineering assistant professor whose research spans general intelligence and reasoning. Ding studied at Huazhong University of Science and Technology before doctoral study at Tsinghua and postdoctoral work in its electronic-engineering department. The company initially focused on embodied intelligence and the model layer for physical reasoning.
Source