
NVIDIA Isaac ROS
About
About NVIDIA Isaac ROS
NVIDIA Isaac ROS is an open-source collection of accelerated ROS 2 software packages for robot perception, navigation and manipulation. Developers combine GPU-enabled components for stereo depth, visual SLAM, object pose estimation, scene reconstruction and motion planning into application pipelines. The software connects camera and other sensor inputs to AI inference and planning on supported NVIDIA computing platforms, with examples for physical robots and Isaac Sim.
Release 5.0, published in September 2026, moved the supported ROS distribution to ROS 2 Lyrical and added Ubuntu 24.04 packages. Accelerated message transport now uses ROS 2's rosidl::Buffer with a CUDA backend, allowing array data to use GPU-backed memory. Applications calling the former NITROS interfaces directly require source changes. The release also supplies agent skills for development and migration, alongside deployment, teleoperation and data tools for building and running robot applications.
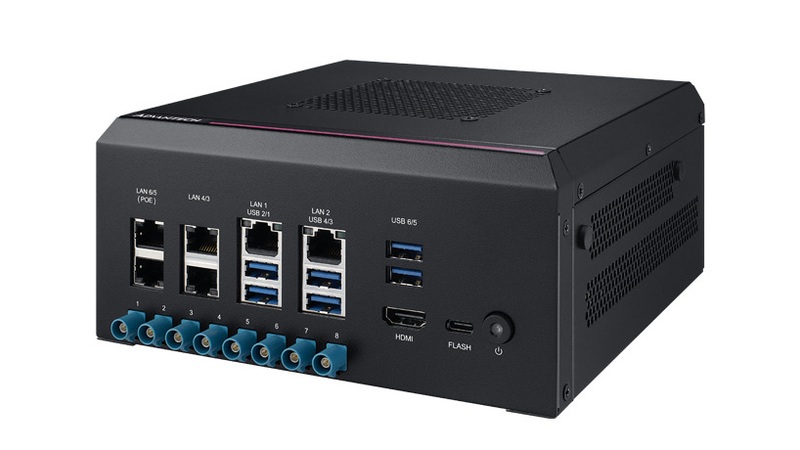
Advantech introduces UniCAM multi-camera integration on NVIDIA Jetson Thor
LG Innotek and NVIDIA develop robot vision sensing with Holoscan Sensor Bridge
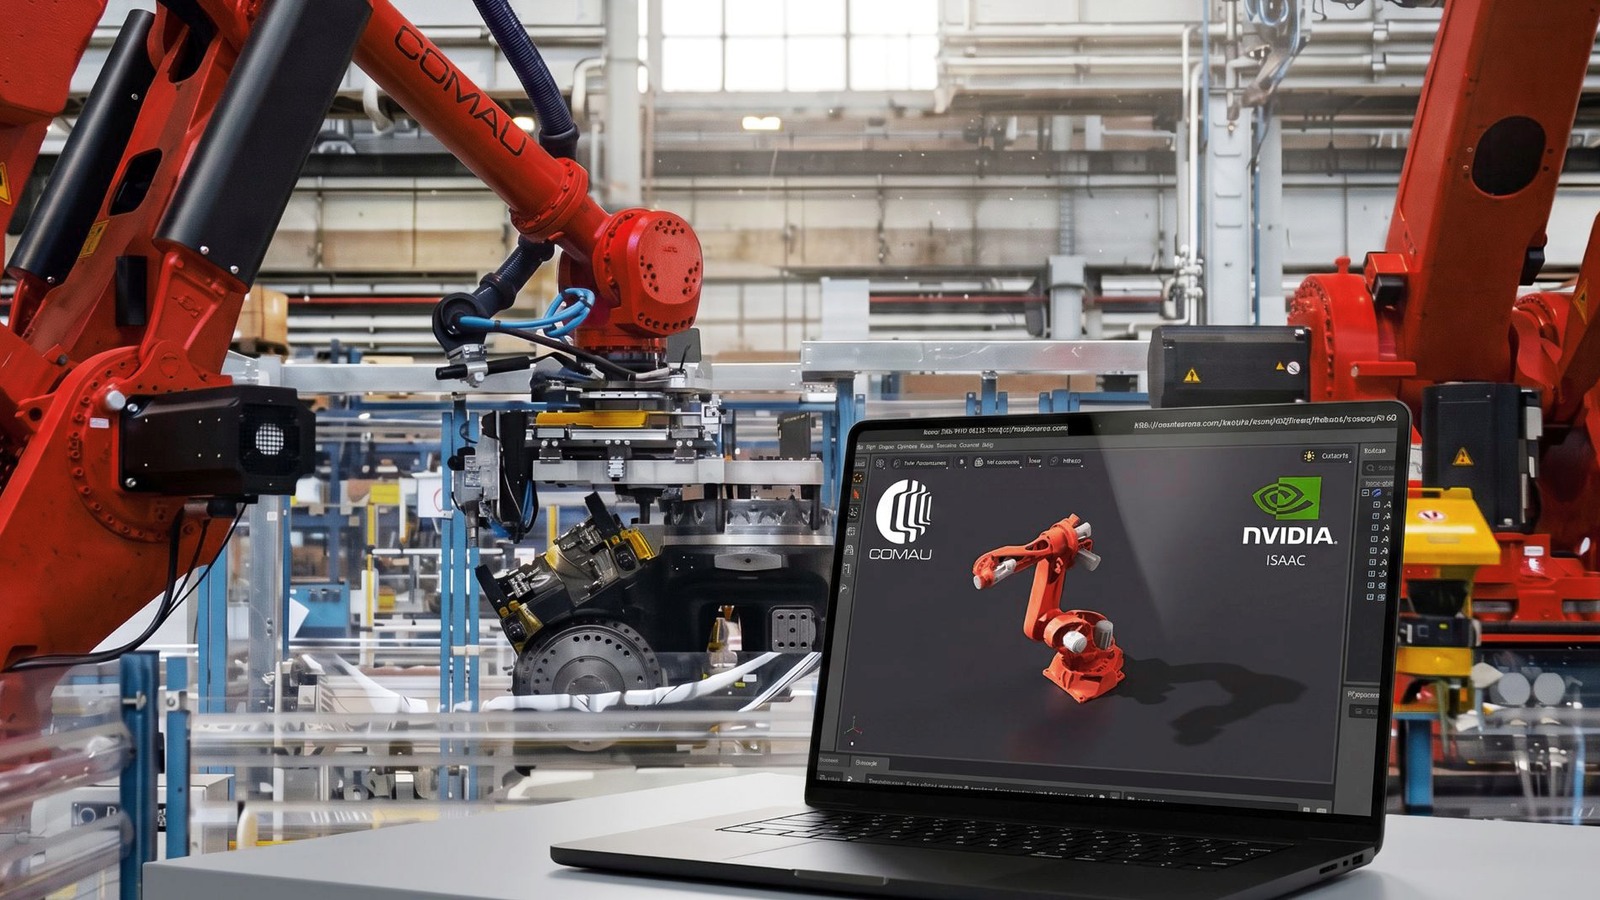
Comau integrates NVIDIA Jetson and Isaac tools across industrial robotics portfolio
NVIDIA introduces Flora data engine for robotics video annotation
Timeline
- NVIDIA releases Isaac ROS 5.0
2026-09-22 - Product Launch - The release adds NVIDIA-built ROS 2 Lyrical packages for Ubuntu 24.04 and updates GPU-backed message exchange through rosidl::Buffer. FoundationPose inference runs up to 5.5x faster, alongside a FoundationStereo fine-tuning workflow. The release includes a standalone agent-ready pick-and-place workflow and expanded Jetson and RealSense integration.
Source