
PM01
About
About PM01
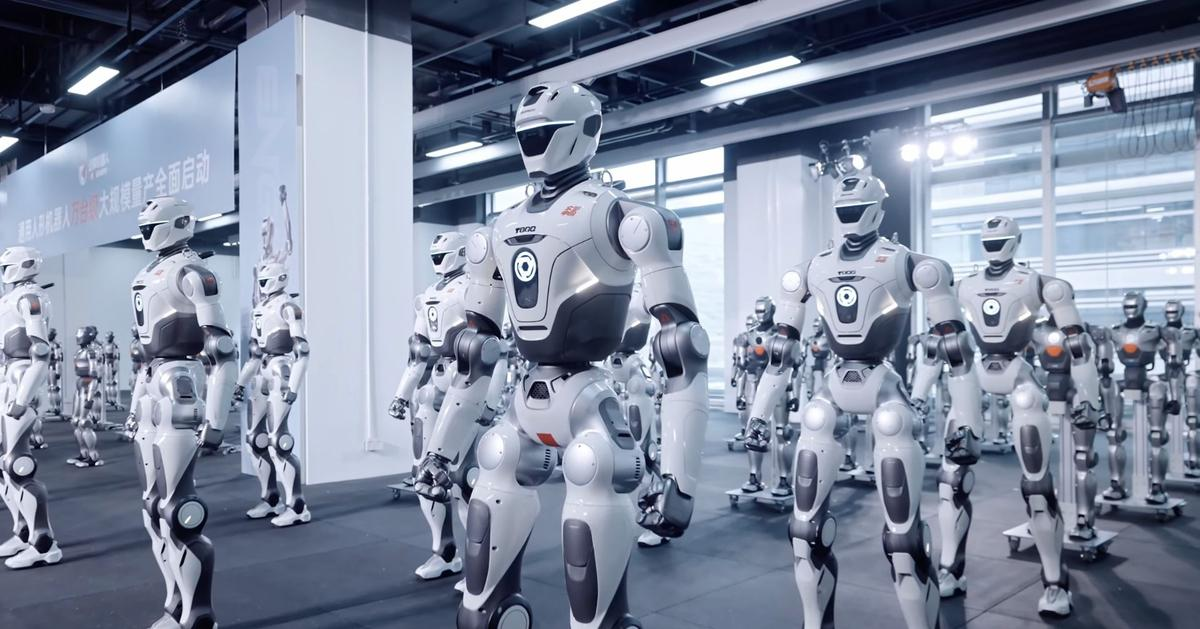
PM01 is ENGINEAI's compact bipedal robot for research, education and dynamic movement development. The current 2026 Education and Navigation editions are approximately 1.4 metres tall, with 24 powered degrees of freedom and a wide-rotation waist. Whole-body control, onboard perception and proprietary joint actuators support walking, running and expressive motion routines.
Both editions provide secondary-development access, training and deployment code, and an NVIDIA Jetson Orin NX module. The Navigation edition adds 3D lidar, while camera placement and display hardware vary by package. A quick-removal battery has a stated operating duration of about two hours. ENGINEAI sells PM01 as a development platform: its demonstration motions, hardware speed capability and customer-created applications represent different levels of task readiness.


Capabilities
Source-backed capabilities
- Operating environments: Shenzhen government-visit demonstration
- Bipedal walking
Demonstrated - 2026-01-06 - Walk with a human-like gait in the official demonstration. - environment: Shenzhen government-visit demonstration
Source - Fall recovery
Demonstrated - 2025-08-11 - PM01 demonstrated fall recovery, sitting and high-speed running during the live showcase.
Source - Dynamic acrobatics
Demonstrated - 2026-01-06 - Perform a Webster front flip during the official demonstration. - environment: Shenzhen government-visit demonstration
Source
Operations
- Reported Output
hundreds of PM01 units in 2025 - 2026-05-29 - humanoid robot manufacturing - EngineAI said it moved from a first test machine in 2024 to small-scale production of hundreds of PM01 units in 2025 before the T800 manufacturing-base launch. The wording is approximate, so it is not ranked against exact output rows.
Source
Observed use
Exact-product configurations are shown without inferring supply, purchase, customer status, standard fit, deployment or partnership.
- E1R
2026-08-30 - Research Experiment - Mounted - Physical - ETH Zurich mounted a RoboSense E1R lidar on a modified ENGINEAI PM01 for autonomous monkey-bar traversal and overhead-obstacle experiments.
Source
Supply
Supply / Components
- PM01-EDU configuration
Jetson Orin Compute For Pm01 - Compute & Control - NVIDIA - ENGINEAI PM01-EDU uses NVIDIA Jetson Orin NX for application compute - source: engineai.com.cn
Source - PM01-EDU configuration
N97 X86 Compute For Pm01 - Compute & Control - Intel - ENGINEAI PM01-EDU uses an Intel N97 computer for motion control - source: engineai.com.cn
Source - PM01 documented camera configuration
D435i Depth Camera For Pm01 - Perception - RealSense - ENGINEAI PM01 uses a built-in RealSense D435i depth camera - source: engineai.com.cn
Source
Research
- Vision as Proprioception: Estimating Humanoid Robot Pose from Video
2026-10-18 - Research Publication - HumanoidPose estimates humanoid joint configurations and root pose from ordinary video using pretrained human-vision features and a kinematics-conditioned decoder. The ETH Zürich team trains across16 synthetic embodiments and reports18–32% lower joint-angle error than its strongest evaluated baselines on three real robot platforms.
Source - Learning Agile Perceptive Traversal of Sparse 3D Structures for Humanoids
2026-08-30 - Research Publication - The system combines an attention-based lidar encoder, recurrent memory and phase-scheduled teacher-student reinforcement learning, with hardware-aware models for lidar noise, battery-voltage sag and actuator thermal limits.
Source - ENGINEAI ROS2 interfaces and simulation examples
Research Publication - ENGINEAI’s ROS2 workspace provides robot interfaces, MuJoCo simulation and control examples. The current source tree contains PM01, T800 and T800 Pro configurations, with an included PM01 walking-policy file.
Source - EngineAI robot description collection
Research Publication - EngineAI publishes separate PM01, T800 and T800 Pro robot descriptions and mesh assets. The collection distinguishes PM01 lidar and EDU revisions, T800, and 25/43-DoF T800 Pro configurations.
Source - EngineAI native control SDK
Research Publication - EngineAI releases a modular control runtime with task orchestration, simulation and hardware-deployment tooling. Named configurations include PM01 EDU and T800, with robot models and actual MNN walking, dance and transition policies.
Source - EngineAI RL Lab
Research Publication - EngineAI RL Lab supplies Isaac Lab training environments for PM01 and T800 whole-body tracking and adversarial-motion-prior locomotion. Source includes task registrations, replay and deployment workflows plus exported ONNX policies.
Source - EngineAI PM01 navigation stack
Research Publication - EngineAI’s navigation stack trains an SRU-based policy from ordered lidar range images and executes velocity commands through a walking controller. It contains separate PM01 Gazebo and physical ROS 2 deployment trees, preprocessing and an actual ONNX navigation policy.
Source
Timeline
- ETH Zurich study demonstrates autonomous sparse-structure traversal on PM01
2026-08-30 - Research Publication - The PM01 completed the full monkey-bar sequence in 14 of 15 hardware trials across three bar configurations and reached brachiation speeds up to 0.5 m/s. A separately trained policy completed ten passes beneath randomly placed 2 cm wooden bars without contact, recovering to a stable stance after each crossing. The research configuration replaced PM01 hands with passive hooks and mounted a RoboSense E1R lidar; after one goal position was supplied, the traversal sequence ran autonomously.
Source - EngineAI showcases T800 and PM01 at CES 2026
2026-01-07 - Demonstration - The demonstrations focused on whole-body coordination and fine motor control, with discussions involving developers, industry partners and media. The T800 presentation described integrated joint modules rated for up to 450 N·m peak torque and 14,000 watts of instantaneous joint peak power.
Source - EngineAI showcases PM01, T800 and JS01 at World Robot Conference
2025-08-08 - Demonstration - PM01 demonstrated fall recovery, sitting and high-speed running during the live showcase. The T800 prototype was presented as a 1.85-metre heavy-duty humanoid; the booth also included the JS01 quadruped and a preview of the planned SA02.
Source - EngineAI PM01 performs a front flip in Shenzhen
2025-02-23 - Demonstration - The manoeuvre combined dynamic balance, rapid acceleration and controlled landing. PM01 had been introduced at the end of 2024 for commercial and education applications, with initial deliveries scheduled for the second quarter of 2025.
Source - EngineAI showcases SE01, SA01 and PM01 at CES 2025
2025-01-07 - Demonstration - SA01 and PM01 were presented as open development platforms for research teams; SA01 carried an announced price of US$5,400. The 1.38-metre PM01 was offered in commercial and educational editions at a promotional US$13,700 through March 31, 2025.
Source - EngineAI introduces PM01 humanoid development platform
2024-12-24 - Product Launch - The 1.38-metre, approximately 40-kilogram robot supports mechanical and natural-gait walking modes, with an interaction screen and articulated neck and waist. Commercial and educational editions were offered at a promotional US$13,700 through March 31, 2025, including a commercial-to-education upgrade during the offer.
Source
Context
Market context
Lightweight humanoid platform designed for developers, research environments, and education.
- Target environment: Robotics labs, education settings, developer programs and early embodied-AI test environments.
- Workflow context: Humanoid development, locomotion testing, interaction experiments, embodied-system prototyping and education.
- Customer context: Researchers, educators, developers and teams needing an accessible humanoid hardware platform.
- Deployment model: Commercially positioned developer and research humanoid in ENGINEAI's product family.
- Commercial maturity: Commercially presented product with public company positioning, but limited evidence of broad deployed use.
- Adoption constraints: Adoption depends on price, SDK quality, safety, repairability, mobility performance and developer support.
- Market position: Accessible humanoid developer platform below larger industrial or enterprise-oriented ENGINEAI systems.
- Adjacent products: Unitree G1, Booster T1, Kuavo, Fourier GR-1
Comparable Systems
- MagicBot Z1
MagicLab - Anthropomorphic Biped
- E1
Noetix Robotics (松延动力) - humanoid robotics
- HUBO2
Rainbow Robotics - humanoid robotics
- TALOS
PAL Robotics - humanoid robotics
- TORO
DLR Institute of Robotics and Mechatronics - Anthropomorphic Biped
- R1
Unitree - humanoid robotics
Related Systems
- T800
ENGINEAI - humanoid robotics