
SE01
About
About SE01
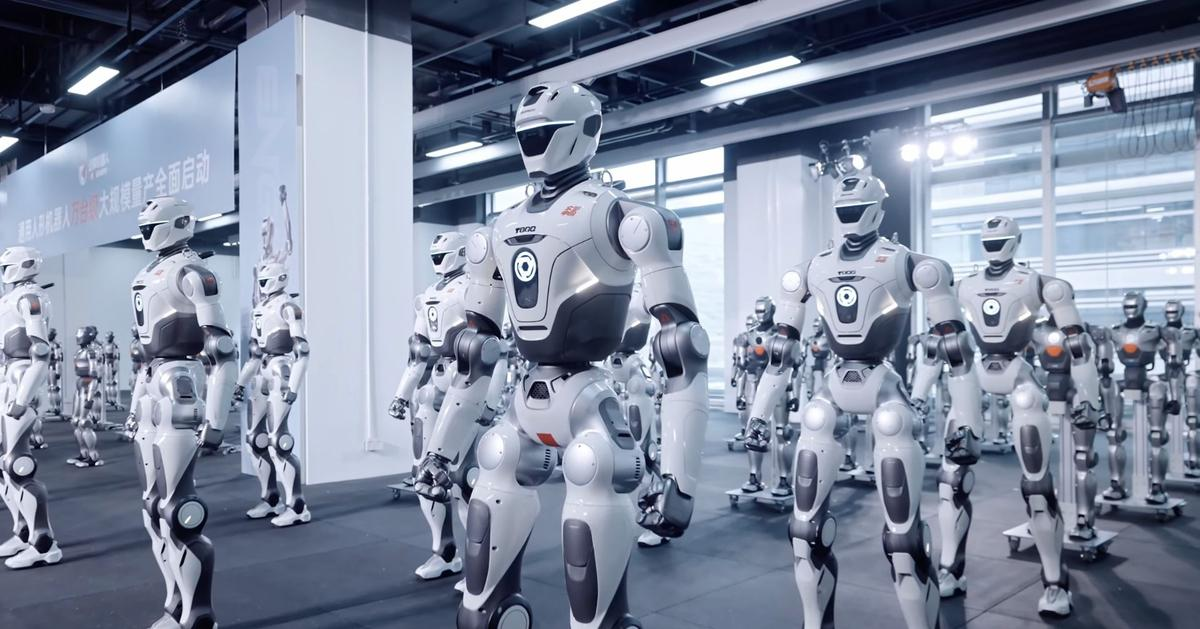
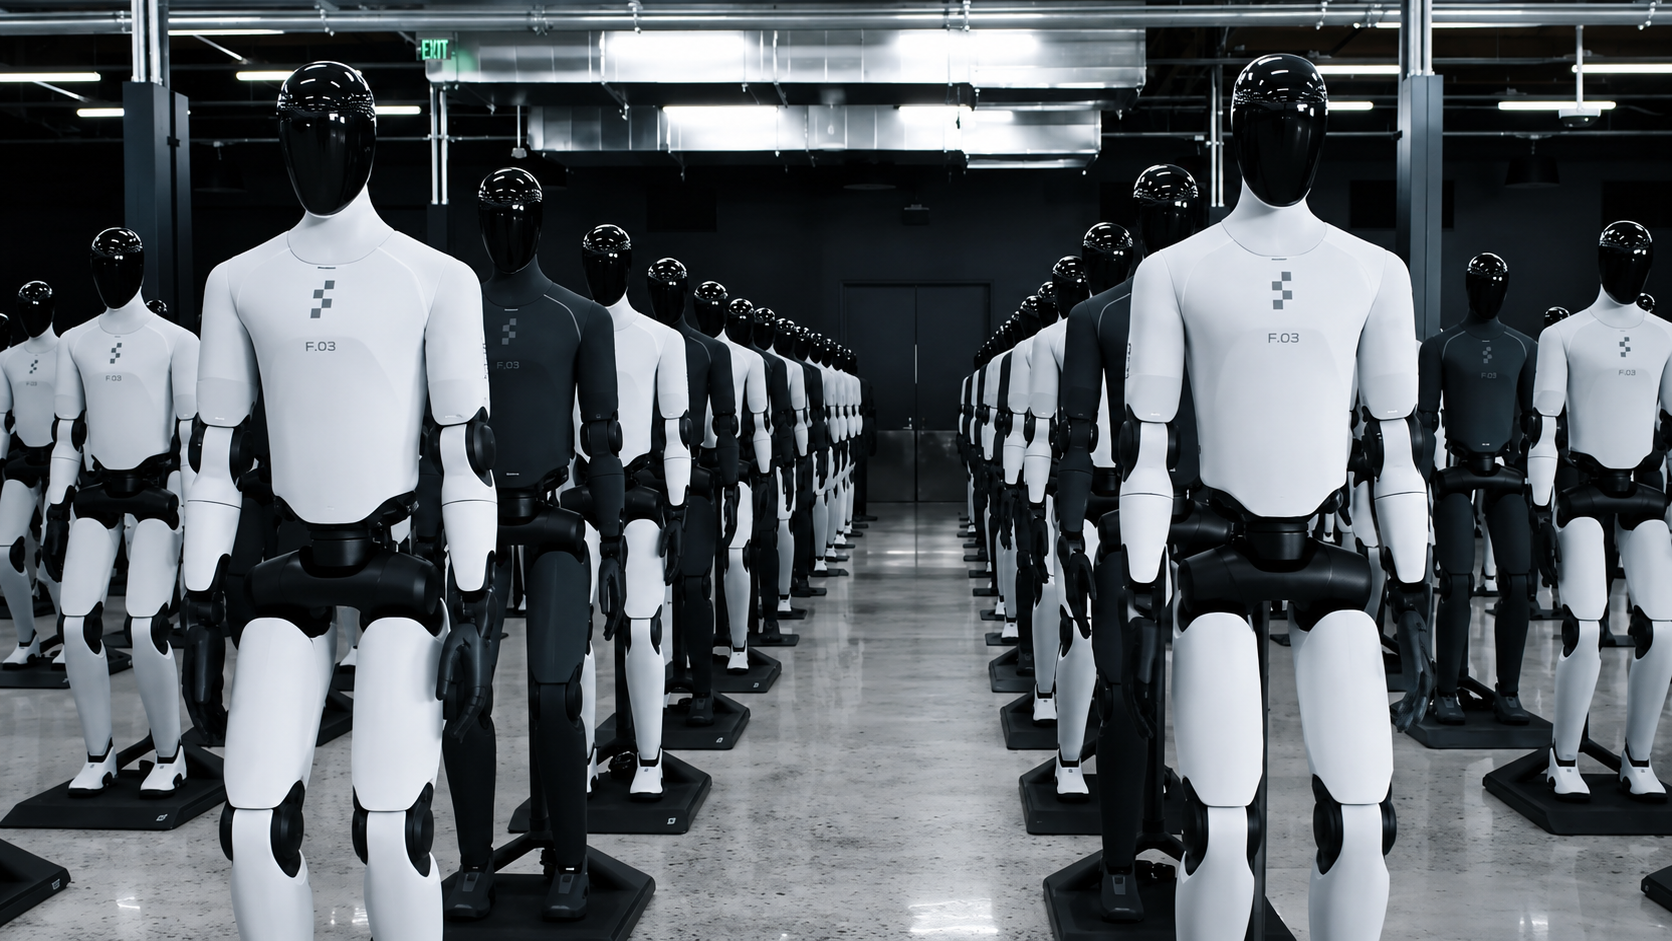
SE01 is ENGINEAI's full-size bipedal humanoid for movement and manipulation development. Its human-proportioned aluminium body combines proprietary joint actuators with five-finger hands. Neural-network gait training supports walking and turning, alongside demonstrated squatting and other dynamic movement routines.
The robot's perception system combines lidar, depth and infrared cameras with onboard audio and inertial sensing. Visual feedback is intended to guide arm motion and grasping, while force feedback in the articulated hands supports contact-sensitive manipulation. A quick-release battery allows battery replacement between operating sessions. SE01 is a general-purpose development platform within ENGINEAI's humanoid programme; its physical architecture and demonstrated movement routines should be distinguished from completed customer applications.


Capabilities
Source-backed capabilities
Timeline
- EngineAI showcases SE01, SA01 and PM01 at CES 2025
2025-01-07 - Demonstration - SA01 and PM01 were presented as open development platforms for research teams; SA01 carried an announced price of US$5,400. The 1.38-metre PM01 was offered in commercial and educational editions at a promotional US$13,700 through March 31, 2025.
Source - EngineAI introduces SE01 full-size humanoid
2024-10-24 - Product Launch - The 1.7-metre, approximately 55-kilogram robot uses harmonic force-control joints and reinforcement and imitation learning for movement. EngineAI targeted heavy handling and precision assembly in factories and later exhibited SE01 at CES 2025.
Source
Context
Market context
Mid-tier humanoid platform developed by ENGINEAI, positioned between lightweight developer units and full-scale industrial systems.
- Target environment: Robotics demonstrations, labs, industrial pilot settings and structured environments requiring bipedal mobility research.
- Workflow context: Humanoid walking, balance, general-purpose movement, early manipulation testing and embodied-AI development.
- Customer context: Industrial partners, researchers and developers evaluating ENGINEAI's larger humanoid hardware line.
- Deployment model: Commercially positioned humanoid platform between developer units and heavier enterprise systems.
- Commercial maturity: Publicly demonstrated product with visible company positioning but limited broad commercial deployment evidence.
- Adoption constraints: Adoption depends on gait reliability, manipulation maturity, safety, operating time, service support and application fit.
- Market position: Gait-forward Chinese humanoid lane competing on natural movement and platform accessibility.
- Adjacent products: PM01, Unitree G1, Robot Era L7, Fourier GR-1