
Helix
About
About Helix
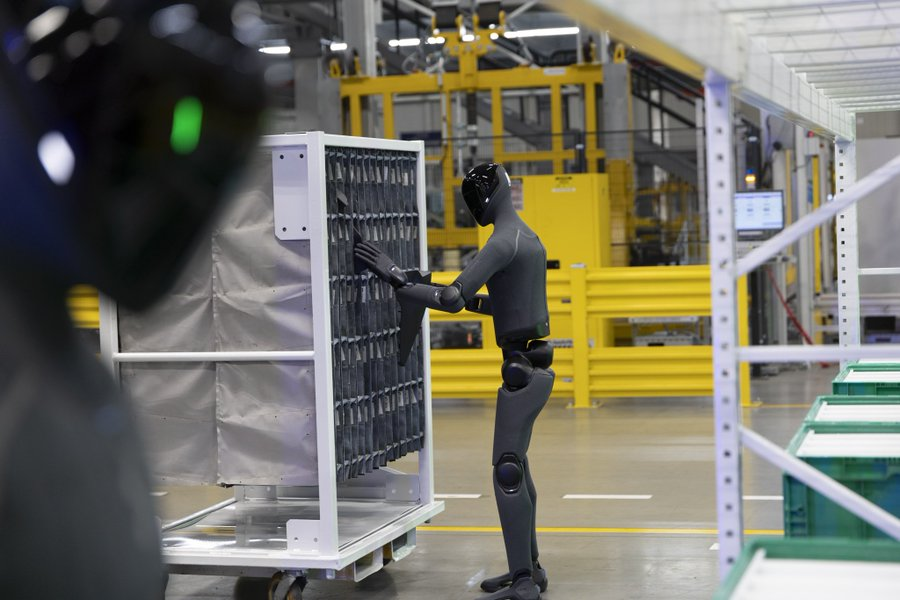
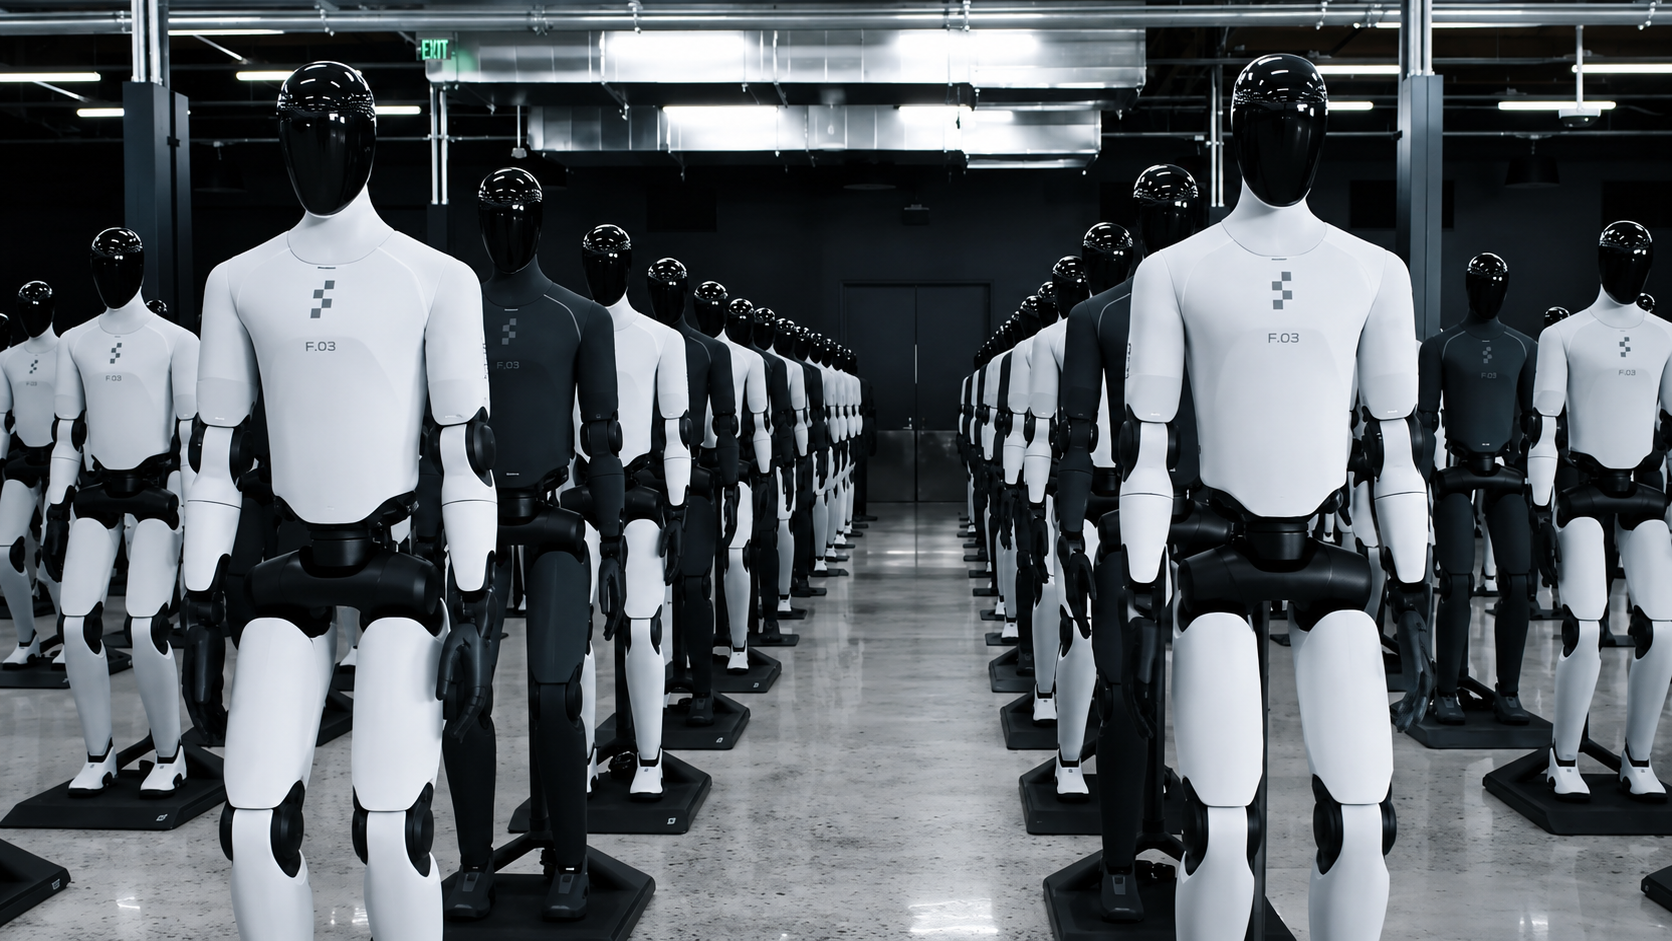
Helix is Figure’s vision-language-action system, linking visual observations and language instructions to continuous humanoid motion. Its initial architecture divides work between a slower vision-language model for scene and task understanding and a faster policy that converts that understanding into responsive movements of the upper body, hands and head.
The two systems exchange a compact representation of the intended behaviour while using incoming images and robot-state information to adjust motion. Training uses teleoperated examples paired with language descriptions, and execution runs on onboard processors. This arrangement connects semantic instructions with feedback-driven physical control, supporting learned manipulation and the sequencing of behaviours on Figure’s robots.


Capabilities
Source-backed capabilities
- Workflows: Natural-language task execution, object manipulation, collaborative handoff and real-time robot control.
- Operating environments: Figure humanoid deployments, logistics demonstrations and household manipulation demos.
- Target markets: Figure AI robot development teams and customers evaluating Figure humanoids for physical work.
- Deployment model: Platform-integrated model layer running on Figure robots rather than a standalone third-party software product.
- Object manipulation
Demonstrated - 2026-05-08 - Figure published an official Helix 02 bedroom-tidy demo showing its humanoid system performing a household soft-object manipulation task.
Source - Fabric smoothing and folding
Demonstrated - 2025-08-16 - On 16 August 2025, Figure 02 continued folding laundry while a person raised the worktable, and Helix adapted to the changing height in real time.
Source - Deformable-object manipulation
Research demonstration - 2026-09-17 - One base model produced three behaviours - tidying a living room, folding towels and making a bed - spanning locomotion, rigid and deformable manipulation, bimanual coordination and active perception.
Source - Bimanual manipulation
Research demonstration - 2026-09-17 - One base model produced three behaviours - tidying a living room, folding towels and making a bed - spanning locomotion, rigid and deformable manipulation, bimanual coordination and active perception.
Source - Dexterous manipulation
Research demonstration - 2025-08-12 - The demonstration covered mixed laundry piles, adaptive folding from different starting configurations, recovery from multi-pick errors, and fine manipulation such as tracing edges and pinching corners, alongside learned gaze and hand gestures.
Source - Object manipulation
Research demonstration - 2025-08-12 - Figure AI shows Helix folding laundry as a deformable-object manipulation benchmark
Source - Deformable-object manipulation
Research demonstration - 2025-08-12 - Figure AI shows Helix folding laundry as a deformable-object manipulation benchmark
Source - Fabric smoothing and folding
Research demonstration - 2025-08-12 - Figure AI shows Helix folding laundry as a deformable-object manipulation benchmark
Source - Home tidying and tool use
Demonstrated - 2026-03-09 - On 9 March 2026, Helix 02 performed an end-to-end living-room cleanup while walking through the room and continuously manipulating objects, tools, and containers.
Source - Dishwasher loading
Demonstrated - 2025-09-03 - Figure demonstrates Helix loading a dishwasher
Source - Dishwasher loading
Claimed - 2026-01-27 - A four-minute autonomous kitchen sequence combined walking, unloading and reloading a dishwasher, carrying dishes, and cabinet placement; Figure also highlighted tactile and palm-camera dexterity, while noting these are early company demonstrations rather than deployment proof.
Source
Supply
Supply / Components
- Helix
Gpu Cloud Compute And Orchestration - ai_compute - Nscale - Nscale will provide Figure AI with compute for future Helix models under a multi-year preferred-provider agreement - source: prnewswire.co.uk
Source
Research
- Figure introduces Helix 02 full-body humanoid autonomy model
2026-01-27 - Research Publication - Figure introduces Helix 02, a full-body autonomy model that connects perception, whole-body control, and semantic reasoning for humanoid loco-manipulation. The release shows a four-minute autonomous dishwasher task and dexterous manipulation using Figure 03 sensing.
Source - Project Go-Big: Internet-Scale Humanoid Pretraining and Direct Human-to-Robot Transfer
2025-09-18 - Research Publication - Figure announced Project Go-Big as a large-scale humanoid pretraining initiative built around egocentric human video collected across Brookfield environments. The company says Helix achieved zero-shot human-video-to-robot transfer for navigation tasks and now uses a unified model for both manipulation and navigation.
Source - Figure AI shows Helix folding laundry as a deformable-object manipulation benchmark
2025-08-12 - Research Publication - This paper covers Figure AI shows Helix folding laundry as a deformable-object manipulation benchmark for Helix in dexterity.
Source - Figure scales Helix logistics policy for faster package handling
2025-06-07 - Research Publication - Figure reports Helix logistics policy improvements for package handling, including broader package variety, faster handling time, higher barcode-orientation success, temporal visual memory, and force feedback in the policy input.
Source - Figure applies Helix to real-world logistics package manipulation
2025-02-26 - Research Publication - Figure reports Helix improvements for real-world logistics package manipulation and triaging. The post covers stereo vision, multi-scale visual representation, learned visual proprioception, data curation, and faster-than-demonstrator policy execution.
Source - Figure AI introduces Helix VLA model for generalist humanoid control
2025-02-20 - Research Publication - This model covers Figure AI introduces Helix VLA model for generalist humanoid control for Helix in Human-robot interaction.
Source
Timeline
- Figure AI introduces Helix 2.5 with zero-shot generalization across 30 homes
2026-09-17 - Research Publication - Holding task-specific data, architecture, training and evaluation fixed, Index pretraining alone raised zero-shot success from 9% to 56%, and a single fixed checkpoint per task was used across all 30 homes with no adaptation to homes or objects. One base model produced three behaviours - tidying a living room, folding towels and making a bed - spanning locomotion, rigid and deformable manipulation, bimanual coordination and active perception. Figure reports a human-to-humanoid transfer scaling law: across an 8x increase in Index pretraining data, loss fell predictably enough to forecast the largest run's test loss to four decimal places before training, with forecasting error of 0.54% of the variation.
Source - Figure selects Nscale as preferred compute provider
2026-09-03 - Partnership - The agreement includes an initial $3.5 billion compute commitment and an intent to scale beyond $6 billion. The potential deployment covers up to 100,000 NVIDIA Vera Rubin GPUs, with initial capacity targeted for Barstow, Texas, from the second half of 2027. Nscale will become a Figure shareholder and the companies will explore using humanoids to scale Nscale's supply chain.
Source - Figure demonstrates Helix 02 bedroom tidy task with humanoid robot
2026-05-08 - Demonstration - Figure published an official Helix 02 bedroom-tidy demo showing its humanoid system performing a household soft-object manipulation task. The demo expands Figure's home-task evidence beyond rigid object handling into bedroom organization and bed-related manipulation. Treat this as a capability demonstration for Helix and home robotics, not a deployment or product launch.
Source - Figure demonstrates Helix 02 autonomous living-room cleanup
2026-03-09 - Demonstration - On 9 March 2026, Helix 02 performed an end-to-end living-room cleanup while walking through the room and continuously manipulating objects, tools, and containers. The demonstration included spraying and wiping a surface, handling a flexible towel, moving a bin while scooping blocks, throwing a pillow, reorienting a remote, and navigating tight spaces. The release presents the same general-purpose system learning these behaviors by adding data rather than new algorithms or special-case engineering; this remains a company demonstration, not evidence of broad home deployment.
Source - Figure introduces Helix 02 for full-body humanoid autonomy
2026-01-27 - Product Launch - On 27 January 2026, Figure introduced Helix 02 as a system extending Helix's upper-body control to the entire robot, including walking, manipulation, and balance. The release describes a unified stack: System 2 for goals and language, System 1 for 200 Hz full-body joint targets, and System 0 for 1 kHz balance, contact, and coordination. A four-minute autonomous kitchen sequence combined walking, unloading and reloading a dishwasher, carrying dishes, and cabinet placement; Figure also highlighted tactile and palm-camera dexterity, while noting these are early company demonstrations rather than deployment proof.
Source - Figure 02 contributes to 30,000 BMW X3 vehicles at Plant Spartanburg
2025-11-19 - Deployment - Figure reported an 11-month Figure 02 deployment at BMW Group Plant Spartanburg. The robots ran 10-hour weekday shifts, logged more than 1,250 runtime hours, and loaded more than 90,000 parts. Figure said the deployment contributed to production of more than 30,000 BMW X3 vehicles before Figure 02 fleet retirement.
Source - Figure partners with Brookfield on humanoid data, infrastructure and deployment pathways
2025-09-17 - Partnership - Figure announced a strategic partnership with Brookfield, which it described as a major real-world environment partner for humanoid scale-up. The partnership covers real-world humanoid pretraining data, AI infrastructure for Helix and robotic training environments across Brookfield assets. Figure said the companies will explore humanoid deployment opportunities across Brookfield's portfolio over time.
Source - Figure exceeds $1B in Series C commitments at $39B valuation
2025-09-16 - Funding - On 16 September 2025, Figure disclosed more than $1 billion in committed Series C capital at a $39 billion post-money valuation, led by Parkway Venture Capital. Figure linked the financing to scaling Helix, expanding BotQ manufacturing, and placing general-purpose humanoid robots into homes and commercial operations. The plan also includes GPU infrastructure and human-video and multimodal data collection to improve Helix's perception, reasoning, and control.
Source - Figure demonstrates Helix loading a dishwasher
2025-09-03 - Demonstration - Helix learned to singulate stacked plates and load them in order. The system picked up a glass with one hand, reoriented it and placed it in the rack with the other. Figure reported that Helix adapted to messy starting configurations and recovered from misgrasps and collisions.
Source - Figure Helix adapts to a table-height change during laundry folding
2025-08-16 - Demonstration - On 16 August 2025, Figure 02 continued folding laundry while a person raised the worktable, and Helix adapted to the changing height in real time. The video shows the robot responding to the altered surface during the fold rather than visibly failing or stopping when the work height changed. The dated clip is best treated as an adaptive-resilience demonstration, not a quantified benchmark or evidence of deployment.
Source - Figure 02 demonstrates autonomous Helix package sorting and barcode handling
2025-06-05 - Demonstration - On 5 June 2025, Figure 02, powered by Helix, autonomously sorted and scanned packages spanning different sizes, colours, materials, and deformability. The robot turned parcels to expose barcodes and flattened polybags before scanning, with forceful patting and smoothing used for wrinkled mailers. This is a video demonstration of autonomous package handling; it does not establish production deployment or human-level throughput, so those claims are not carried into the event.
Source - Figure demonstrates Helix voice-guided household manipulation with Figure 02
2025-02-20 - Demonstration - Figure 02 took voice instructions through Helix for household tasks, showing the model turn natural-language requests into robot actions rather than a fixed scripted sequence. The demonstration included two robots coordinating chores such as passing cookies and placing items in a drawer, matching Figure's contemporaneous description of multi-robot control. This was an early company demonstration and recruiting-oriented preview, not evidence of general home deployment; the event is retained as demonstrated capability.
Source
Context
Market context
Helix is Figure's vision-language-action model stack for humanoid perception, manipulation and whole-body control.
- Target environment: Figure humanoid deployments, logistics demonstrations and household manipulation demos.
- Workflow context: Natural-language task execution, object manipulation, collaborative handoff and real-time robot control.
- Customer context: Figure AI robot development teams and customers evaluating Figure humanoids for physical work.
- Deployment model: Platform-integrated model layer running on Figure robots rather than a standalone third-party software product.
- Commercial maturity: Public model layer with technical writeups and demos, tied to Figure's own humanoid platform.
- Adoption constraints: Adoption depends on Figure robot availability, task reliability, safety validation and deployment access.
- Market position: Robot foundation-model layer for humanoid manipulation and generalist physical task execution.
- Adjacent products: GENE-26.5, sudo R1, FluxVLA Engine, Project GR00T
Comparable Systems
- Being-H0.8
BeingBeyond - Robotics Foundation Model
- FusionMax
Muks Robotics AI Pvt. Ltd. - Robotics Foundation Model
- GEN-1
Generalist - Software
- GENE-26.5
Genesis AI - Robotics Foundation Model
- Lumo 2
Astribot - Robotics Foundation Model
- Rho-alpha
Microsoft - Robotics Foundation Model
Related Systems
- DYNA-1
Dyna Robotics - Robotics Foundation Model