
3-Finger Adaptive Robot Gripper
About
About 3-Finger Adaptive Robot Gripper
The 3-Finger Adaptive Robot Gripper uses articulated under-actuated fingers that conform around an object during closing. Pinch, wide and scissor modes support cylindrical, spherical, flat and irregular parts with one programmable end effector.
Position, speed and force settings are controlled through the robot interface, and object detection confirms whether a part has been acquired. Robotiq supplies integration kits, software and technical documentation for manufacturing, laboratory automation and manipulation research.
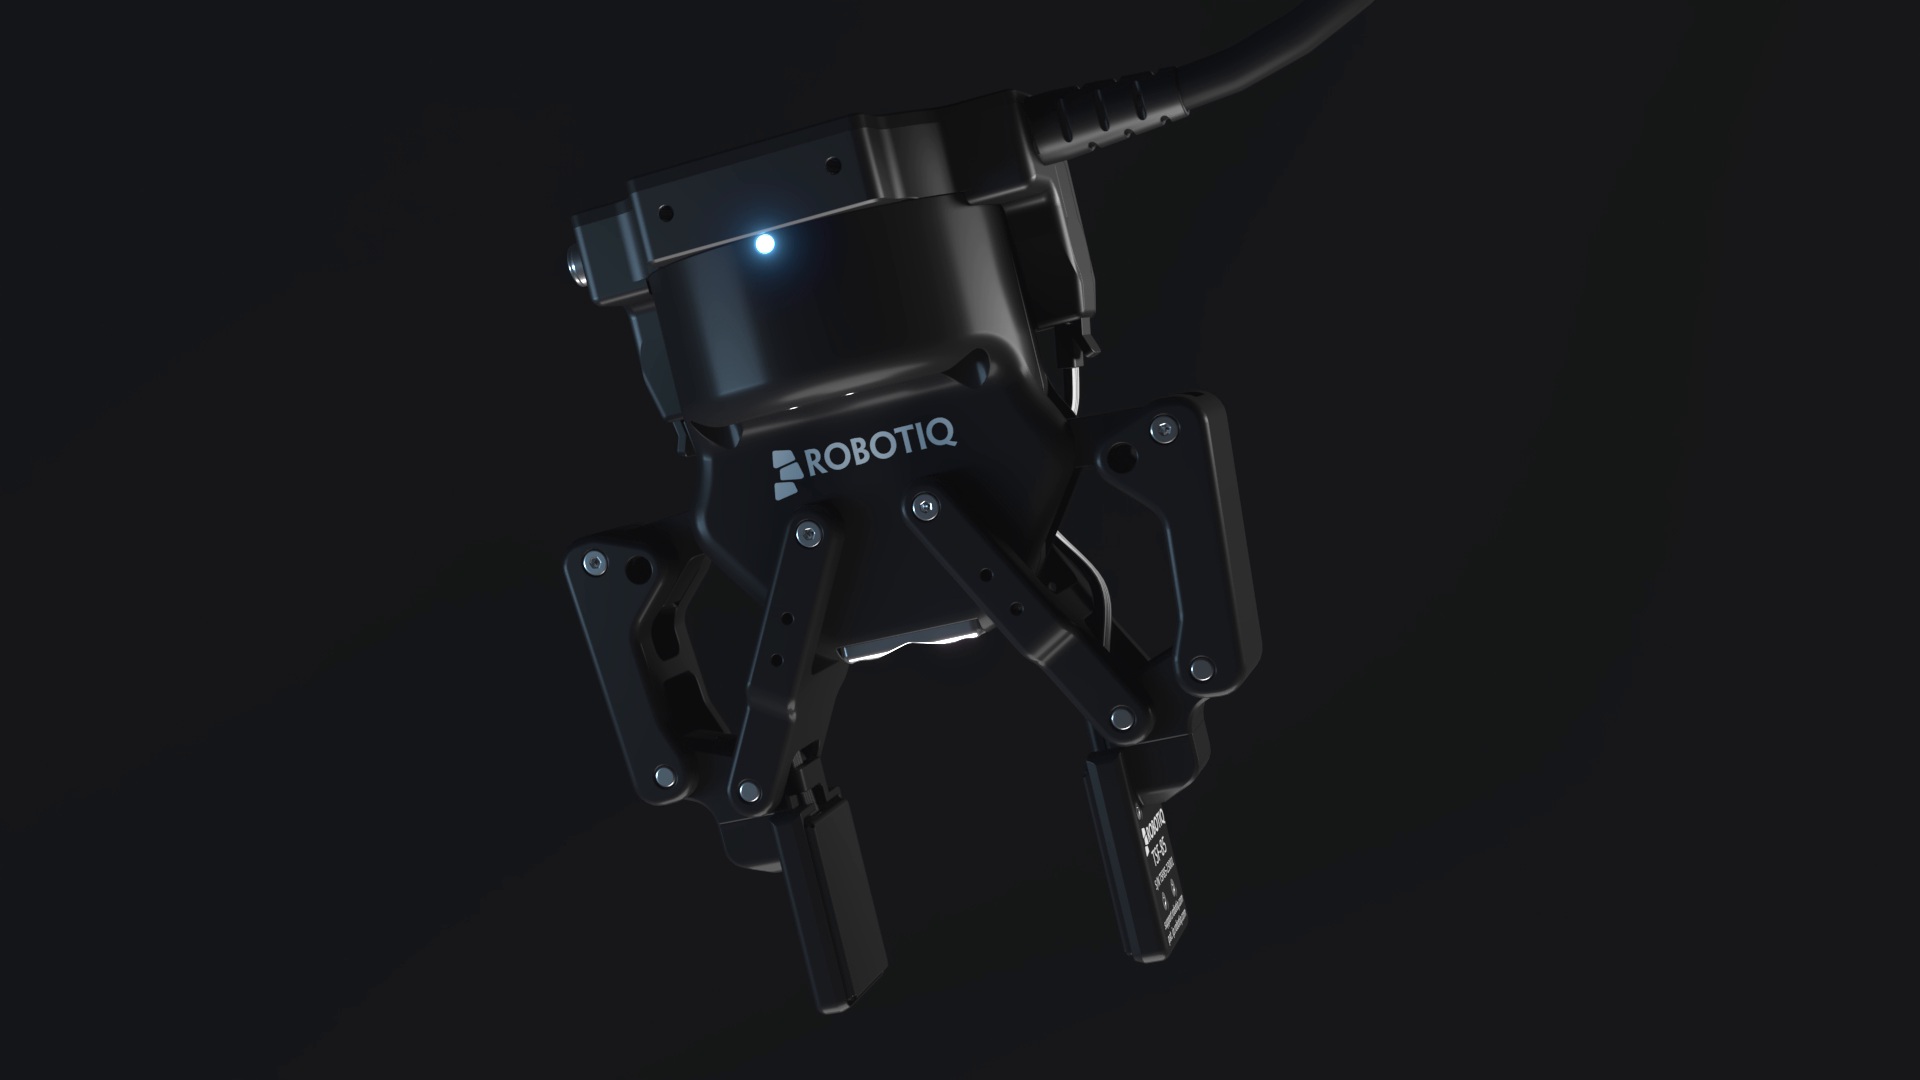
Capabilities
Source-backed capabilities
- Capability areas: Robotic grasping, Adaptive grasping
- Workflows: End-effector manipulation, Material handling
- Operating environments: Collaborative robots, advanced manufacturing cells, research labs and quality-testing setups
- Target markets: Manufacturers and labs needing articulated gripping without a full five-finger dexterous hand.
- Deployment model: Mounted as a three-finger adaptive end effector for cobots and industrial robot arms where flexible grasp geometry matters more than a simple parallel grip.
- Dense-clutter grasping
Research demonstration - 2021-06-07 - The paper learns to detect multi-modal grasps for dexterous grasping in dense clutter.
Source - Robotic grasping
Claimed - Robotiq presents its 3-Finger Adaptive Robot Gripper for flexible grasping, pick-and-place and machine-tending work using selectable grip modes and independent finger control.
Source - Pick and place
Claimed - Robotiq presents its 3-Finger Adaptive Robot Gripper for flexible grasping, pick-and-place and machine-tending work using selectable grip modes and independent finger control.
Source - Machine tending
Claimed - Robotiq presents its 3-Finger Adaptive Robot Gripper for flexible grasping, pick-and-place and machine-tending work using selectable grip modes and independent finger control.
Source
Research
- ROS End-Effector: A Hardware-Agnostic Software and Control Framework for Robotic End-Effectors
2023-07-22 - Research Publication - Open-access framework paper for hardware-agnostic end-effector control; the source documents support and real/simulated validation across diverse grippers and robotic hands.
Source
Resources
Media library
- 3-Finger gripper design view
image · Robotiq
Source - 3-Finger gripper integration
image · Robotiq
Source - 3-Finger gripper grasp operation
image · Robotiq
Source - 3-Finger Adaptive Robot Gripper main features
video · Robotiq
Source
Official operating references, exact-product application imagery and a verified overview video for the Robotiq 3-Finger Adaptive Robot Gripper.
- 3-Finger Adaptive Robot Gripper product reference
WEB · 3-Finger Adaptive Robot Gripper · Robotiq
Source - 3-Finger Adaptive Robot Gripper support library
WEB · 3-Finger Adaptive Robot Gripper · Robotiq
Source - 3-Finger Adaptive Robot Gripper instruction manual
PDF · 3-Finger Adaptive Robot Gripper · Robotiq
Source - 3-Finger Adaptive Robot Gripper product sheet
PDF · 3-Finger Adaptive Robot Gripper · Robotiq
Source
Context
Market context
Three-finger adaptive gripper for cobot/manufacturing work where a simple parallel gripper is not flexible enough.
- Target environment: Collaborative robots, advanced manufacturing cells, research labs and quality-testing setups
- Workflow context: Adaptive grasping, pick-and-place, quality testing and flexible object handling
- Customer context: Manufacturers and labs needing articulated gripping without a full five-finger dexterous hand.
- Deployment model: Mounted as a three-finger adaptive end effector for cobots and industrial robot arms where flexible grasp geometry matters more than a simple parallel grip.
- Commercial maturity: Commercial product with public payload, stroke and grip-force figures.
- Adoption constraints: Fit depends on robot compatibility, mounting, application payload, object geometry and whether three-finger adaptation is enough for the task.
- Adjacent products: Seed RH4D, qb SoftHand Industry, Unitree Dex1-1, adaptive gripper families
Comparable Systems
- GCKW Electric Actuator 3-Finger Gripper
CKD Corporation - Gripper
- 3FG15
OnRobot - Robotic Gripper
- 3FG25 Finger Gripper
OnRobot - Electric Gripper