
ExynView
About
About ExynView
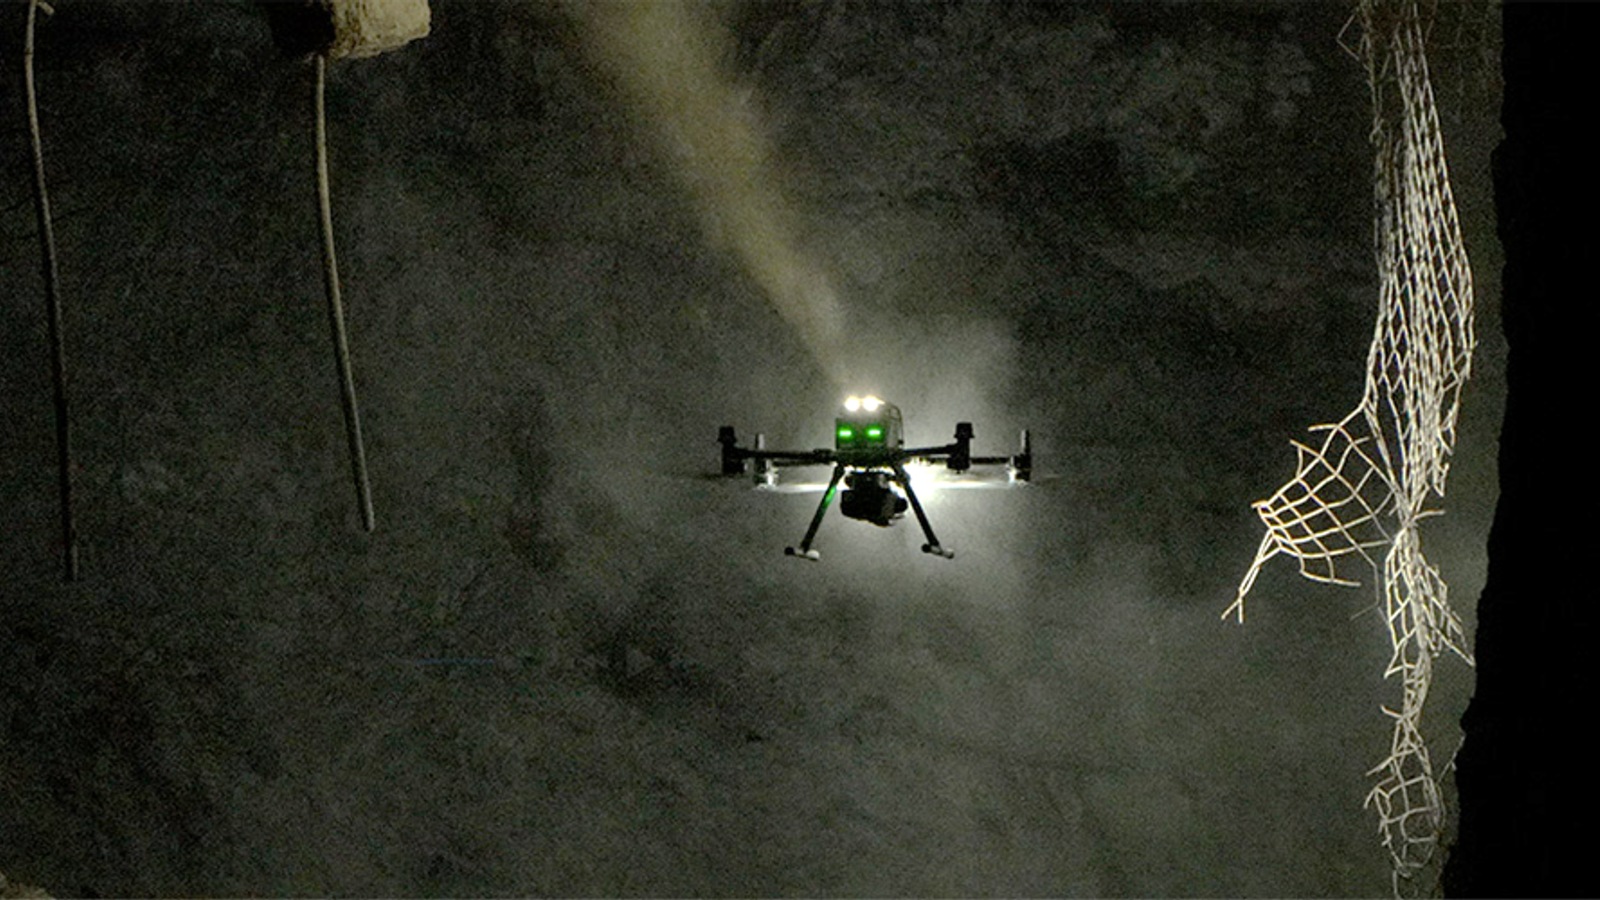
ExynView plans and executes autonomous Nexys missions through Fly-to and Exploration modes. Operators define an area of interest, send the mission to a Nexys-equipped robot and monitor its progress while communications are available; Nexys can then continue exploration with its data stored onboard.
After capture, ExynView processes Nexys logs into 3D models at the job site. Its workflow includes loop closure, ground-control-point or GNSS/RTK georeferencing, point-cloud colorization and 360-degree photosphere export. Finished data can be exported in LAS, PLY, XYZ and E57 formats for survey, BIM and reality-capture tools. Exyn describes batch post-processing as still in development, so it is not presented as a current production feature.
Context
Market context
ExynView is Exyn’s visualization and data-review software for analyzing captured 3D mapping, inspection and survey data.
- Target environment: Industrial sites, mines, infrastructure inspection workflows and field mapping programs.
- Workflow context: Post-mission visualization, 3D model review, inspection data handling and survey deliverables.
- Customer context: Survey teams, industrial inspection teams and customers using Exyn mapping data.
- Deployment model: Software layer used with Exyn's mapping and autonomy ecosystem.
- Commercial maturity: Public product with official Exyn documentation and field workflow positioning.
- Adoption constraints: Adoption depends on Exyn data capture, mapping accuracy, export workflow and site documentation needs.
- Market position: Data and visualization layer adjacent to ExynAI SDK and Nexys, not a robot-control system.
- Adjacent products: ExynAI SDK, Nexys, industrial mapping platforms
Related Systems
- Hovermap
Emesent - Autonomy Mapping Payload
- ExynAero
Exyn - Autonomous Drone
- Flyability Inspector
Flyability - Software Platform