
TORA-ONE
About
About TORA-ONE
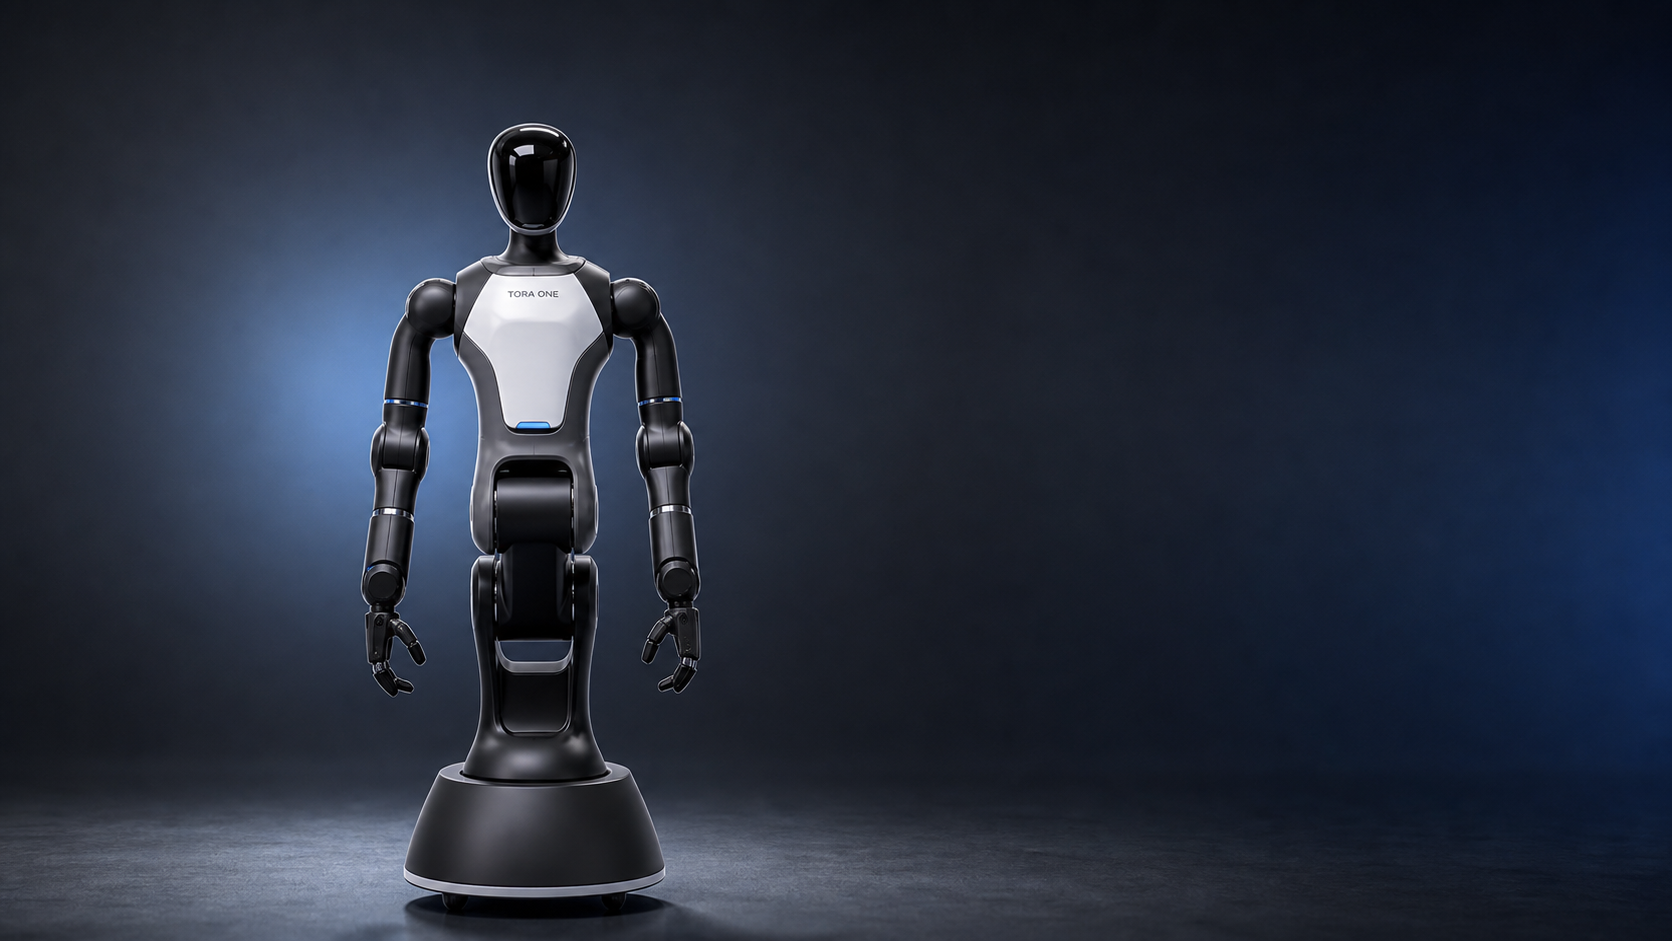
TORA-ONE is PaXini's wheeled tactile humanoid for manipulation in industrial, logistics and service environments. Its folding torso changes working height between 1.46 and 1.86 metres, while laser-SLAM navigation moves the platform between task locations. Two articulated arms carry four-finger hands that combine visual sensing with multidimensional tactile feedback.
The robot has 21 body degrees of freedom and 16 in each hand, including active and passive finger movement. Five RGB cameras and two depth cameras provide object and environmental information. Its VTLA model connects visual and tactile perception with handling, including object-pose estimation and grasping. PaXini rates each arm for a five-kilogram horizontal load including the hand. The platform is commercially offered for configurable applications, with tactile interaction and mobile manipulation defining its operating design.


Capabilities
Source-backed capabilities
- Operating environments: CES2026 exhibition booth, CES2026 exhibition manipulation setup
- Control modes: Autonomous
- Pick and place
Demonstrated - 2026-01-08 - Pick and place wafers in the CES manipulation demonstration. - environment: CES2026 exhibition manipulation setup
Source - Food preparation
Demonstrated - 2026-01-08 - Operate the ice-cream workflow, including levers, ingredients and cup delivery. - environment: CES2026 exhibition booth
Source
Timeline
- PaXini demonstrates tactile robots and dexterous hands at CES
2026-01-07 - Demonstration - TORA-ONE performed ice-cream preparation, including lever operation, ingredient handling and cup handover; TORA-DOUBLE ONE crossed obstacles and shook hands with visitors. The DexH13 hand mirrored gestures, grasped test tubes and cubes, and turned knobs using 1,140 tactile processing units.
Source - PaXini demonstrates TORA-ONE at the 2024 World Robot Conference
2024-08-27 - Demonstration - The configuration described in the report had 47 degrees of freedom, a 6 kg single-arm load capacity and nearly 2,000 tactile sensors in its hands. PaXini also presented the PX-6AX Gen 2 tactile sensor and DexH13 hand, combining tactile sensing with visual information for manipulation.
Source
Context
Market context
Humanoid system focused on tactile-driven manipulation.
- Target environment: Factories, warehouses, labs, service sites and controlled indoor environments where wheeled manipulation can operate safely.
- Workflow context: Autonomous navigation, object handling, dual-arm or arm-based manipulation, teleoperation and facility task execution.
- Customer context: Industrial operators, logistics teams, research labs and service organizations evaluating mobile manipulation.
- Deployment model: Commercial or available product positioned for customer use, integration or developer adoption.
- Commercial maturity: Publicly presented as commercial or available, with maturity depending on deployment scale and support coverage.
- Adoption constraints: Adoption depends on site fit, manipulation reliability, safety, navigation, integration effort and task economics.
- Market position: Tora One sits in the mobile-manipulation lane, using mobility plus arms to pursue practical physical tasks.
- Adjacent products: Kinisi 01, DexForce W1, Stretch RE2, Quanta X2