
Galbot G1
About
About Galbot G1
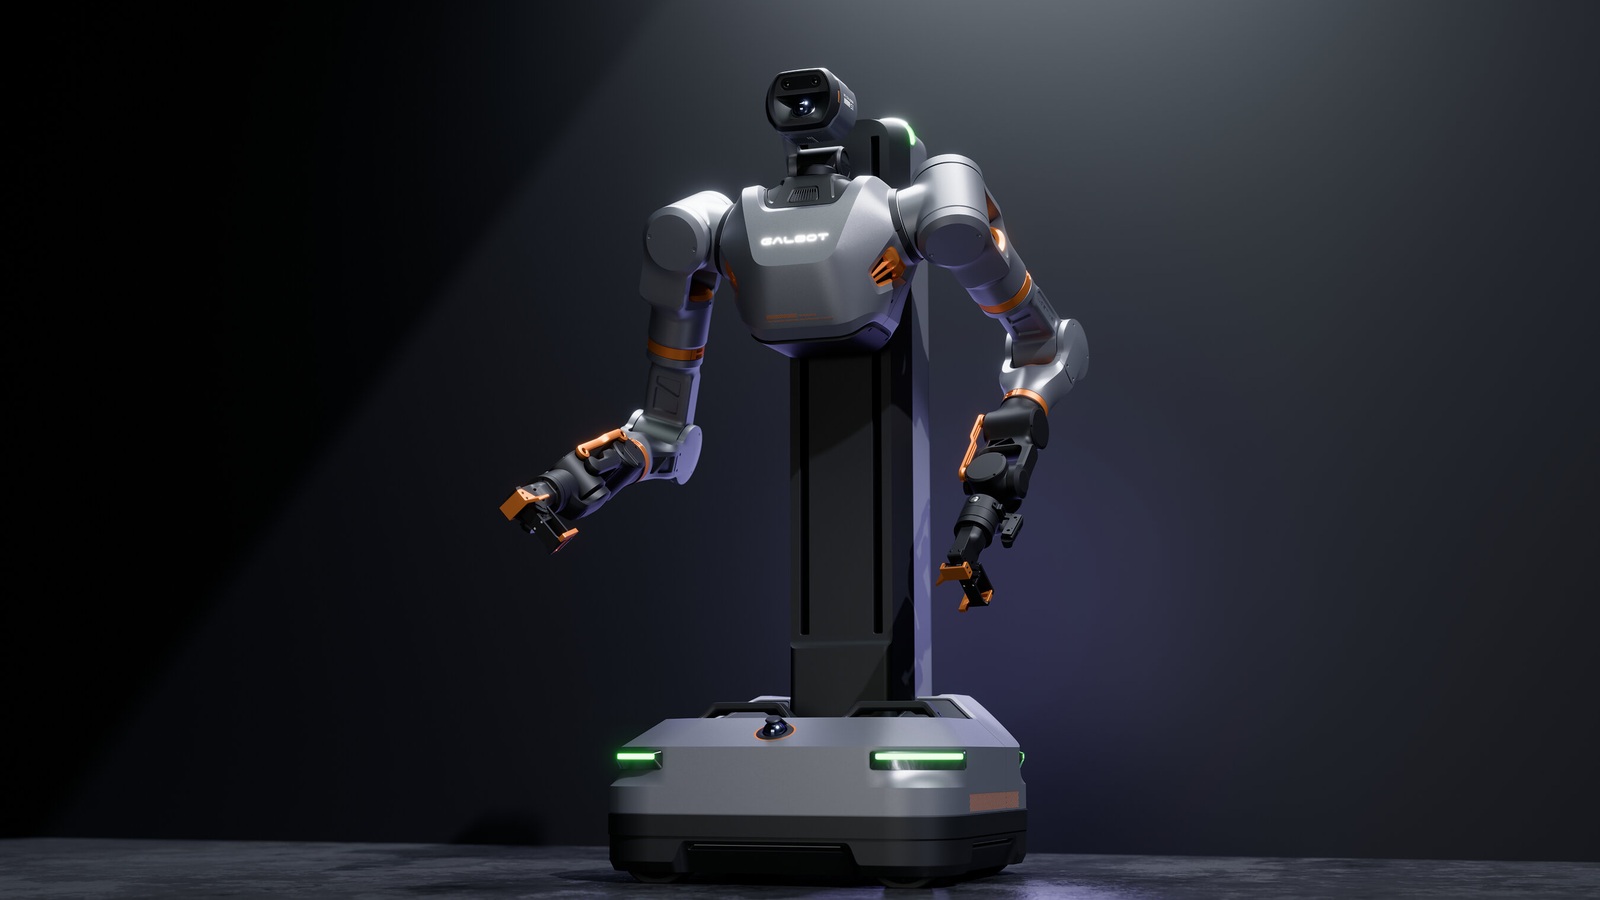
Galbot G1 is a wheeled dual-arm robot for retail, warehouse and industrial handling. An omnidirectional base, lifting body and seven-axis arms let it move between work areas and reach shelves at different heights. The platform can be configured with dexterous hands, suction tools or grippers, with a stated five-kilogram payload per arm and ten kilograms combined.
Galbot's AstraBrain software connects perception, decision-making and physical action. Head and wrist cameras, wrist force sensors and base-mounted lidar support object handling and navigation. Galbot offers G1 commercially, with applications including picking and delivering retail products, replenishment, inventory and industrial material handling. The robot has also been used for medicine retrieval and packing in a Beijing pharmacy; task performance and operating scale remain specific to the installed application.


Capabilities
Source-backed capabilities
- Operating environments: Drugstore in Haidian District, Beijing
- Control modes: Autonomous
- Medication picking and delivery
Customer-site use - 2026-03-12 - Retrieve and package medicine orders for a smart pickup cabinet in a Beijing pharmacy. - environment: Drugstore in Haidian District, Beijing
Source
Deployments
- Commercial Activity
3 planned retail sites - 2026-08-31 - autonomous retail stores - Galbot announced three Hong Kong retail sites scheduled to open on September 1, following an August 31 launch ceremony.
Source - Customer Site
Galbot G1 pharmacy service in Beijing - 2026-03-13 - Beijing pharmacy operator - retail pharmacy automation - Galbot G1 was reported operating in a licensed pharmacy pilot in Beijing Haidian District, picking and packaging medicines for a smart pickup cabinet.
Source
Supply
Supply / Components
- G1
Agx Orin 64gb For Galbot G1 - Compute & Control - NVIDIA - Galbot G1 uses an NVIDIA AGX Orin 64GB platform rated at 275 TOPS - source: developer.galbot.com
Source
Research
- GigaBrain-0.7: Scaling Embodied Foundation Models to Emergent Capabilities with a Three-System Architecture
2026-08-16 - Research Publication - GigaBrain-0.7 combines action control, understanding and planning, and world-model prediction in a three-system embodied model. GigaAI reports training on over 37,000 hours of heterogeneous data and physical evaluation on Maker H01 and AgileX PiPER-family manipulators.
Source - Galbot C++ and Python SDK
Research Publication - Galbot provides C++/Python SDK interfaces, model-specific examples, libraries and documentation for G1, S1 and G3. The current release distinguishes robot environment compatibility and supports installation on different onboard compute configurations.
Source - Galbot MCAP to LeRobot converter
Research Publication - Galbot releases a converter from G1 MCAP recordings to LeRobot v2.1 datasets. The implementation handles four camera streams, joint/action vectors and episode metadata, producing parquet and encoded video outputs.
Source - ioailab Galbot G1 simulation toolkit
Research Publication - ioailab provides Galbot G1 configurations, Isaac Lab task registrations, action/sensor helpers and planner agents. The source supports simulated pick, navigation and placement workflows, demonstration generation, policy training and evaluation.
Source
Resources
Media library
- Galbot G1 autonomous robot-operated store
video · Galbot
Source
Official G1 product, operating and SDK references with exact retail and pharmacy deployment imagery and a verified Galbot video.
- Galbot G1 quick-use manual V2.0
WEB · Galbot G1 manual V2.0 · Galbot
Source - Galbot G1 Python SDK examples
WEB · GalbotSDK 1.7.0 for G1 · Galbot
Source - Galbot G1 Pro product brochure (2025)
PDF · G1 Pro configuration; 2025 brochure · Galbot
Source
Timeline
- Galbot demonstrates G1 at Hong Kong retail launch
2026-08-31 - Demonstration - G1 completed ordering, picking and handover without remote control during the launch demonstration. Three stores were scheduled to open on September 1 at the Hung Hom waterfront, Wan Chai waterfront and Kai Tak Sports Park.
Source - Galbot G1 operates in a Beijing pharmacy pilot
2026-03-13 - Deployment - The roughly 70-square-metre pharmacy used an optimized layout accommodating about 5,000 drug stock-keeping units. Pharmacists retained prescription review and medication guidance while the robot assisted with order handling and inventory work.
Source
Context
Market context
Galbot G1 is a developer-oriented mobile manipulation platform for embodied AI, dexterous grasping and robot-learning data workflows.
- Target environment: Robotics labs, developer environments and controlled indoor manipulation settings.
- Workflow context: Mobile manipulation, dexterous grasping, robot-learning data collection and manipulation policy development.
- Deployment model: Developer platform for training, testing and demonstrating mobile manipulation capabilities.
- Commercial maturity: Public developer mobile manipulation platform for embodied AI and robot-learning workflows.
- Adoption constraints: Requires software integration, task design, manipulation reliability and controlled operating conditions.
- Market position: Developer-facing mobile manipulation robot for embodied AI and robot-learning workflows.
- Adjacent products: Mobile manipulator for dexterous grasping, manipulation policy development and robotics lab use.