
1X Technologies
About
About 1X Technologies
1X develops NEO, a soft-bodied bipedal robot designed for assistance in homes, and the Redwood generalist AI used to learn and repeat tasks. The current system combines compliant tendon-driven actuation, onboard perception and compute, two dexterous hands, voice interaction, app control and automatic charging.
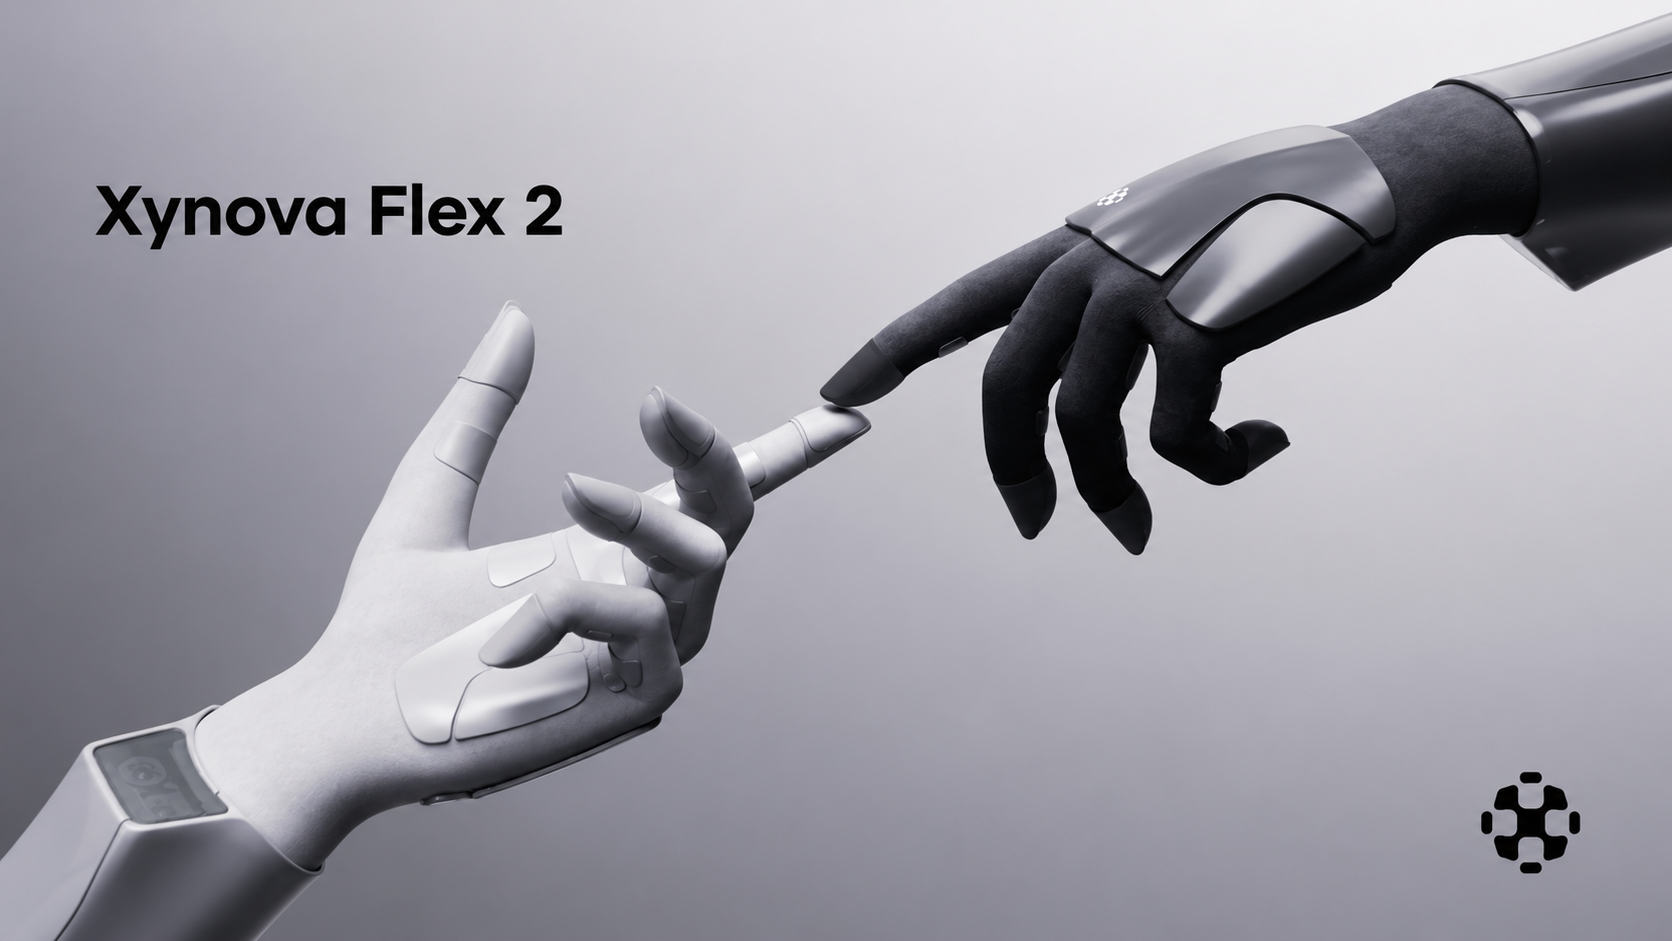
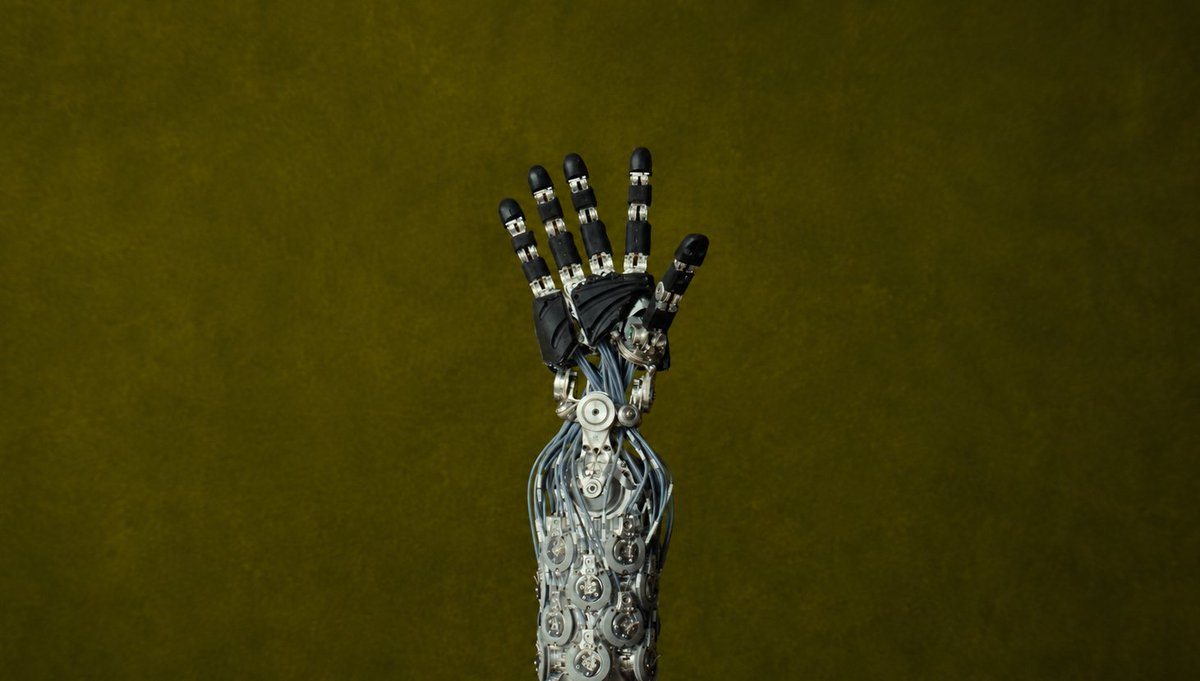
NEO is sold through an Early Access ownership offer and a later subscription option, with US deliveries stated to begin in 2026. Initial capability is deliberately bounded: Redwood supplies basic autonomy, while scheduled Expert Mode lets an authorised remote operator supervise unfamiliar chores. In July 2026, 1X detailed the 25-degree-of-freedom hand assemblies shipping on NEO and said hundreds had already been produced on a dedicated line.
Articles


Products
Operations
Facilities & manufacturing
- Production setup
2024-04-02 - In April 2024, 1X said it was developing a Moss facility intended to place actuator manufacturing, robot assembly and testing next to its engineering campus. - 1X Moss manufacturing facility programme — actuator manufacturing, robot assembly and testing planned together - 1X Moss manufacturing facility programme
Source
Production capacity
- Production capacity
2026-04-30 - 1X says its Hayward NEO Factory is live and, with San Carlos coming online later in 2026, the company has capacity to produce up to 10,000 robots per year. This is stated capacity rather than confirmed annual output. - NEO Factory plus San Carlos ramp - Hayward, California
Source - Production capacity
2026-04-30 - 1X says planned automation increases and the San Carlos facility are expected to scale production toward 100,000-plus robots annually by the end of 2027. This is a forward target, not current installed capacity. - NEO production network target - California
Source
Orders & commitments
- Order / commitment
2026-09-18 - In a Relentless interview published on 18 September 2026, 1X CEO Bernt Børnich outlined a target to manufacture and ship 50,000 NEO home robots in 2027. - NEO home robots; annual shipment target
Source
Supply
Supply chain relationships
- Hand production capacity
Integration - Product - 1X reports hundreds of hands have already come off a scalable line and says the line has capacity to produce 10,000 hands this year.
Source - Hand stack internalization
Integration - Product - 1X says every NEO hand is built end-to-end in-house, from tendon materials and 1X Motors through soft polymers, skin, and tactile sensing.
Source - NEO critical-component internalization
Integration - Product - 1X says it designs and manufactures NEO critical components in-house, including motors, batteries, structures, transmission systems, soft goods, and sensors.
Source - NEO factory vertical integration
Integration - Factory - 1X describes the Hayward NEO Factory as a vertically integrated humanoid robot factory and says it maintains end-to-end control across critical component manufacturing.
Source - NEO annual production capacity
Integration - Production Capacity - 1X says the Hayward factory and San Carlos ramp give it capacity for up to 10,000 NEOs per year, with automation intended to scale toward 100,000+ units annually by the end of 2027.
Source - NVIDIA
Inbound - Compute & Control - 1X NEO uses NVIDIA Jetson Thor for onboard multimodal inference
Source - NVIDIA
Inbound - Software - 1X NEO uses NVIDIA Argus to process camera data for low-latency visual inference
Source - Mecka AI
Inbound - Data - Mecka AI supplies human-activity training data for 1X robot-learning programme
Source
Funding
- 2024-01-13 - Series B - $100M - 1X Technologies Closes $100 Million Series B
1X announced a $100M Series B financing round. - source: 1x.tech
- 2023-03-23 - Series A2 - $23.5M - 1X raises $23.5M Series A2 led by OpenAI Startup Fund
1X announced a $23.5M Series A2 round led by OpenAI Startup Fund to accelerate humanoid robotics development. - source: 1x.tech
Investors
- Sandwater - Participant - Unknown - 2 funding events - repeat backer - first seen 2023-03-23 - latest 2024-01-13
- Skagerak Capital - Participant - VC - 2 funding events - repeat backer - first seen 2023-03-23 - latest 2024-01-13
- Alliance Ventures - Participant - VC - 1 funding event - first seen 2023-03-23
- EQT Ventures - Lead - VC - 1 funding event - first seen 2024-01-13
- Nistad Group - Participant - Angel / Individual - 1 funding event - first seen 2024-01-13
- OpenAI Startup Fund - Lead - VC - 1 funding event - first seen 2023-03-23
- Samsung NEXT - Participant - Corporate / CVC - 1 funding event - strategic/corporate - first seen 2024-01-13
- Tiger Global - Participant - VC - 1 funding event - first seen 2023-03-23
Team
- Bernt Øyvind Børnich - Founder and Chief Executive Officer
- Dar Sleeper - VP of Product and Design - Directs product and industrial-design work for NEO as 1X prepares the home robot for customer delivery.
- Bill Nash - Chief Financial Officer - Leads finance organization building, strategic partnerships, and growth-stage financial controls.
- Tom Sanocki - VP of Engineering - Directs the software-engineering organisation supporting NEO, Redwood AI and the associated customer platform.
- Sam Sinha - Founding AI Researcher and Head of World Models - Leads 1X World Model Lab work on embodied world-model pretraining for humanoid intelligence.
Research
- 1X Technologies introduces 1XWM world model for NEO robot
2026-01-12 - Research Publication - The 14-billion-parameter video backbone was adapted using 900 hours of egocentric human video and 70 hours of NEO robot data. An inverse-dynamics model converts generated video into robot actions; its training used 400 hours of unfiltered robot data. 1X tested each task 30 times and reported remaining difficulties with depth grounding, pouring and drawing.
Source - 1X releases the 1X World Model for humanoid policy evaluation and scaling
2025-06-16 - Research Publication - The model predicts future video and final-state task success from initial observations and low-level robot action sequences. 1X used the forecasts to compare policy architectures and training checkpoints, finding correlation with real-world evaluation results. The model still struggled with interactions involving held-out objects; added task-interaction data improved its physical predictions.
Source - 1X introduces Redwood AI for NEO Gamma mobile manipulation
2025-06-10 - Research Publication - Redwood is a 160-million-parameter model running on the robot’s onboard GPU at about 5 Hz. Its outputs coordinate arm, hand, walking and pelvis commands, allowing whole-body and multi-contact manipulation. Training uses successful and unsuccessful episodes from EVE and NEO; a separate offboard speech model converts spoken requests into goals.
Source
Resources
Media library
- NEO home workflow
image · Courtesy of 1X
Source - NEO profile view
image · Courtesy of 1X
Source - 1X World Model
video · 1X
Source
Official technical reports, developer material, press-kit assets and portfolio media for 1X Technologies.
- 1X press gallery
WEB · 1X product portfolio · 1X Technologies
Source - NEO press asset pack
ZIP · NEO · 1X Technologies
Source - 1X World Model: Evaluating Bits, not Atoms
PDF · 1X World Model · 1X Technologies
Source - 1X World Model Challenge repository
WEB · 1X World Model Challenge · 1X Technologies
Source
Timeline
Events
- 2026-08-26 - Market Signal - Report says SoftBank is discussing a majority stake in 1X
The Information attributed the talks to people familiar with the matter, and Reuters said it could not independently confirm the report. SoftBank declined to comment and 1X did not immediately respond to Reuters. No agreement had been announced, and the reported terms remained subject to change.
Source - 2026-07-09 - Production Milestone - 1X reports hundreds of NEO hands produced on line rated for 10,000 in 2026
Each hand assembly has 25 force-controlled degrees of freedom: 22 in the fingers and palm, plus three at the wrist. The dedicated line uses full end-of-line testing and is rated to produce 10,000 hands during 2026. 1X manufactures the assemblies in-house, from tendon materials and motors to soft polymers, skin and tactile sensing.
Source - 2026-07-02 - Executive Hire - 1X appoints Bill Nash as chief financial officer
Bill Nash previously served as chief financial officer at Ursa Major and Cruise. At Cruise, Nash worked on capital raising, strategic partnerships and operational expansion; at Ursa Major, he supported propulsion-system development. Nash holds an MBA from Wharton, an electrical-engineering master’s degree from Georgia Tech and a bachelor’s degree from the US Naval Academy.
Source - 2026-06-25 - Executive Hire - 1X appoints Tom Sanocki as VP of Engineering
Sanocki was the first Engineering Director for Avatars at Roblox and led four engineering teams on Meta’s Horizon Worlds. He founded a virtual-reality character platform acquired by Lytro and previously worked on Bungie’s Destiny 1 and Pixar films. He earned a Computer Science Engineering degree at Princeton University and will help develop 1X’s NEO developer platform.
Source - 2026-06-24 - Market Signal - 1X accelerates plans to deliver NEO to developers
The developer initiative targets researchers, robotics startups and enterprise integrators. Børnich said the initiative would keep the home-customer roadmap in place and contribute improvements to the consumer product. 1X planned to announce specific delivery dates and programme details later.
Source - 2026-06-04 - Market Signal - 1X launches World Model Lab for embodied foundation-model pretraining
1X launched the 1X World Model Lab to focus on large-scale embodied world-model pretraining for humanoid robots. The lab is led by Sam Sinha, who previously worked on large-scale multimodal generative foundation models at Luma AI. 1X said the lab will combine web-scale media, egocentric human videos, simulation, dexterous teleoperated robot data, and on-policy NEO data to improve real-world humanoid deployment.
Source - 2026-04-30 - Facility Opening - 1X brings NEO Factory online in Hayward, California
The operational Hayward site employs more than 200 people, with current units prioritized for testing in 1X team members’ homes. 1X manufactures motors, batteries, structures, transmissions, soft goods and sensors in-house; its latest NEO iteration went from CAD to walking in one month. The factory is ramping toward 10,000 robots annually; further automation and a planned San Carlos facility support a target above 100,000 annually by the end of 2027.
Source - 2026-03-17 - Capability - 1X details NVIDIA compute and vision stack for NEO
Jetson Thor runs NEO multimodal models locally for low-latency perception, reasoning and control. NVIDIA Argus processes camera data within NEO perception stack for low-latency visual inference. 1X uses Blackwell HGX B200 GPUs to train robot foundation models on simulated and real-world data.
Source - 2026-01-12 - Research Publication - 1X Technologies introduces 1XWM world model for NEO robot
The 14-billion-parameter video backbone was adapted using 900 hours of egocentric human video and 70 hours of NEO robot data. An inverse-dynamics model converts generated video into robot actions; its training used 400 hours of unfiltered robot data. 1X tested each task 30 times and reported remaining difficulties with depth grounding, pouring and drawing.
Source - 2025-12-11 - Partnership - 1X and EQT agree framework for potential NEO rollout
Each EQT portfolio company would independently decide whether and how to implement the robots. The initial focus spans manufacturing, logistics, facilities, warehousing and healthcare operations. The partners planned initial US pilots during 2026, followed by expansion into Europe and Asia.
Source - 2025-11-13 - Partnership - 1X and IFS partner to industrialize humanoid robotics for asset-intensive sectors
The partnership combines 1X humanoid robots with IFS.ai industrial AI software. The companies plan to develop and deploy production-ready robotics solutions with select customers. Target sectors include manufacturing, utilities, aviation, and other asset-intensive operating environments.
Source - 2025-10-28 - Product Launch - 1X opens NEO home robot preorders
The new platform succeeds NEO Beta and NEO Gamma and uses tendon-driven actuation with a soft body. Owners can schedule a 1X Expert to guide unfamiliar chores while the robot learns. Early Access cost $20,000 with priority delivery in 2026; a later subscription option was priced at $499 per month.
Source - 2025-06-16 - Research Publication - 1X releases the 1X World Model for humanoid policy evaluation and scaling
The model predicts future video and final-state task success from initial observations and low-level robot action sequences. 1X used the forecasts to compare policy architectures and training checkpoints, finding correlation with real-world evaluation results. The model still struggled with interactions involving held-out objects; added task-interaction data improved its physical predictions.
Source - 2025-06-10 - Research Publication - 1X introduces Redwood AI for NEO Gamma mobile manipulation
Redwood is a 160-million-parameter model running on the robot’s onboard GPU at about 5 Hz. Its outputs coordinate arm, hand, walking and pelvis commands, allowing whole-body and multi-contact manipulation. Training uses successful and unsuccessful episodes from EVE and NEO; a separate offboard speech model converts spoken requests into goals.
Source - 2025-03-18 - Partnership - 1X and NVIDIA collaborate on NEO Gamma autonomy research
The teams trained a single end-to-end GR00T N1 model over one week in a 1X employee’s home. NEO Gamma autonomously grasped a cup, transferred it between hands and placed it in a dishwasher. 1X supplied a dataset API and an inference SDK supporting a continuous 5 Hz vision-action loop with onboard or offboard GPUs.
Source - 2025-01-27 - Acquisition - 1X acquires Kind Humanoid
Kind Humanoid had developed Mona, a home-focused humanoid robot. 1X positioned the deal as a way to accelerate development of humanoid robots for household use.
Source - 2024-08-30 - Product Launch - 1X unveils NEO Beta humanoid robot for consumer home use
NEO Beta was a bipedal prototype designed for home use and close interaction with people. 1X planned to place a limited number of units in selected homes during 2024 for research and development. The design was intended for scaled manufacturing at 1X’s factory in Moss, Norway.
Source - 2024-04-02 - Market Signal - 1X outlines vertically integrated manufacturing site in Moss
The planned site would co-locate actuator manufacturing, robot assembly and testing. 1X positioned the facility next to its Moss campus and engineering team to shorten feedback loops. The company described the programme as supporting vertically integrated EVE and NEO production.
Source - 2024-01-13 - Funding - 1X Technologies Closes $100 Million Series B
The proceeds were intended to introduce NEO to consumers and support existing enterprise clients in logistics and guarding. The financing brought 1X’s fundraising to more than $125 million in less than 12 months, following the March 2023 round led by OpenAI and Tiger Global. A secondary transaction increased Sandwater’s stake and included Samsung NEXT, Skagerak Capital and the Nistad group.
Source - 2023-03-23 - Funding - 1X raises $23.5M Series A2 led by OpenAI Startup Fund
1X announced a $23.5M Series A2 funding round. OpenAI Startup Fund led the round. The financing was positioned to accelerate humanoid robotics R&D and product development.
Source - 2023-03-06 - Org Change - Halodi Robotics rebrands to 1X Technologies
The name refers to the company’s intention for androids to work alongside people at normal human speed. The wider brand rollout was planned for spring 2023, following the corporate name change. At the time, 1X described US EVE deployments and a manufacturing-capacity goal of 140 robots across Norway and Dallas.
Source
Notes
Profile notes
- NEO's early home service combines autonomy with scheduled remote assistance
reviewed 2026-07-18 - 1X is placing NEO in homes before the robot can complete every household task autonomously. NEO handles familiar work through its autonomy system, while scheduled Expert Mode allows remote specialists to guide the robot through tasks it does not yet know.
Source - 1X shifted from wheeled industrial androids toward a home humanoid programme
reviewed 2026-07-20 - The company now called 1X began as Halodi Robotics and commercialised the wheeled EVE platform for guarded and industrial environments. After rebranding, it made the bipedal NEO home robot the centre of its public strategy while retaining EVE as a separate deployed platform. NEO is therefore a change in target environment and embodiment, not simply the next generation of the same industrial robot.
Source
Relations
Relationships
- NVIDIA
Autonomy Technology Collaborator - 1X and NVIDIA collaborated on NEO autonomy tooling, dataset workflows, and GR00T N1 work.
- Kind Humanoid
Acquired Company - 1X acquired Kind Humanoid, developer of the Mona home humanoid robot.
- EQT
Commercial Order - 10,000 NEO robots to EQT portfolio companies by 2030
- Mecka AI
Partner - Mecka AI has worked with 1X Technologies as an early robotics customer for human activity data used in robot learning.
Context
Comparable profiles
- Figure AI
stack adjacency - Bipedal Locomotion · Dexterous Manipulation · Vision Language Action Control
- UBTECH Robotics
stack adjacency - Bipedal Locomotion · Dexterous Manipulation
- DexForce
stack adjacency - Dexterous Manipulation · Vision Language Action Control
- Apptronik
stack adjacency - Bipedal Locomotion · Dexterous Manipulation
- RobotEra
stack adjacency - Bipedal Locomotion · Dexterous Manipulation
- Foundation Robotics
stack adjacency - Bipedal Locomotion · Dexterous Manipulation
- AgiBot
stack adjacency - Bipedal Locomotion · Dexterous Manipulation
- Zhejiang Humanoid
stack adjacency - Bipedal Locomotion · Dexterous Manipulation
- Persona AI
stack adjacency - Dexterous Manipulation
- WIRobotics
stack adjacency - Dexterous Manipulation
- CASBOT
stack adjacency - Bipedal Locomotion
- Unitree
stack adjacency - Bipedal Locomotion
Shared workflows
- Enchanted Tools
workflow adjacency - Humanoid Service Robot Builder
- Engineered Arts
workflow adjacency - Humanoid Service Robot Builder
- Noetix Robotics (松延动力)
workflow adjacency - Humanoid Service Robot Builder
- RealMan Intelligent Technology (Beijing) Co., Ltd.
workflow adjacency - Humanoid Service Robot Builder
- IntBot
workflow adjacency - Humanoid Service Robot Builder
- AiMOGA Robotics
workflow adjacency - Humanoid Service Robot Builder
- Standard Bots
workflow adjacency - Industrial Task Execution
- Astribot
workflow adjacency - Humanoid Service Robot Builder
- Holiday Robotics
workflow adjacency - Industrial Task Execution
- Haier Group
workflow adjacency - Humanoid Service Robot Builder
- Kinetix AI
workflow adjacency - Humanoid Service Robot Builder
- Macco Robotics
workflow adjacency - Humanoid Service Robot Builder
Context tags
- Humanoid service robot builder - Workflow - Core peer group: Neo/NEO humanoid for service and home contexts
- Dexterous manipulation - Capability - Hand and arm manipulation disclosed
- Industrial task execution - Workflow - Initial deployment focus on industrial and logistics tasks
- Vision-language-action control - Capability - Embodied AI approach for robot task learning
- Robot OEM - Stack Layer - Builds complete NEO humanoid robot system
- Bipedal locomotion - Capability - NEO demonstrated walking, sitting and human-like mobility
- Pilot deployments - Commercial Stage - Pilot deployments with disclosed customers
- Factories - Customer Environment - Initial target environments include industrial facilities