
AGIBOT G1
About
About AGIBOT G1
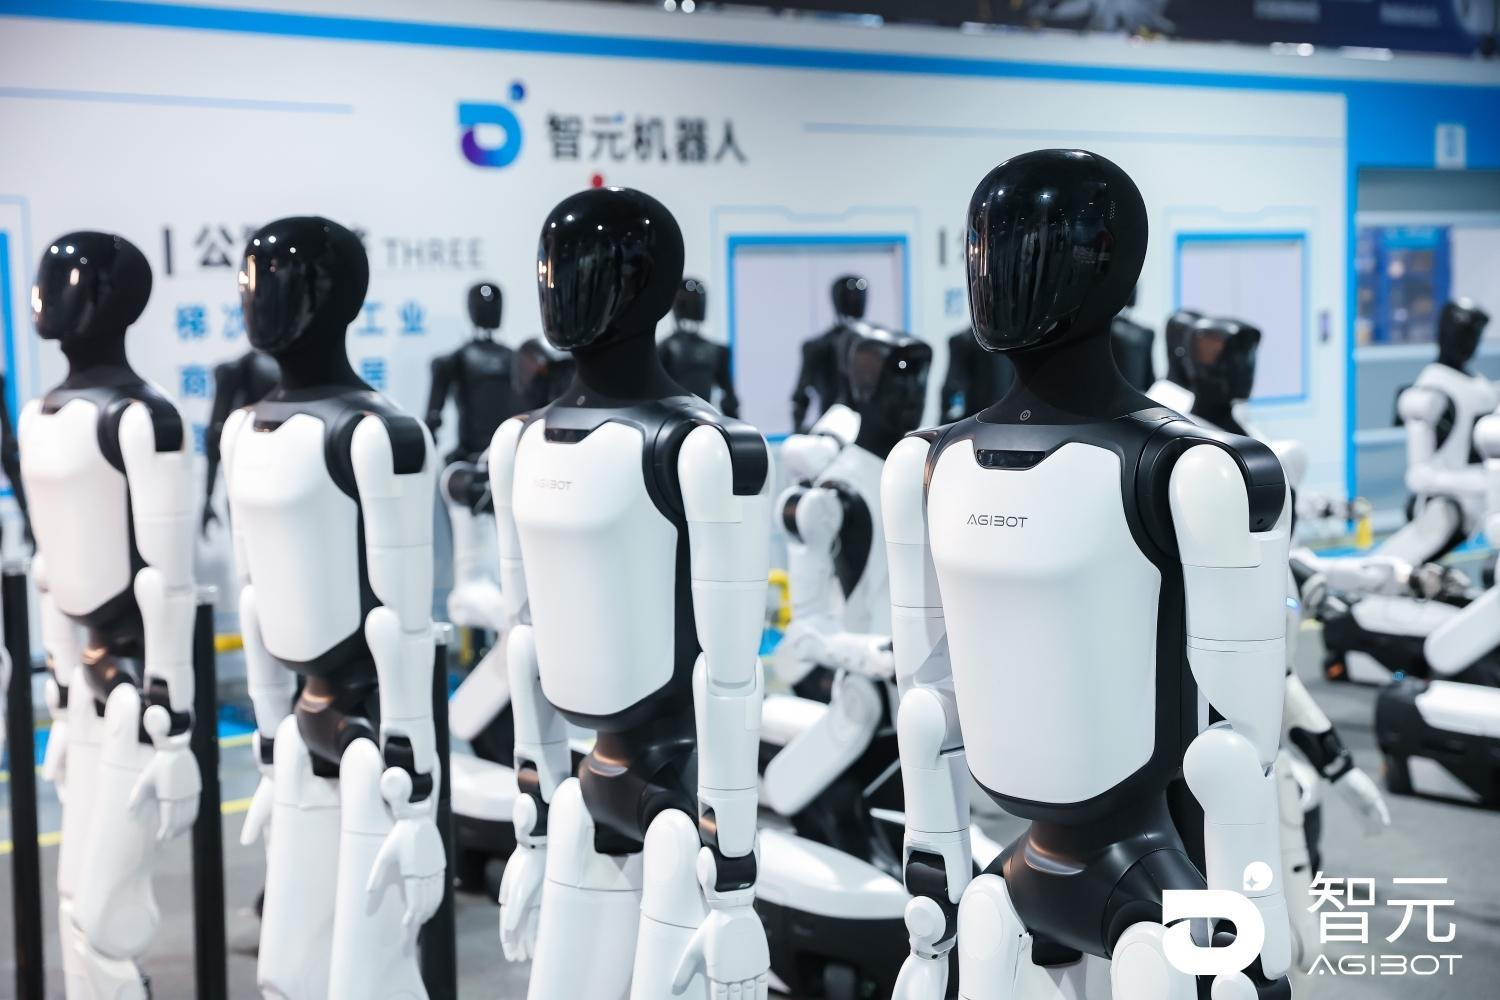
AGIBOT G1 is a wheeled dual-arm platform for collecting robot training data and deploying learned models. Its adjustable upper body combines head and waist movement with arms, end effectors and a mobile chassis, giving developers a way to record coordinated manipulation and navigation workflows. AgiBot supports VR and motion-capture teleoperation alongside full-body joint-data recording.
The platform uses a Jetson AGX Orin computer, multiple RGB-D and fisheye cameras, and six-axis force sensing on both arms. Data collection combines local recording with cloud transfer, validation and review. The chassis turns in place, while the height-adjustable body expands the working area around shelves and work surfaces. The configuration has twenty degrees of freedom excluding end effectors and more than four hours of runtime. AgiBot offers the platform through direct enquiries for industrial, commercial and domestic development applications.


Capabilities
Source-backed capabilities
- Control modes: Vr Or Motion Capture Teleoperation
- Multimodal data collection
Claimed - Record full-body joint data during VR- or motion-capture-based remote operation.
Source
Observed use
Exact-product configurations are shown without inferring supply, purchase, customer status, standard fit, deployment or partnership.
- NVIDIA Isaac Sim
Digital Simulation - Tested With - Simulated - AGIBOT G1 has a digital robot asset in the robot_usds library for Isaac Sim and ROS 2 control. This records a simulation configuration.
Source
Research
- GigaBrain-0.7: Scaling Embodied Foundation Models to Emergent Capabilities with a Three-System Architecture
2026-08-16 - Research Publication - GigaBrain-0.7 combines action control, understanding and planning, and world-model prediction in a three-system embodied model. GigaAI reports training on over 37,000 hours of heterogeneous data and physical evaluation on Maker H01 and AgileX PiPER-family manipulators.
Source - LingBot-VLA: A Pragmatic VLA Foundation Model
2026-01-26 - Research Publication - LingBot-VLA is a vision-language-action model and software release evaluated on the GM-100 benchmark with AgiBot G1, AgileX and Galaxea R1Pro robots.
Source - Genie Sim 3.0: A High-Fidelity Comprehensive Simulation Platform for Humanoid Robot
2026-01-05 - Research Publication - Genie Sim combines scene generation, synthetic manipulation data and automated policy evaluation. The paper describes more than 10,000 hours across 200 tasks; four-task physical transfer experiments use AgiBot G1, while G1 and G2 supply simulated data and benchmarks.
Source - FiveAges robot_usds simulation asset library
Research Publication - A shared library of robot USD assets for ROS 2 control and Isaac Sim development, with configurable robot and end-effector models.
Source
Timeline
- Galaxea R1 Pro appears in LingBot-VLA’s real-world benchmark
2026-01-27 - Research Publication - The model used 20,000 hours of real-world pretraining data from nine dual-arm robot configurations. The release provided depth-free and depth-distilled model variants, with evaluation separating complete task success from partial success.
Source
Context
Comparable Systems
- W1 Pro
DexForce - Semi Humanoid
- AlphaBot 2
AI2 Robotics - Semi Humanoid
- Galaxea R1 Pro
Galaxea Dynamics - Semi Humanoid
- RealBot-01
RealMan Intelligent Technology (Beijing) Co., Ltd. - Semi Humanoid
- RealBot-L2
RealMan Intelligent Technology (Beijing) Co., Ltd. - Semi Humanoid
- RealBot-S2
RealMan Intelligent Technology (Beijing) Co., Ltd. - Semi Humanoid
Related Systems
- ψ-SynRobot
PsiBot - Semi Humanoid