
Menlo Research
About
About Menlo Research
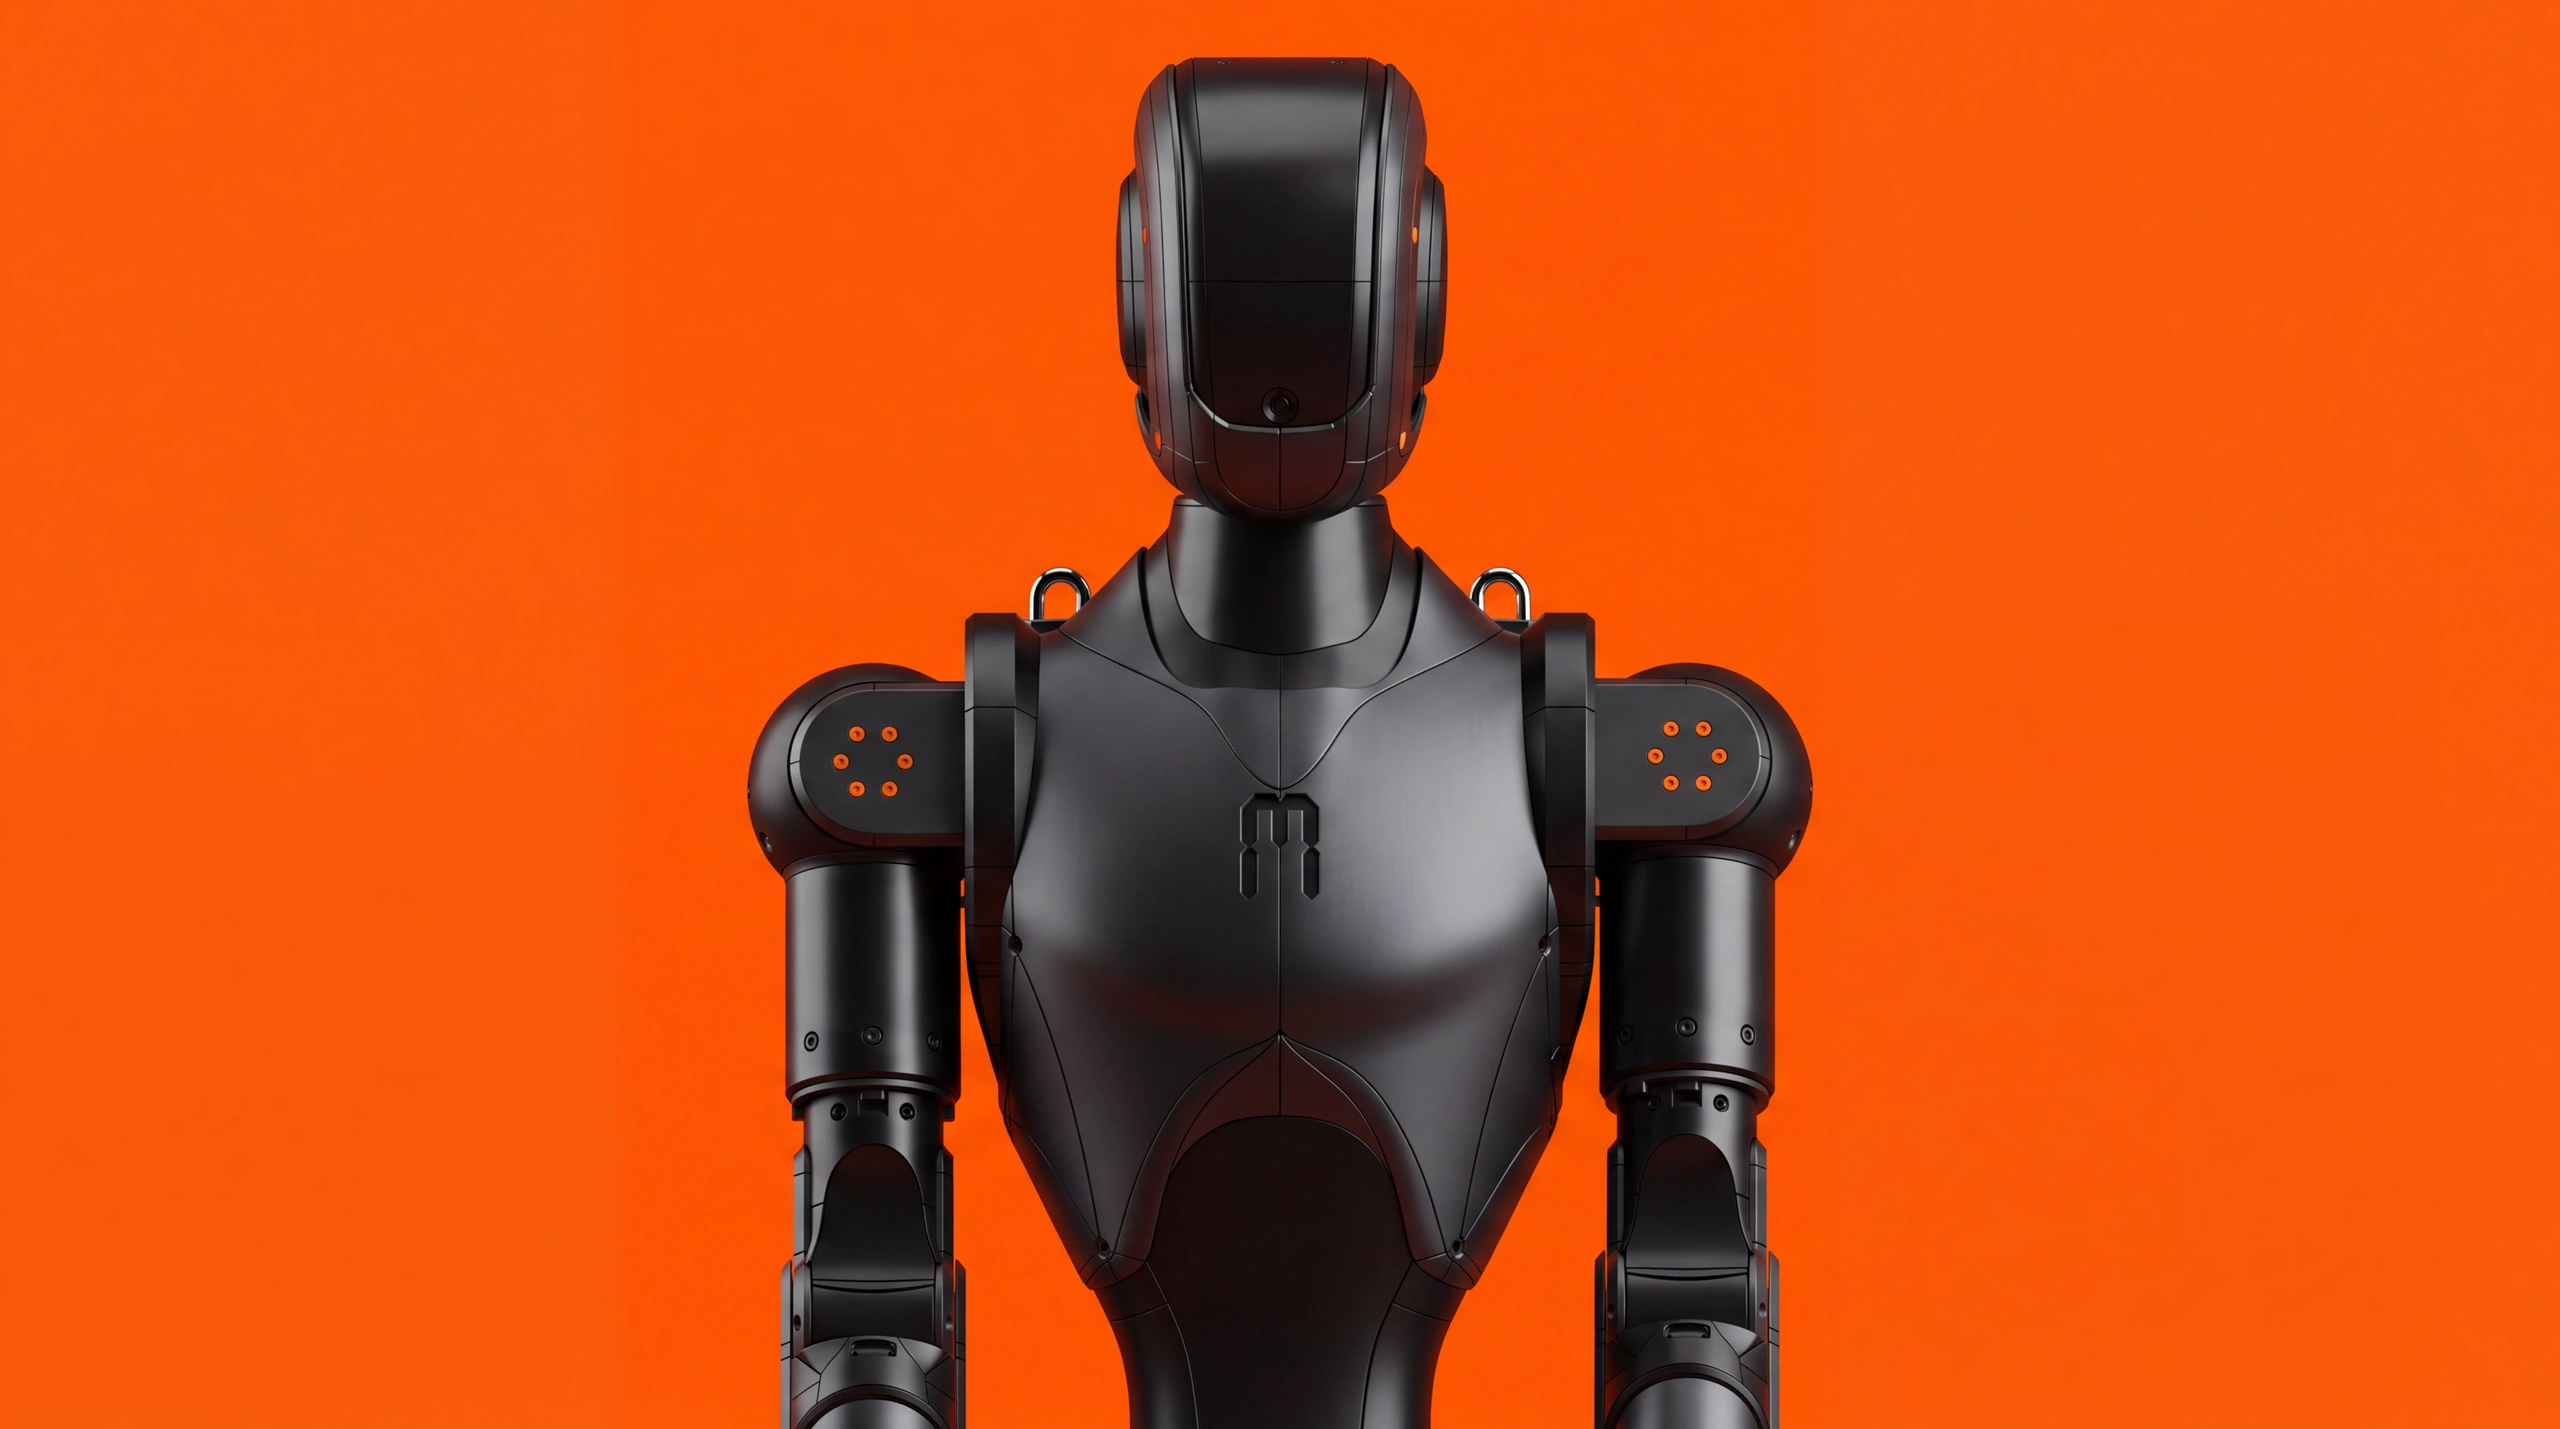
Menlo Research is a Singapore applied R&D lab building an open platform for robot development. Its flagship Asimov programme provides repairable humanoid reference hardware, simulation models, control interfaces and published design material so researchers and developers can train policies, inspect the stack and modify the machine rather than rely on a closed appliance.
Asimov 1 is the current 1.2-metre, 35-kilogram full-body platform. Menlo accepts orders, supports worldwide shipping and works with manufacturing and service partners rather than vertically integrating every unit. The company also develops Asimov OS and a broader software platform intended to connect skills, telemetry and applications across physical and simulated robots.
Articles


Products
Operations
Output & shipments
- Shipments
2026-09-12 - Menlo Research accepts orders for Asimov 1, states that it ships worldwide and says units are already working in laboratories and workshops. - Asimov v1 DIY Kit
Source
Supply
Supply chain relationships
- ENCOS
Inbound - Actuator - Menlo's initial Asimov leg build uses ENCOS actuators
Source - Raspberry Pi
Inbound - Compute & Control - Raspberry Pi 5 handles media and networking in Menlo Research's Asimov 1 humanoid
Source - Radxa
Inbound - Compute & Control - Radxa CM5 runs motion control in Menlo Research's Asimov 1 humanoid
Source - ENCOS
Inbound - actuation and motion control - ENCOS EC-A series actuators are specified for Menlo Research's Asimov 0 biped legs
Source
Research
- Menlo open-sources Asimov v1 designs and simulation model
2026-04-27 - Research Publication - The release-era platform measured 1.2 metres and 35 kilograms, with 25 actuated joints and two passive toe joints. Builders could use the bill of materials to source parts, including machined 7075 aluminium and MJF-printed PA12 nylon components. Mechanical files and simulation models were available, while electrical schematics, PCB files and a mobile app remained in development.
Source
Timeline
Events
- 2026-08-27 - Capability - Menlo demonstrates zero-shot sim-to-real locomotion on Asimov 1
Base policies ran onboard at 50 Hz, controlling 25 motors and sensors without external compute in the loop. Testing covered multiple units walking on flat ground, slight slopes and grass, with recovery from mild disturbances. Hardware changes included thermal fixes and a move to full SPI-CAN with an MCP2518FD controller to improve actuator communication.
Source - 2026-04-27 - Research Publication - Menlo open-sources Asimov v1 designs and simulation model
The release-era platform measured 1.2 metres and 35 kilograms, with 25 actuated joints and two passive toe joints. Builders could use the bill of materials to source parts, including machined 7075 aluminium and MJF-printed PA12 nylon components. Mechanical files and simulation models were available, while electrical schematics, PCB files and a mobile app remained in development.
Source
Context
Comparable profiles
- VinMotion
comparable profile - Physical AI Humanoid Builder
- Kunlunxing Robotics / 昆仑行机器人
comparable profile - Physical AI Humanoid Builder
- Noetix Robotics (松延动力)
comparable profile - Education Humanoid Robot Builder
- isento GmbH
comparable profile - Education Humanoid Robot Builder
Context tags
- Education humanoid robot builder - Peer Group - https://menlo.ai/ — reviewed source supports this bounded company context.
- Whole-body humanoid control - Capability - https://menlo.ai/handbook/solution — reviewed source supports this bounded company context.
- Physical AI humanoid builder - Peer Group - https://menlo.ai/ — reviewed source supports this bounded company context.