
G2 Max
About
About G2 Max
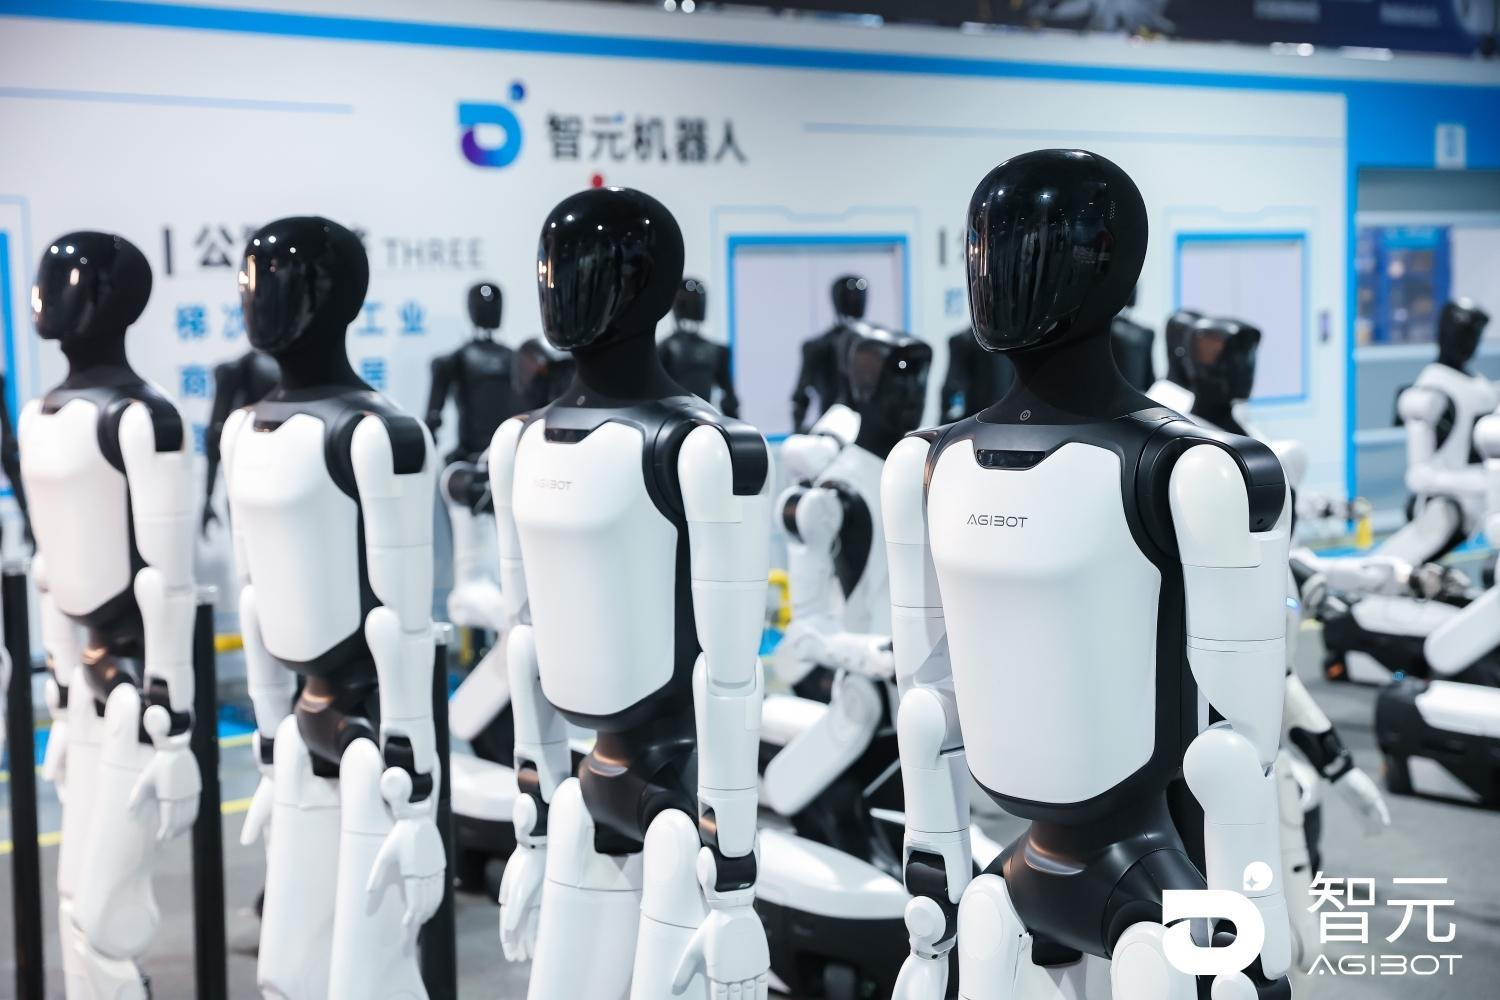
AGIBOT G2 Max is a heavy-load dual-arm robot developed by AgiBot with JD Logistics for warehouse handling. Its humanlike arms and force-control system are intended to grasp and move standard containers, with inbound unloading and palletising as the main announced workflows. The platform is designed to connect manual container-handling steps with surrounding warehouse automation.
JD Logistics and AgiBot introduced G2 Max in July 2026 and announced plans to use it in Zhilang warehouses. The proposed integration places it at the inbound side of a high-density goods-to-person system, linking container handling with automated storage and transport. Its planned role is to reduce repetitive bending, lifting and stacking by warehouse employees. The application combines robot force control with JD's warehouse equipment and workflow coordination.


Capabilities
Source-backed capabilities
- Operating environments: Intended JDLogistics Zhilang inbound warehouse, Intended warehouse inbound palletizing
- Material handling
Claimed - Grasp and transfer standard warehouse totes at inbound stations. - environment: Intended JDLogistics Zhilang inbound warehouse
Source - Palletizing
Claimed - Stack and unstack inbound warehouse totes alongside existing automation. - environment: Intended warehouse inbound palletizing
Source
Timeline
- AgiBot and JD Logistics introduce G2 Max for warehouse handling
2026-07-17 - Product Launch - G2 Max targets tote handling, palletizing and depalletizing at the inbound stage, connecting manual unloading with existing warehouse automation. The joint July 17 announcement described planned warehouse adoption; JD Logistics’ existing robotic storage and retrieval network was already operating in China and overseas.
Source
Context
Comparable Systems
- GINO 1
Geek+ - Mobile Manipulator
- AGIBOT G1 MAX
AgiBot - Semi Humanoid
- KUAVO 5W
Leju Robotics - Semi Humanoid
- MagicBot D1
MagicLab - Semi Humanoid
- REX G1
RoboScience / 机器科学 - Semi Humanoid
- Sonny
Tutor Intelligence - Semi Humanoid