
QDH
About
About QDH
QDH is Apptronik's Quick Development Humanoid, a historical research robot used to develop the hardware and controls that preceded Apollo. The bipedal prototype added legs and upper-body movement for balance to the company's earlier manipulation work, with simple arms for basic object handling. It served as an internal testbed for coordinating locomotion and manipulation in a complete humanoid body.
Apptronik designed and built QDH's structure, actuators, electronics and software. The robot used three actuator types, and the development programme explored how simpler components and a lower part count could support a practical humanoid. Lessons from QDH informed Apollo's subsequent design. QDH represents an experimental predecessor in that development sequence, while Apollo became the company's later platform for commercial applications.
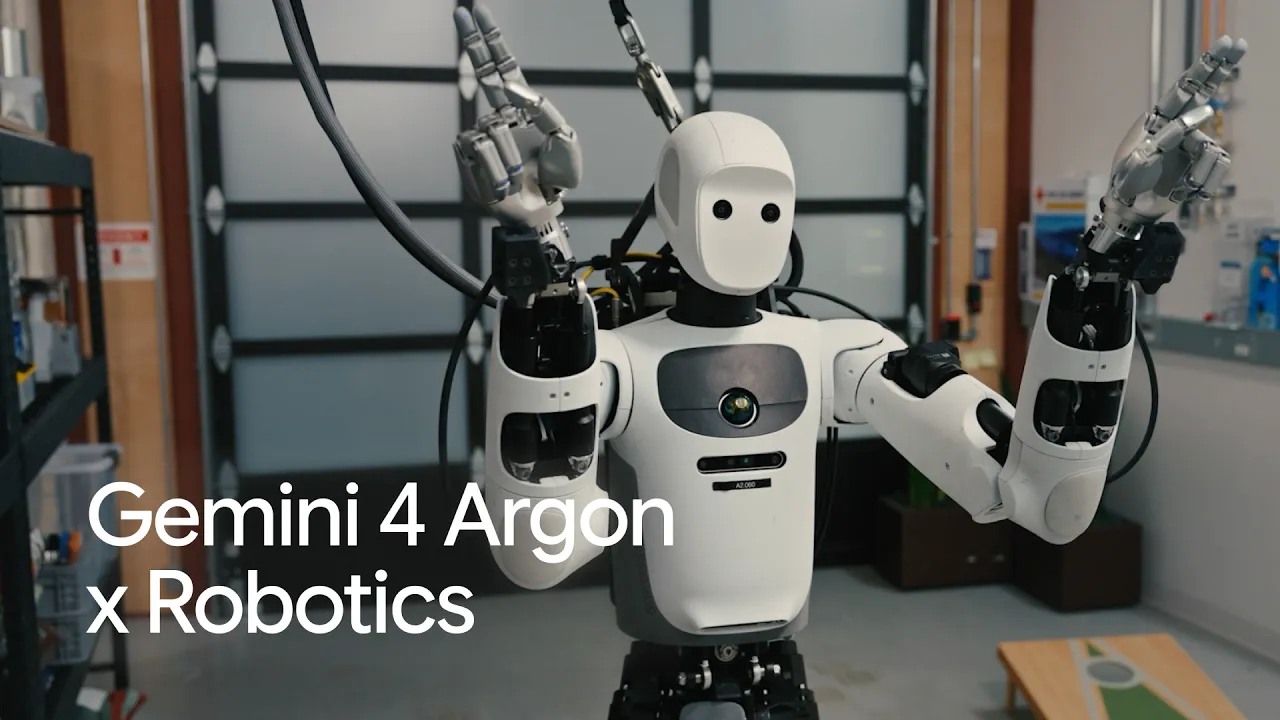
Google DeepMind demonstrates Gemini 4 Argon on Apptronik Apollo through video-to-simulation robotics pipeline

Gemini Robotics 2 Brings Whole-Body Control to Apollo 2
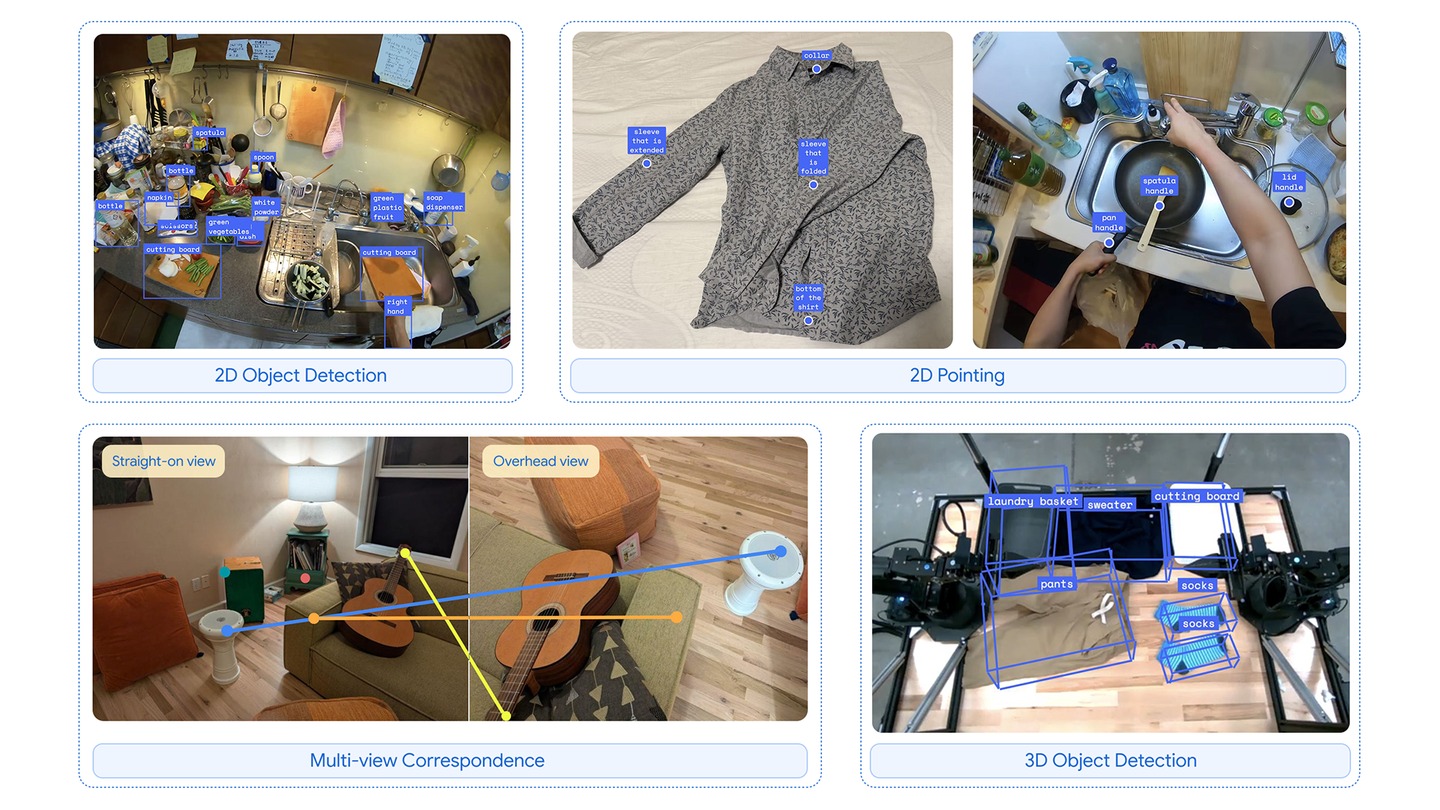
Google DeepMind introduces Gemini Robotics and embodied-reasoning models
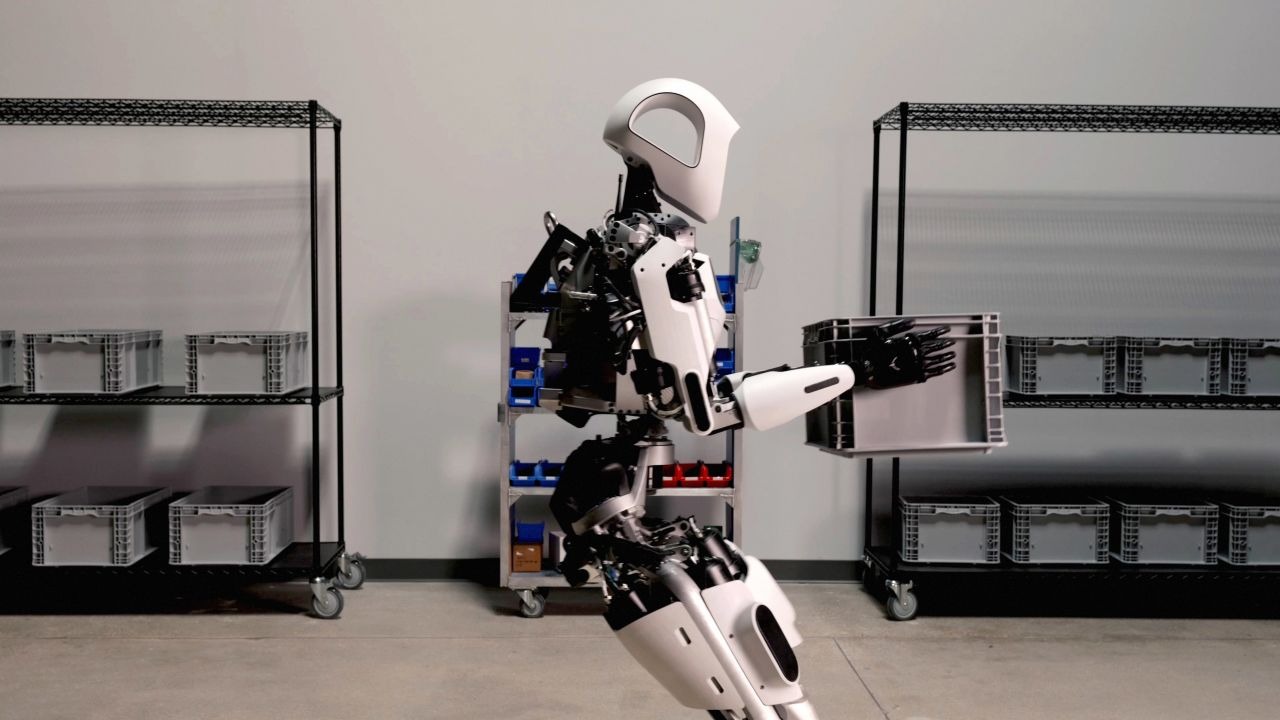
Apptronik unveils Apollo humanoid for manufacturing and logistics
Context
Comparable Systems
- ALICE 5
AeiROBOT - humanoid robotics
- AGIBOT A1
AgiBot - humanoid robotics
- Asimov 1
Menlo Research - Humanoid Robot
- Hydraulic Atlas
Boston Dynamics - humanoid robotics
- Elf 3
BXI Robotics - humanoid robotics
- TORO
DLR Institute of Robotics and Mechatronics - Anthropomorphic Biped
Related Systems
- Agile ONE
Agile Robots - humanoid robotics