
LYNX M20
About
About LYNX M20
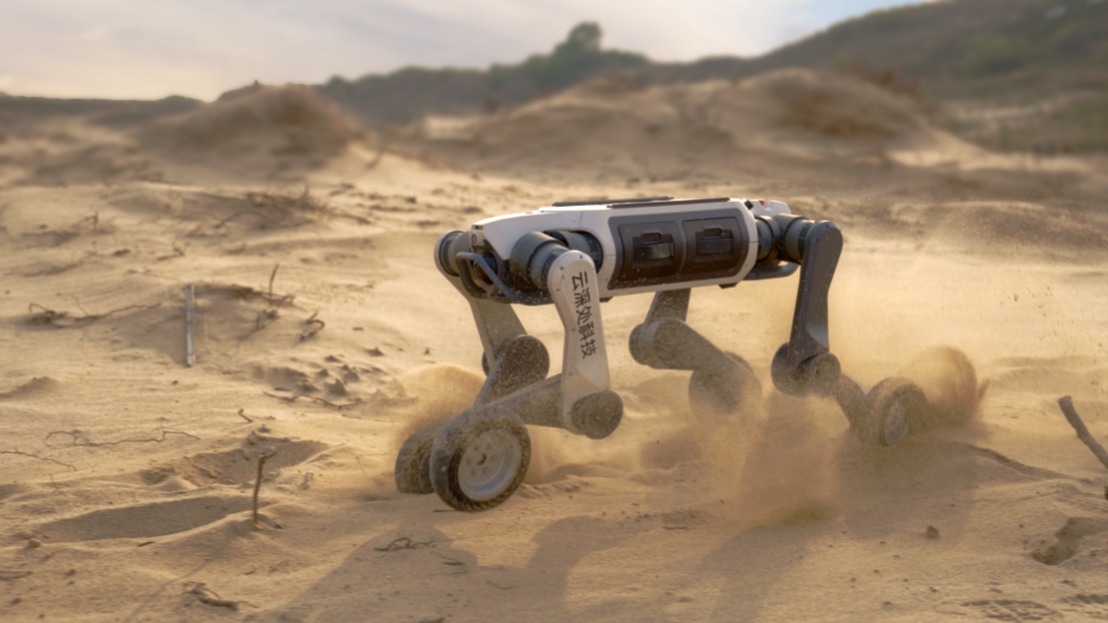
LYNX M20 is Deep Robotics’ wheel-legged mobile robot for inspection and response across mixed terrain. Driven wheels provide efficient travel on suitable surfaces, while articulated legs help the platform negotiate steps, obstacles and uneven ground.
The robot is offered with sensing and payload options for industrial and public-safety workflows. Traversable stairs, slopes and obstacles vary with load and conditions, while mission capability depends on the installed sensor, communications and autonomy package. M20, M20S and the smaller S10 retain separate variant specifications.


Capabilities
Source-backed capabilities
- Operating environments: Mountain trails, wetlands, ruins, pipelines and tunnels
- Control modes: Operator Supervised Autonomy
- Navigation and obstacle avoidance
Customer-site use - 2026-02-27 - The robots autonomously navigated rugged terrain to carry produce from the fields.
Source - Multi-terrain locomotion
Claimed - Traverse 45-degree slopes, wetlands and debris-filled ruins. - environment: Mountain trails, wetlands, ruins, pipelines and tunnels
Source - Stair climbing
Claimed - Climb 25 cm stairs and cross single steps up to 80 cm. - environment: Mountain trails, wetlands, ruins, pipelines and tunnels
Source - Crop harvesting
Customer-site use - 2026-02-27 - Deep Robotics' Lynx M20 Robots Transport Harvested Crops
Source
Operations
- Operating Milestone
26 km utility tunnel - 2026-06-23 - Chengdu Future Science and Technology City - LYNX M20 operated in a 26-kilometre urban utility tunnel in Chengdu.
Source
Research
- LynxScenes: A Large-Scale Real-World Benchmark for Outdoor Wheel-Legged Robot Perception, Navigation, Imagination and Reconstruction
2026-10-13 - Research Publication - Deep Robotics and academic collaborators introduce an outdoor wheel-legged robot corpus collected with LYNX M20. It contains about 100,000 navigation clips,833.6 hours and 3,294.7 km of recorded movement, supporting perception, trajectory prediction, future-scene prediction and reconstruction.
Source
Timeline
- Deep Robotics introduces LynxScenes outdoor wheel-legged robot dataset
2026-10-13 - Research Publication - The corpus contains about 100,000 clips, 833.6 hours and 3,294.7 km of recorded movement. Synchronized recordings combine four fisheye cameras, dual lidars, IMU, odometry and robot states. Benchmark tasks cover trajectory prediction, bird’s-eye-view perception, future-scene prediction and multi-view reconstruction.
Source - DEEP Robotics and Zhejiang emergency agency test LYNX M20 flood-response system
2026-04-16 - Demonstration - The 16 April drill took place in Shuichewu, Jingshan Town, and tested traversal, perception, warning and rescue functions. The system combined a dual-spectrum payload, 5G communications and edge computing on the wheeled-legged platform. Onboard detection classified simulated hazards and relayed location-tagged alerts to the command platform.
Source - Deep Robotics' Lynx M20 Robots Transport Harvested Crops
2026-02-27 - Deployment - Deep Robotics deployed Lynx M20 robots to transport freshly harvested greens from mountainous farmland. The robots autonomously navigated rugged terrain to carry produce from the fields. This deployment addressed the rural 'last mile' logistics challenge in agriculture.
Source - Lynx M20 Pro wins CES 2026 Innovation Award
2026-01-07 - Award - DEEP Robotics' Lynx M20 Pro, a medium-sized wheeled-legged quadruped robot, received the CES 2026 Innovation Award in the Robotics category. The robot features self-developed joints, IP66 protection, and capabilities such as speeds up to 5 m/s, stair climbing up to 25 cm, and carrying loads of 15 kg for 2.5 hours over 12 km. It has been deployed in environments like the uninhabited Hoh Xil region, transporting oxygen tanks and supplies in harsh plateau conditions.
Source
Context
Market context
LYNX M20 is Deep Robotics' payload-forward legged robot for field operations, inspection and rugged mobility.
- Target environment: Industrial sites, outdoor terrain, inspection routes, patrol areas and field environments needing legged mobility.
- Workflow context: Autonomous navigation, payload carriage, inspection, patrol, field sensing and modular mission expansion.
- Customer context: Industrial operators, security teams, inspection providers and public-sector users evaluating rugged legged robots.
- Deployment model: Commercial quadruped platform in Deep Robotics' Lynx family.
- Commercial maturity: Commercial product with public product page and field-robotics positioning.
- Adoption constraints: Adoption depends on payload needs, terrain, autonomy performance, battery life, fleet management and service support.
- Market position: Rugged quadruped lane between lighter developer robots and larger heavy-duty inspection platforms.
- Adjacent products: ANYmal, Unitree B2, Spot, Lynx S10
Comparable Systems
- LYNX M20S
Deep Robotics - Quadruped
- LYNX S10
Deep Robotics - Quadruped
- MagicDog-W
MagicLab - Quadruped
- X5 explosion-proof quadruped
QITEN Robotics - Quadruped Robot
- Hypertron-SW01
ASTRALL - Quadruped
- Unitree As2-W
Unitree - Quadruped
Related Systems
- Unitree As2
Unitree - Quadruped
- Trakr
Addverb - Quadruped
- Vbot Super Robot Dog
Vita Dynamics - Quadruped
- Vision 60
Ghost Robotics - Quadruped
- A2
Unitree - Quadruped
- B2
Unitree - Quadruped