
LimX Oli
About
About LimX Oli
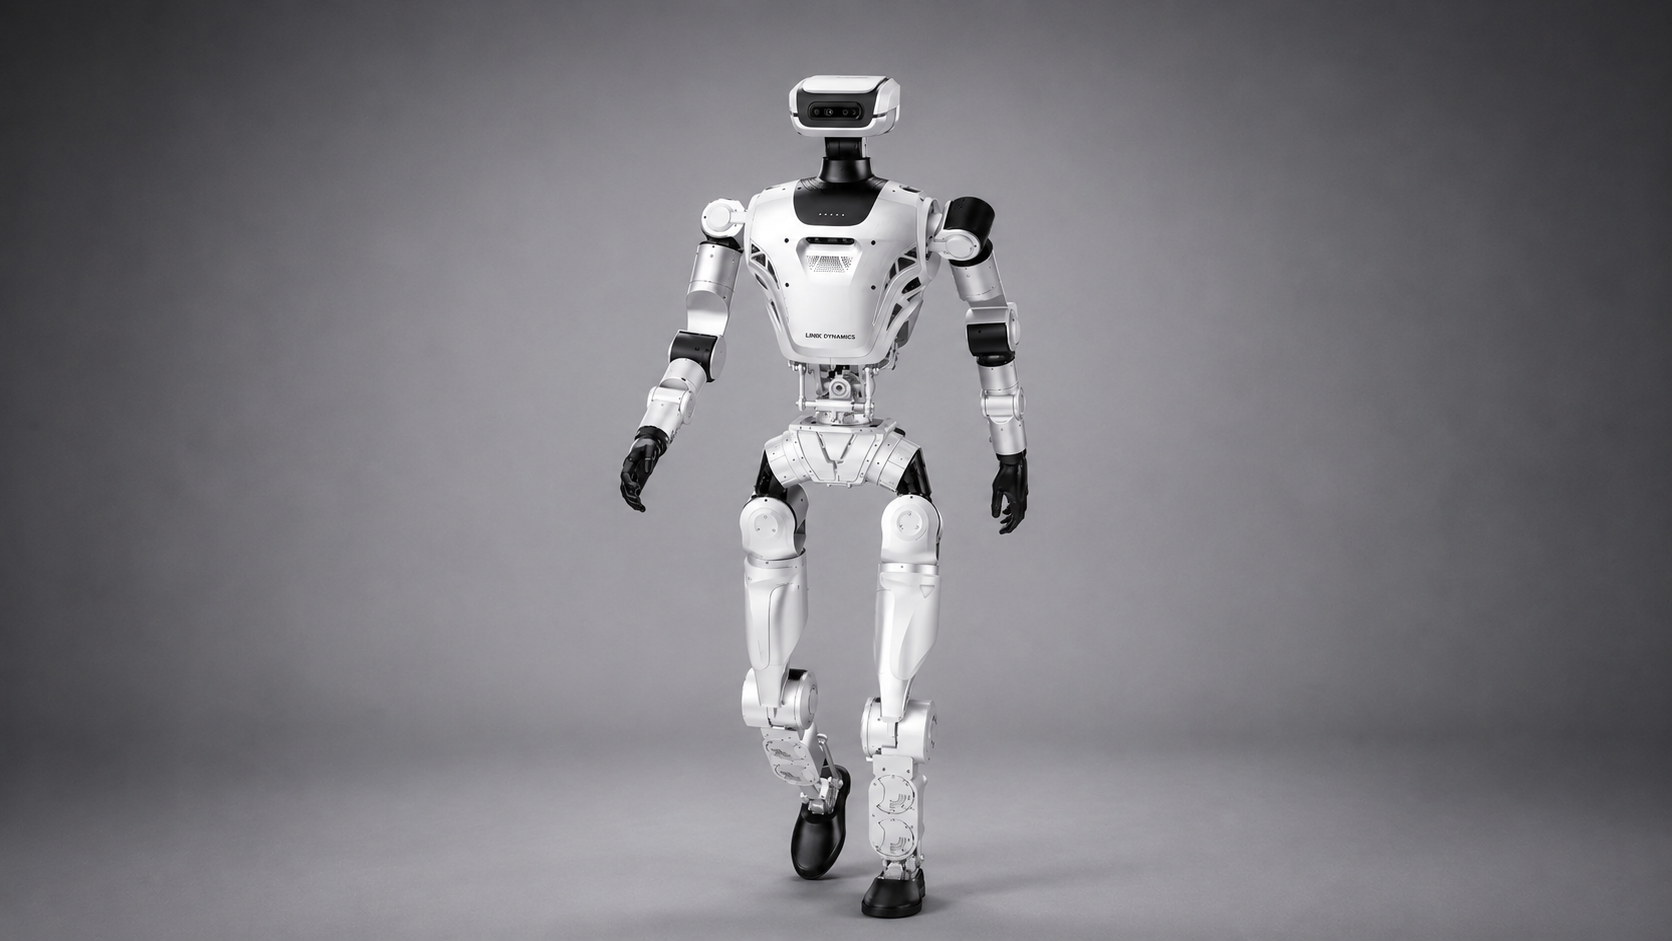
LimX Oli is a 165-centimetre humanoid with 31 degrees of freedom distributed across its head, waist, arms and legs. Depth cameras provide environmental perception, and interchangeable end effectors allow the platform to move between manipulation and research configurations. Whole-body control coordinates walking, balance and upper-body movement.
Oli operates with LimX Dynamics’ COSA agentic operating system, which connects perception, language reasoning, locomotion and manipulation. The robot is used for embodied-AI development, whole-body policy research and practical task demonstrations. LimX launched Oli commercially in China in 2025 and provides software, documentation, remote control and developer support.
Capabilities
Source-backed capabilities
- Operating environments: Taobao Influencer Night stage, Physical furnished-room and tabletop research setup
- Control modes: Autonomous, Human In The Loop
- Bipedal walking
Demonstrated - 2026-03-26 - Walk the Taobao Influencer Night runway alongside Luna. - environment: Taobao Influencer Night stage
Source - Clothing-to-hamper transfer
Research demonstration - 2026-07-15 - Remove a jacket from a clothes rack and put clothing into a hamper. - environment: Physical furnished-room and tabletop research setup
Source - Floor-level box stacking
Research demonstration - 2026-07-15 - Lift a box from the floor, align it and stack it on another box. - environment: Physical furnished-room and tabletop research setup
Source - Shelf-to-person wallet handover
Research demonstration - 2026-07-15 - Take a wallet from a shelf and hand it directly to a person. - environment: Physical furnished-room and tabletop research setup
Source - Tabletop basket cleanup
Research demonstration - 2026-07-15 - Pick tabletop objects and place them in a basket across rearranged object layouts. - environment: Physical furnished-room and tabletop research setup
Source - Small-candy pickup and retry
Research demonstration - 2026-07-15 - Pick small pieces of candy from a tray and retry after a missed grasp. - environment: Physical furnished-room and tabletop research setup
Source - Two-hand cup stacking
Research demonstration - 2026-07-15 - Pick up a cup in each hand and stack them onto a third cup. - environment: Physical furnished-room and tabletop research setup
Source - Hand-to-hand ball transfer
Research demonstration - 2026-07-15 - Pick up a ball, pass it to the other hand and drop it into a basket. - environment: Physical furnished-room and tabletop research setup
Source - Whole-body teleoperation and expert correction
Research demonstration - 2026-07-15 - Walk, bend to lift a storage box and correct failed grasps under whole-body human control. - environment: Physical furnished-room and tabletop research setup
Source - Continuous room tidying
Research demonstration - 2026-07-15 - Put toys away, straighten and push in a chair, and place table litter into a bin during a continuous room routine. - environment: Physical furnished-room and tabletop research setup
Source
Supply
Supply / Components
- LimX Oli
Realsense D435i Primary Depth Sensor - Perception - RealSense - RealSense D435i is LimX Oli's primary depth camera for humanoid navigation - source: realsenseai.com
Source - LimX Oli humanoid
Robot Control Soc - Compute & Control - Fuzhou Rockchip Electronics - LimX specifies RK3588 motion-control compute configurations in the Oli humanoid - source: limxdynamics.com
Source
Research
- FluxVLA Engine: A One-Stop VLA Engineering Platform for Embodied Intelligence
2026-09-15 - Research Publication - FluxVLA Engine connects embodied-policy data, distributed training, simulation evaluation, human correction and physical robot inference in an open engineering stack.
Source - Introducing COSA 0.5: A Whole-Body Capability Upgrade for the Humanoid VLA V³-0
2026-07-15 - Research Publication - LimX describes COSA 0.5 and its V³-0 stack for whole-body manipulation on the 43-DoF Oli humanoid. The report combines asynchronous vision-language-action inference, whole-body balance control and policy improvement from physical rollouts and human corrections.
Source - CWI: Composite Humanoid Whole-Body Imitation System for Loco-manipulation
2026-06-26 - Research Publication - A teleoperated LimX Oli performs a broad set of whole-body loco-manipulation demonstrations.
Source
Resources
Media library
- LimX Oli upper-body product view
image · LimX Dynamics
Source - LimX Oli end-effector options
image · LimX Dynamics
Source - LimX Oli slide-out battery module
image · LimX Dynamics
Source - LimX Oli unboxing and self-standing
video · LimX Dynamics
Source - Oli outdoors
image · LimX Dynamics
Source
Official product, brochure and developer-download references with exact LimX Oli architecture imagery and a verified manufacturer video.
- LimX Oli product brochure
PDF · LimX Oli, June 2026 · LimX Dynamics
Source - LimX Oli downloads centre
WEB · LimX Oli developer resources · LimX Dynamics
Source
Timeline
- LimX Dynamics demonstrates Luna at Taobao Influencer Night
2026-03-26 - Demonstration - The robots shared the runway and red-carpet presentation with actress Michelle Chen. Luna performed a catwalk and an illusion turn, demonstrating coordinated stage movement and balance.
Source - LimX Dynamics launches full-size Oli humanoid
2025-07-30 - Product Launch - The 165-centimetre robot has 31 active degrees of freedom excluding end-effectors and was offered in Lite, EDU and Super editions. Its modular interfaces support interchangeable end-effectors and peripherals, while the SDK exposes joint control, sensor data and task orchestration. A global version was planned, and its first public exhibition was scheduled for the August 8 World Robot Conference.
Source
Context
Market context
LimX Oli is LimX Dynamics' modular humanoid platform designed for flexible development and deployment across research and commercial use cases.
- Target environment: Research labs, development workshops and structured testing environments.
- Workflow context: Modular platform development, locomotion research and embodied AI experimentation with interchangeable hardware configurations.
- Customer context: Robotics researchers, embodied AI teams and developers working with modular humanoid hardware.
- Deployment model: Development platform positioned for research and flexible deployment.
- Commercial maturity: Active development platform with growing partnerships.
- Adoption constraints: Modular design enables flexibility but may trade off deployment readiness compared to fixed-configuration platforms.
- Market position: A modular humanoid platform enabling iterative hardware development. Distinct from fixed-configuration humanoids by its reconfigurable design.
- Adjacent products: H1, G1, TRON 2
Comparable Systems
- Lumos LUS 2
Lumos Robotics - humanoid robotics
- MagicBot Z1
MagicLab - Anthropomorphic Biped
- AI Sapiens K0
ROBOTIS - humanoid robotics
- Booster T1
Booster Robotics - humanoid robotics
- Booster T2
Booster Robotics - humanoid robotics
- G1
Unitree - humanoid robotics
Related Systems
- AKINCI 5
AKINROBOTICS - humanoid robotics
- AIDOL Walking Robot
AIDOL - humanoid robotics
- Walker C
UBTECH Robotics - Humanoid Platform