
Jetson Thor
About
About Jetson Thor
Jetson Thor is an embedded-compute family built around NVIDIA’s Blackwell GPU and Arm Neoverse CPU architecture. The T5000 module provides up to 2,070 FP4 teraflops and 128 gigabytes of memory within a configurable 40–130-watt power range, while the T4000 provides a lower-power 64-gigabyte configuration.
High-speed Ethernet, camera interfaces, programmable vision acceleration and Multi-Instance GPU support allow perception, generative models and lower-level robot workloads to run concurrently with isolated resources. The developer kit provides a carrier board and storage for prototyping, while production modules are integrated into customer machines. Jetson software connects Thor to Isaac, GR00T, Holoscan and wider CUDA-based robotics workflows.
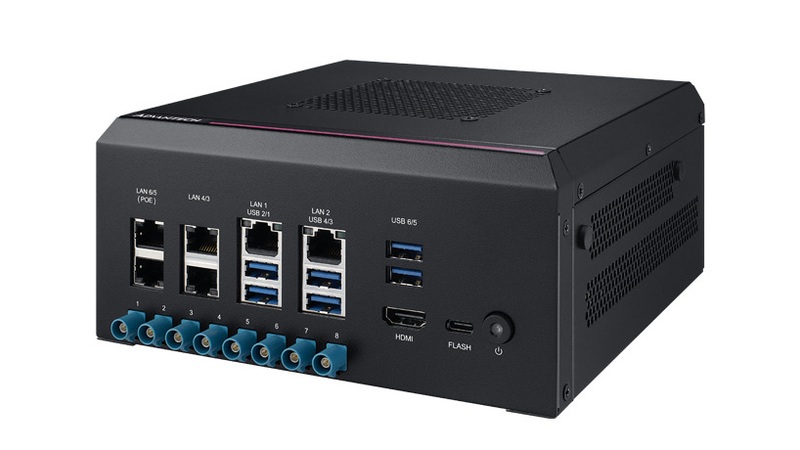
Advantech introduces UniCAM multi-camera integration on NVIDIA Jetson Thor
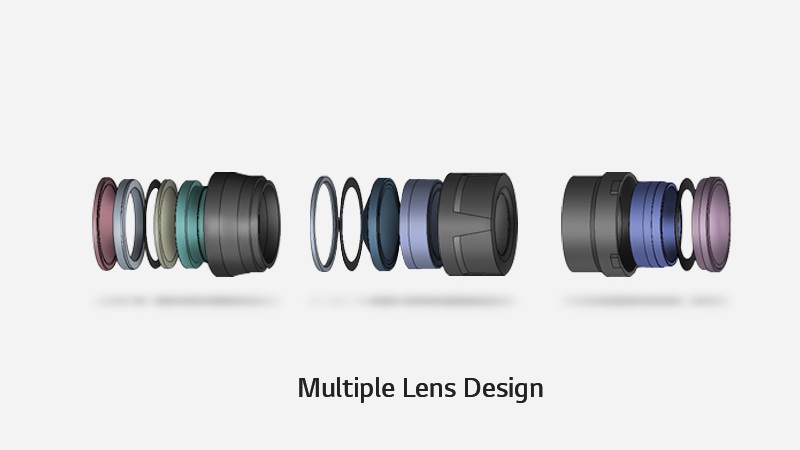
LG Innotek and NVIDIA develop robot vision sensing with Holoscan Sensor Bridge
Comau integrates NVIDIA Jetson and Isaac tools across industrial robotics portfolio
NVIDIA introduces Flora data engine for robotics video annotation
Observed use
Exact-product configurations are shown without inferring supply, purchase, customer status, standard fit, deployment or partnership.
- Observed configuration
Research Experiment - Tested With - Physical - HMR and HMR-Lite ran on NVIDIA Jetson Thor for embedded human-mesh benchmarks; HMR-Lite’s 5.5 ms RGB latency excludes person detection.
Source
Supply
Supply / Components
- Jetson Thor
robotics_compute
Research
- Seeing Machines HMR: Real-time 3D Human Mesh Recovery at up to 180 FPS on NVIDIA Jetson Thor
2026-09-30 - Research Publication - Embedded 3D human reconstruction from RGB or RGB-D inputs, evaluated on Jetson Thor.
Source - xperception -- Making Robotic Grasping Easier
2026-07-14 - Research Publication - However, conventional vision systems remain a bottleneck, requiring extensive data collection and model retraining whenever a new object is introduced to the production line.
Source - NVIDIA announces Isaac GR00T open reference humanoid for academic research
2026-06-01 - Research Publication - Announces an open humanoid reference design combining a Unitree H2 Plus body, Sharpa tactile hands, Jetson Thor onboard compute, and Isaac GR00T software workflows.
Source - FOUND-IT: Foundation-model-first Task-driven 3D Scene Graphs with Granularity on Demand
2026-05-25 - Research Publication - We present the first approach to build hierarchical task-driven 3D scene graphs of arbitrary indoor or outdoor environments using an uncalibrated monocular camera in real-time. We leverage geometric foundation models to estimate geometric attributes of the scene graph (e.
Source - 2.5-D Decomposition for LLM-Based Spatial Construction
2026-05-08 - Research Publication - Autonomous systems that build structures from natural-language instructions need reliable spatial reasoning, yet large language models (LLMs) make systematic coordinate errors when generating three-dimensional block placements. We present a neuro-symbolic pipeline based on \emph{2.
Source - Shallow-π: Knowledge Distillation for Flow-based VLAs
2026-01-28 - Research Publication - The growing demand for real-time robotic deployment necessitates fast and on-device inference for vision-language-action (VLA) models. Within the VLA literature, efficiency has been extensively studied at the token level, such as visual token pruning.
Source - VGGT-SLAM 2.0: Real-time Dense Feed-forward Scene Reconstruction
2026-01-27 - Research Publication - The authors present VGGT-SLAM 2.0, a real-time RGB feed-forward SLAM system which substantially improves upon VGGT-SLAM for incrementally aligning submaps created from VGGT.
Source
Resources
Media library
- Jetson AGX Thor Developer Kit
image · NVIDIA
Source - Physical AI development context
image · NVIDIA
Source - Developer kit detail
image · NVIDIA
Source - Getting started with Jetson AGX Thor
video · NVIDIA Developer
Source
Official technical documentation and product media for the NVIDIA Jetson AGX Thor developer kit and platform.
- Jetson AGX Thor Developer Kit user guide
WEB · Developer kit · NVIDIA
Source - Jetson Linux Developer Guide
WEB · Jetson Linux 39.2 · NVIDIA
Source - Jetson download center
WEB / PDF · Jetson platform · NVIDIA
Source
Timeline
- Agile Robots unveils Agile ONE SN humanoid reference platform
2026-10-21 - Product Launch - The 1.4 m platform has 31 body degrees of freedom plus 20 in each hand and supports up to 3 kg payload per arm. GR00T 1.7, whole-body control and URDF/USD assets connect demonstration capture, simulation, training and physical testing. Availability is scheduled for early 2027; NVIDIA Halos safety integration is being explored.
Source - NVIDIA introduces Cosmos 3 Edge and Jetson Thor T2000/T3000
2026-07-15 - Product Launch - Cosmos 3 Edge is a 4-billion-parameter open world foundation model for real-time vision reasoning and robot-action generation on edge systems. The T3000 combines 865 FP4 teraflops, 32GB LPDDR5X memory and 25GbE; the T2000 provides 400 FP4 teraflops and 16GB memory. NVIDIA said T3000 emulation would begin in July 2026, while commercial T2000 and T3000 module availability is scheduled for Q1 2027.
Source - NVIDIA and Doosan Group expand physical AI partnership across robotics and AI factory infrastructure
2026-06-07 - Partnership - NVIDIA and Doosan Group expanded their collaboration across physical AI, robotics and AI factory infrastructure. Doosan Robotics is integrating NVIDIA Isaac Sim, Isaac Lab, Cosmos, Newton and Jetson Thor into its Agentic Robot OS for perception, reasoning, simulation, learning and on-device inference. The robotics work includes industrial task use cases such as depalletizing and sanding, plus new robot form factors including dual-arm and humanoid platforms. The broader collaboration also covers Doosan Bobcat autonomous equipment, Doosan Enerbility power infrastructure for AI factories and Doosan electronics materials for next-generation data-center systems.
Source - NVIDIA unveils open humanoid robot for university research
2026-06-02 - Product Launch - The system combines a Unitree H2 Plus humanoid body, Sharpa five-fingered hands, Jetson Thor onboard computing, and NVIDIA's Isaac GR00T software stack. Onboard computing comes from the Jetson AGX Thor T5000, based on NVIDIA's Blackwell architecture.
Source - NVIDIA Releases Jetson T4000 Module and New Physical AI Models at CES
2026-01-05 - Product Launch - NVIDIA announced the Jetson T4000 module, powered by the Blackwell architecture, offering four times greater energy efficiency and AI compute. The company also introduced new open models and frameworks for physical AI, including NVIDIA Cosmos and GR00T, to advance robot learning and reasoning. Global partners such as Boston Dynamics, Caterpillar, and LG Electronics unveiled new robots built on NVIDIA technologies.
Source - NVIDIA's Jetson AGX Thor now available for robotics applications
2025-08-25 - Product Launch - NVIDIA announced the general availability of the Jetson AGX Thor developer kit and production modules, designed for physical AI and robotics. The Jetson AGX Thor, powered by NVIDIA's Blackwell GPU architecture, delivers up to 2,070 FP4 teraflops of AI compute within a 130-watt power envelope. Early adopters include Agility Robotics, Amazon Robotics, Boston Dynamics, Caterpillar, Figure, Hexagon, Medtronic, and Meta.
Source - NVIDIA introduces Jetson Thor robotics compute platform
2024-03-18 - Product Launch - NVIDIA unveiled Jetson Thor as a high-performance embedded compute platform designed specifically for humanoid robots and advanced autonomous machines. The platform combines GPU acceleration with AI model support for perception, planning, and control tasks. NVIDIA positioned Jetson Thor as a next-generation edge compute layer for physical AI systems.
Source
Context
Market context
Jetson Thor is NVIDIA's next-generation robotics compute platform, designed specifically for humanoid and advanced autonomous systems.
- Target environment: Humanoids, mobile robots, industrial robots and edge robotics systems.
- Workflow context: On-robot AI inference, perception, control, foundation-model execution and edge compute.
- Customer context: Robot builders and manufacturers needing embedded AI compute.
- Deployment model: Compute module and developer platform sold into robotics hardware programs.
- Commercial maturity: Commercial NVIDIA robotics compute platform.
- Adoption constraints: Adoption depends on power envelope, thermal design, software integration and robot production timelines.
- Market position: Robotics compute layer beneath humanoids, AMRs and industrial robots; not a finished robot platform.
- Adjacent products: Project GR00T, Isaac, edge AI compute modules
Comparable Systems
- IGX Thor Module and Boardkit
NVIDIA - Component
- Jetson AGX Orin 64GB
NVIDIA - Component
- Kria AI Series
Advanced Micro Devices - Component Family
- Open-Q 6490CS SOM
Lantronix - Component