
OmniHand Pro 2025
About
About OmniHand Pro 2025
OmniHand Pro 2025 is a compact anthropomorphic hand with 12 active and 19 total degrees of freedom. Its linkage-driven fingers provide a two-millimetre minimum grasp diameter, fingertip forces reaching 20 newtons and fine control for tool use, sorting and dexterous object handling.
The hand integrates fingertip three-axis force sensors, palm force sensing and more than 150 tactile points. CAN FD communications connect it with humanoids and robot arms, and AgiBot supplies firmware, host software, URDF models and an SDK. Commercial versions are available through AgiBot’s store.


Context
Market context
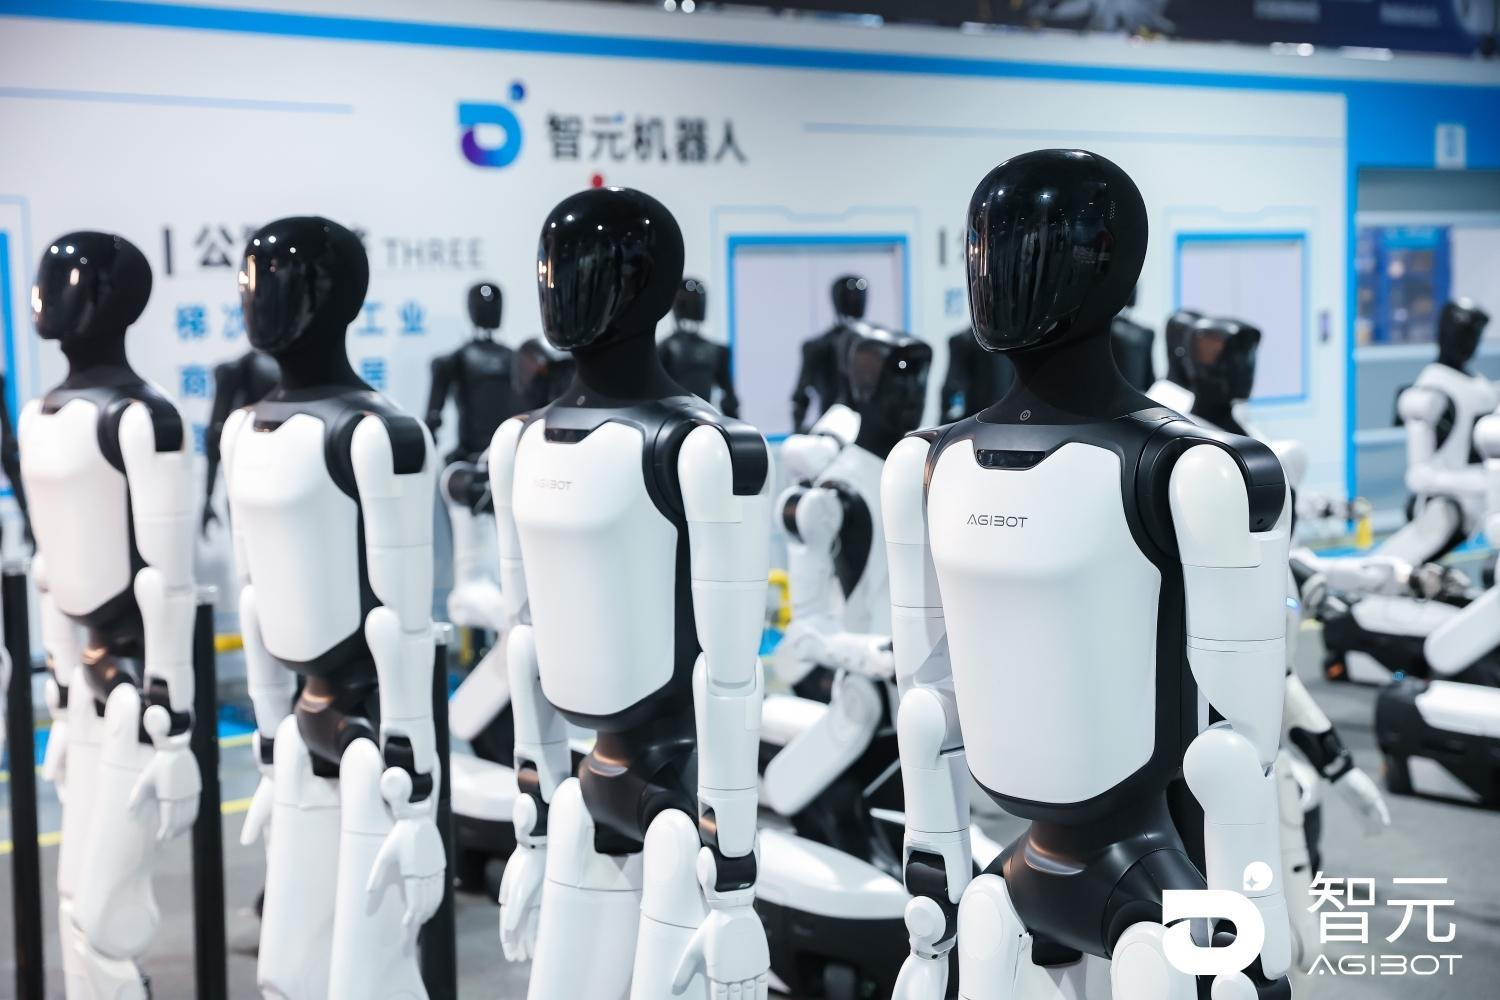
OmniHand Pro 2025 is AGIBOT higher-capability dexterous robotic hand with 12 active DOF and multimodal sensing for humanoid and advanced manipulation.
- Target environment: Research labs and advanced manipulation research facilities.
- Workflow context: Advanced dexterous grasping, precision manipulation and multimodal sensing for humanoid and robotic arm platforms.
- Customer context: Robotics researchers and advanced manipulation R and D teams.
- Deployment model: Commercial component-level dexterous hand for high-performance manipulation.
- Commercial maturity: Commercially available higher-capability dexterous hand with advanced sensing.
- Adoption constraints: End-effector level product requiring integration into a complete robotic system.
- Market position: AgiBot stronger hand offering for manipulation-heavy humanoid and component profiles.
- Adjacent products: OmniHand 2025, dexterous robotic hands
Comparable Systems
- OmniHand O10 2025
AgiBot - Hand
- ArtiXon Hand
X Square Robot - Hand
- Revo 3
BrainCo - Dexterous Hand
- Cool Hand
Ti5 Robot - Hand
- DEX-EE Hand
Shadow Robot - Hand
- Griply Hand Series
Griply AI - Dexterous Hand