
Digit
About
About Digit
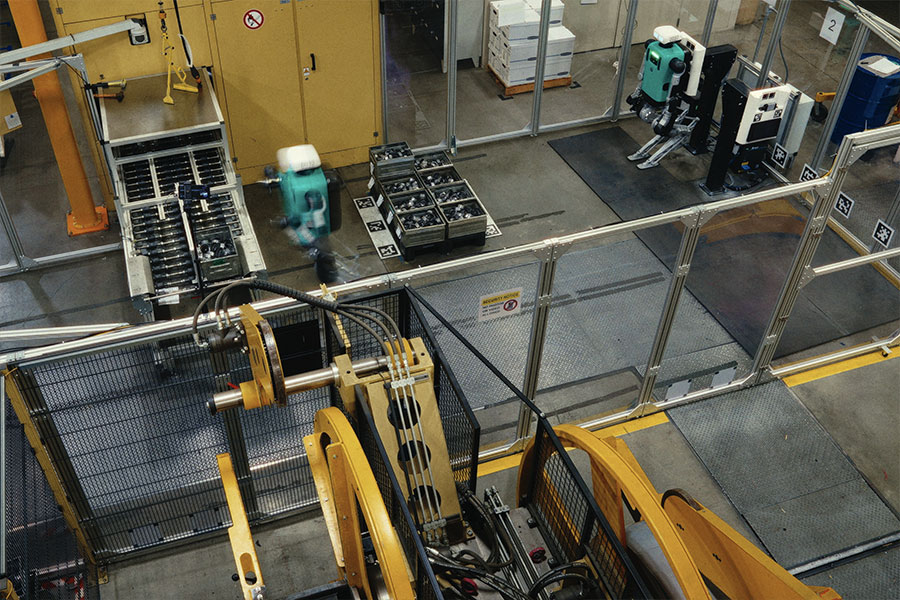
Digit is Agility Robotics' bipedal material-handling robot for repetitive work in logistics and manufacturing facilities. It combines walking and mobile manipulation with Agility Arc, the software used to configure workflows, coordinate robot fleets and manage operating status. The platform is designed to work with existing facility automation, including autonomous mobile robots and conveyors.
At GXO's SPANX operation, Digit moves totes from mobile robots onto conveyors under a commercial Robots-as-a-Service agreement. By September 2026, Agility attributed more than 65,000 operating hours to the Digit 4 generation across customer sites. These operating results belong to that deployed generation. Digit 5 is a separate successor with an updated safety architecture and planned 2027 availability.



Capabilities
Source-backed capabilities
- Operating environments: GXO SPANX fulfillment facility
- Tote handling
Commercial deployment - 2024-06-27 - Transfer totes from mobile robots onto conveyors at GXO’s SPANX warehouse. - environment: GXO SPANX fulfillment facility
Source - Material handling
Claimed - 2023-03-20 - Agility unveils next-generation Digit for warehouse material handling
Source
Operations
- Production Capacity
up to 10,000 robots/year design capacity - 2026-09-15 - RoboFab - humanoid robot manufacturing - Agility says RoboFab is designed to produce up to 10,000 Digit robots per year at full capacity. This is the facility's design capacity, not achieved annual output or current utilisation.
Source - Order / Commitment
1,000 Digit v5 robots under multi-year RaaS orders - 2026-06-24 - Agility disclosed multi-year Digit v5 RaaS orders relating to 1,000 robots, subject to contractual milestones.
Source - Order / Commitment
more than $300 million potential multi-year order value - 2026-06-24 - Agility disclosed more than $300 million of potential multi-year Digit v5 order value, subject to contractual milestones.
Source - Order / Commitment
9 committed customer-facility deployments - 2026-06-24 - Agility disclosed nine committed customer-facility deployments for Digit as of May 2026.
Source - Operating Milestone
more than 100,000 totes moved - 2025-11-20 - GXO Logistics - warehouse logistics - Agility says Digit moved more than 100,000 totes at GXO's Flowery Branch facility. The metric measures tote movements handled in commercial operation, not robots deployed.
Source
Deployments
- Commercial Activity
at least 4 named commercial customer deployments - 2026-06-24 - At least four named customers have current commercial Digit deployment evidence: GXO, Schaeffler, Toyota Motor Manufacturing Canada and Mercado Libre.
Source - Operating Use
65,000 operating hours - 2026-06-24 - Agility reported 65,000 cumulative hours of Digit operations as of May 2026.
Source - Customer Site
1 disclosed pilot site - 2026-02-19 - Toyota Motor Manufacturing Canada - automotive manufacturing logistics - Toyota Motor Manufacturing Canada signed a Robots-as-a-Service agreement after a successful Digit pilot, with plans to expand use in manufacturing and logistics.
Source - Commercial Activity
1 named commercial site - 2024-10-03 - GXO Logistics - warehouse logistics - Digit entered commercial operations at a GXO facility near Atlanta under a multi-year Robots-as-a-Service agreement. The active robot count was not disclosed.
Source
Supply
Supply / Components
- Digit
Realsense D455 Depth Camera - Perception - RealSense - Agility Robotics’ Digit incorporates a RealSense D455 depth camera in its neck - source: realsenseai.com
Source - Digit
Mesh Rider Radios For Digit - Communications - Doodle Labs - Doodle Labs RM-1700-21N3 and RM-1700-22O3 Mesh Rider radios are installed in Agility Robotics Digit - source: doodlelabs.com
Source
Research
- Proprioceptive Invariant State Estimation for Humanoid Robots on Non-Inertial Ground
2026-06-17 - Research Publication - Digit maintains state estimates while standing, squatting and walking on non-inertial ground.
Source - Efficient and Compliant Control Framework for Versatile Human-Humanoid Collaborative Transportation
2025-12-08 - Research Publication - We present a control framework that enables humanoid robots to perform collaborative transportation tasks with a human partner. The framework supports both translational and rotational motions, which are fundamental to co-transport scenarios. It comprises three components: a high-level planner, a low-level controller, and a stiffness modulation mechanism. At the planning level, we introduce the Interaction Linear Inverted Pendulum (I-LIP), which, combined with an admittance model and an MPC formulation, generates dynamically feasible footstep plans. These are executed by a QP-based whole-body controller that accounts for the coupled humanoid-object dynamics. Stiffness modulation regulates robot-object interaction, ensuring convergence to the desired relative configuration defined by the distance between the object and the robot's center of mass. We validate the effectiveness of the frame
Source - Isaac Lab: A GPU-Accelerated Simulation Framework for Multi-Modal Robot Learning
2025-11-06 - Research Publication - Isaac Lab models Digit locomotion with a ray-cast height scanner and closed-loop kinematic chains for simulated perceptive-learning benchmarks.
Source - Agility Robotics trains a whole-body control foundation model for Digit
2025-08-28 - Research Publication - Agility Robotics describes a whole-body-control foundation model for Digit. The research uses Digit as the humanoid deployment platform for coordinated mobility, manipulation, and task behavior.
Source - Dynamic subgoal pursuit paper validates humanoid navigation using Digit simulation
2025-06-02 - Research Publication - Safe and real-time navigation is fundamental for humanoid robot applications. However, existing bipedal robot navigation frameworks often struggle to balance computational efficiency with the precision required for stable locomotion.
Source - Opt2Skill: Imitating Dynamically-feasible Whole-Body Trajectories for Versatile Humanoid Loco-Manipulation
2024-09-30 - Research Publication - Humanoid robots are designed to perform diverse loco-manipulation tasks. However, they face challenges due to their high-dimensional and unstable dynamics, as well as the complex contact-rich nature of the tasks. Model-based optimal control methods offer flexibility to define precise motion but are limited by high computational complexity and accurate contact sensing. On the other hand, reinforcement learning (RL) handles high-dimensional spaces with strong robustness but suffers from inefficient learning, unnatural motion, and sim-to-real gaps. To address these challenges, we introduce Opt2Skill, an end-to-end pipeline that combines model-based trajectory optimization with RL to achieve robust whole-body loco-manipulation. Opt2Skill generates dynamic feasible and contact-consistent reference motions for the Digit humanoid robot using differential dynamic programming (DDP) and trains RL
Source - Time-Varying Foot-Placement Control for Underactuated Humanoid Walking on Swaying Rigid Surfaces
2024-09-12 - Research Publication - Locomotion on dynamic rigid surface (i.e., rigid surface accelerating in an inertial frame) presents complex challenges for controller design, which are essential for deploying humanoid robots in dynamic real-world environments such as moving trains, ships, and airplanes. This paper introduces a real-time, provably stabilizing control approach for underactuated humanoid walking on periodically swaying rigid surface. The first key contribution is the analytical extension of the classical angular momentum-based linear inverted pendulum model from static to swaying grounds. This extension results in a time-varying, nonhomogeneous robot model, which is fundamentally different from the existing pendulum models. We synthesize a discrete footstep control law for the model and derive a new set of sufficient stability conditions that verify the controller's stabilizing effect. Another key contrib
Source - Revisiting Reward Design and Evaluation for Robust Humanoid Standing and Walking
2024-04-30 - Research Publication - A necessary capability for humanoid robots is the ability to stand and walk while rejecting natural disturbances. Recent progress has been made using sim-to-real reinforcement learning (RL) to train such locomotion controllers, with approaches differing mainly in their reward functions. However, prior works lack a clear method to systematically test new reward functions and compare controller performance through repeatable experiments. This limits our understanding of the trade-offs between approaches and hinders progress. To address this, we propose a low-cost, quantitative benchmarking method to evaluate and compare the real-world performance of standing and walking (SaW) controllers on metrics like command following, disturbance recovery, and energy efficiency. We also revisit reward function design and construct a minimally constraining reward function to train SaW controllers. We ex
Source - Digit social-navigation paper combines MPC with zonotope neural networks
2024-03-25 - Research Publication - This paper covers Digit social-navigation paper combines MPC with zonotope neural networks for Digit in Navigation.
Source - Words into Action: Learning Diverse Humanoid Robot Behaviors using Language Guided Iterative Motion Refinement
2023-10-10 - Research Publication - Humanoid robots are well suited for human habitats due to their morphological similarity, but developing controllers for them is a challenging task that involves multiple sub-problems, such as control, planning and perception. In this paper, we introduce a method to simplify controller design by enabling users to train and fine-tune robot control policies using natural language commands. We first learn a neural network policy that generates behaviors given a natural language command, such as "walk forward", by combining Large Language Models (LLMs), motion retargeting, and motion imitation. Based on the synthesized motion, we iteratively fine-tune by updating the text prompt and querying LLMs to find the best checkpoint associated with the closest motion in history. We validate our approach using a simulated Digit humanoid robot and demonstrate learning of diverse motions, such as walkin
Source - Invariant Filtering for Legged Humanoid Locomotion on Dynamic Rigid Surfaces
2022-01-25 - Research Publication - State estimation for legged locomotion over a dynamic rigid surface (DRS), which is a rigid surface moving in the world frame (e.g., ships, aircraft, and trains), remains an under-explored problem. This paper introduces an invariant extended Kalman filter that estimates the robot's pose and velocity during DRS locomotion by using common sensors of legged robots (e.g., inertial measurement units (IMU), joint encoders, and RDB-D camera). A key feature of the filter lies in that it explicitly addresses the nonstationary surface-foot contact point and the hybrid robot behaviors. Another key feature is that, in the absence of IMU biases, the filter satisfies the attractive group affine and invariant observation conditions, and is thus provably convergent for the deterministic continuous phases. The observability analysis is performed to reveal the effects of DRS movement on the state observab
Source
Resources
Media library
- Digit in a workcell
image · Agility Robotics
Source - Industrial deployment view
image · Agility Robotics
Source - Sensor-head detail
image · Agility Robotics
Source - Digit's first day at GXO
video · Agility Robotics
Source - Flow-rack handling demonstration
video · Agility Robotics
Source
Timeline
- Agility Robotics plans 50,000-square-foot Pittsburgh software and deployment hub
2026-10-21 - Facility Opening - The facility adds approximately 35,000 square feet to the company’s existing Pittsburgh footprint. First employee access is expected by the end of 2026; the site will include workflow validation and an East Coast service centre. The four-customer announcement includes the previously disclosed AGCO pilot.
Source - Agility and AGCO sign agreement for 2027 Digit pilot
2026-10-20 - Commercial Order - Initial tasks include sorting and stacking parts and placing totes into storage. The trial targets repetitive and physically demanding assembly and production work. Robot quantity and contract value were not disclosed.
Source - Agility Robotics signs commercial deployment agreement with Toyota Motor Manufacturing Canada for Digit
2026-02-19 - Partnership - The pilot examined manufacturing workflows with repetitive, physically demanding tasks. The agreement will bring Digit into automotive manufacturing operations through Agility’s deployment and service model.
Source - Agility Robotics signs Mercado Libre agreement for Digit fulfillment work
2025-12-10 - Partnership - The companies will explore additional logistics applications across Mercado Libre warehouses in Latin America. Initial work targets repetitive, physically demanding fulfillment tasks that are difficult to staff, with Agility Arc coordinating robots and existing enterprise systems.
Source - Agility Digit passes site-specific NRTL safety field evaluation
2025-11-24 - Regulatory - The on-site review assessed mechanical, electrical-shock and interaction hazards in an operating customer environment. Agility said the compliance work supported expansion from automated putwalls to tote recycling; the field evaluation applies to the assessed site.
Source - Agility Robotics expands Digit autonomy, safety and AMR integration
2025-03-31 - Capability - Updates include up to four hours of battery operation, autonomous docking, revised end effectors and additional stop and safety-control functions. Agility Arc was shown coordinating workflows with MiR and Zebra AMRs, including tote handling, loading, unloading and palletizing applications.
Source - Agility Robotics expands NVIDIA collaboration for Digit training and simulation
2025-03-18 - Partnership - Isaac Lab and Isaac Sim reinforcement-learning work had improved step recovery after pushes and other disturbances. Agility received early access to Cosmos and Mega, and used Schaeffler digital assets with Omniverse to test customer deployment environments.
Source - Agility Robotics receives Schaeffler investment and signs robot purchase agreement
2024-11-13 - Partnership - Schaeffler described potential deployment across its network of 100 plants by 2030. Agility said the next phase of development would focus on robots working cooperatively with people beyond existing safety cages.
Source - Agility Robotics and Ricoh partner for humanoid support services
2024-09-09 - Partnership - Ricoh’s Service Advantage program provides lifecycle support for Digit robots and the Agility Arc fleet-management platform. Support spans facility mapping, workflow definition, operational management and troubleshooting as customer installations expand.
Source - Agility Digit enters GXO commercial operations under RaaS agreement
2024-06-05 - Deployment - At the SPANX facility, Digit moves totes from mobile robots onto conveyors, with Agility Arc coordinating the workflow. The commercial operation followed a proof-of-concept pilot in late 2023; the partners planned to explore more use cases and scale usage.
Source - Agility Digit wins inaugural RBR50 Robot of the Year award
2024-04-09 - Award - At ProMAT 2023, Digit moved totes from shelving to a conveyor in a demonstration based on a customer use case. The award coverage highlighted subsequent tests with Amazon near Seattle and GXO at a SPANX facility in Georgia.
Source - Agility Robotics partners with Manhattan Associates on warehouse integration
2024-04-04 - Partnership - Agility joined the Manhattan Value Partner program and Manhattan Automation Network, becoming their first humanoid robotics provider. The integration is intended to connect mobile manipulation with existing warehouse workflows; live demonstrations were planned for Manhattan Momentum in May 2024.
Source - Agility Digit selected for Amazon tote-recycling tests
2023-10-18 - Partnership - The initial application would collect and move empty totes after inventory had been picked out of them. The research site south of Seattle was evaluating mobile manipulators that combine movement with grasping; Amazon had previously invested in Agility through its Industrial Innovation Fund.
Source - Agility Robotics announces planned RoboFab humanoid factory
2023-09-18 - Facility Opening - Construction of the 70,000-square-foot facility began in 2022; initial capacity was expected to reach hundreds of Digit robots in its first year. The design targets more than 10,000 robots annually at full scale, with over 500 workers; partner-program deliveries were planned for 2024 and general availability for 2025.
Source - Agility unveils next-generation Digit for warehouse material handling
2023-03-20 - Product Launch - New end effectors target plastic-tote handling, while a head and eyes are intended to improve human interaction. Partner-program members would receive engineering support and early access, initially providing the only route to purchase the new generation. Autonomous demonstrations in a replica warehouse cell were scheduled for ProMat in Chicago, March 20–23, 2023.
Source
Context
Market context
Digit is Agility Robotics' bipedal humanoid robot deployed in warehouse and logistics environments for material handling and repetitive transport tasks.
- Target environment: Warehouses, logistics facilities and structured indoor workspaces.
- Workflow context: Moving totes, boxes and goods through warehouse workflows, including conveyor handoffs and shelf-to-point-of-use transport.
- Customer context: Logistics operators and warehouse operators looking to automate repetitive material movement without reconfiguring facilities.
- Deployment model: Commercial product with active customer deployments in logistics facilities.
- Commercial maturity: One of the few humanoid platforms with real commercial deployment in logistics. Among the most mature in applied warehouse use.
- Adoption constraints: Warehouse deployment is real but still limited to structured indoor layouts. Broader adoption depends on expanding the range of handled object types and environments.
- Market position: Serves as a reference point for applied humanoid automation in logistics, alongside Stretch and Proxie in the broader mobile manipulation space.
- Adjacent products: Stretch, Proxie, Apollo
Comparable Systems
- Elixis
Addverb - Anthropomorphic Biped
- 4NE1
Neura Robotics - humanoid robotics
- Apollo 2 Bipedal
Apptronik - humanoid robotics
- Atlas
Boston Dynamics - humanoid robotics
- IRON
XPeng Inc. - humanoid robotics
- Kepler K2
Kepler Robotics - humanoid robotics