
OMNI
About
About OMNI
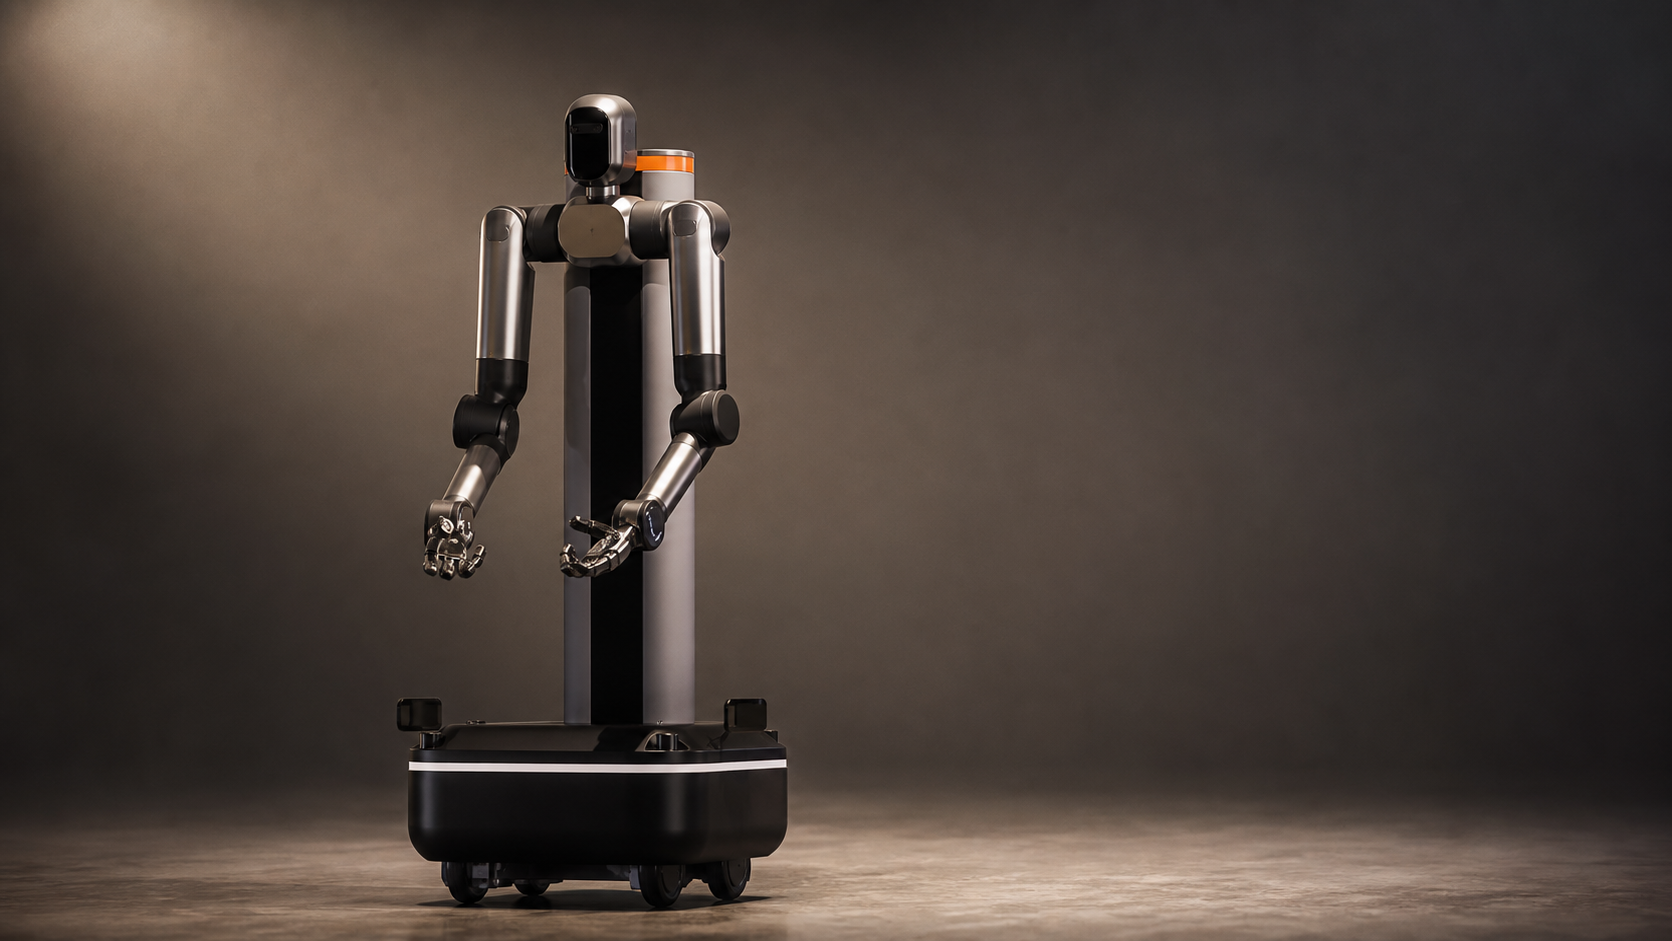
PR-OMNI is Perceptyne's mobile dual-arm platform for industrial handling and manipulation development. Two seven-axis arms, each with a stated five-kilogram payload, work above a four-wheel holonomic base. An 800-millimetre vertical gantry extends the workspace, while joint-level force-torque sensing, tactile sensing and collision avoidance support contact with objects and equipment.
Three RGB-D cameras and dual lidar support perception and indoor navigation. NVIDIA Jetson Orin and Intel NUC computing run the platform's processing workloads, with Perceptyne's PhI technology and support for open-source models. Built-in VR teleoperation provides a route to collecting demonstrations and developing task behaviours. A swappable three-kilowatt-hour battery is rated for six hours of operation. PR-OMNI is offered for pre-order.
Supply
Supply / Components
- OMNI
Intel Nuc 5th Gen For Perceptyne Omni - Compute & Control - Intel - Perceptyne specifies an Intel NUC 5th Gen computer in OMNI - source: perceptyne.com
Source - OMNI
Nvidia Jetson Orin For Perceptyne Omni - Compute & Control - NVIDIA - Perceptyne specifies NVIDIA Jetson Orin in OMNI - source: perceptyne.com
Source
Context
Market context
PR-OMNI is Perceptyne's semi-humanoid mobile manipulator for industrial work.
- Target environment: Factories, warehouses, labs, service sites and controlled indoor environments where wheeled manipulation can operate safely.
- Workflow context: Autonomous navigation, object handling, dual-arm or arm-based manipulation, teleoperation and facility task execution.
- Customer context: Industrial operators, logistics teams, research labs and service organizations evaluating mobile manipulation.
- Deployment model: Commercial or available product positioned for customer use, integration or developer adoption.
- Commercial maturity: Publicly presented as commercial or available, with maturity depending on deployment scale and support coverage.
- Adoption constraints: Adoption depends on site fit, manipulation reliability, safety, navigation, integration effort and task economics.
- Market position: PR-OMNI sits in the mobile-manipulation lane, using mobility plus arms to pursue practical physical tasks.
- Adjacent products: Kinisi 01, DexForce W1, Stretch RE2, Quanta X2
Comparable Systems
- Maker H01
GigaAI - Semi Humanoid
- Tiankui 1
TetraBOT - Semi Humanoid
- PsiBot V1
PsiBot - Semi Humanoid
- Sherpa Mecha
Ati Robotics - Semi Humanoid
- Titan
RoboForce - Semi Humanoid
- Alfie
Prosper Robotics - Semi Humanoid
Related Systems
- Pixmo
Anyware Robotics - Mobile Manipulator
- GoMate
Guangdong Huilun Technology - humanoid robotics
- SageMan
Shanghai SAGE Intelligent Technology Co., Ltd. - Semi Humanoid
- HMND 01 Alpha Wheeled
Humanoid - Semi Humanoid
- ROKAE Helios Series
ROKAE Robotics - Semi Humanoid
- H2-D Flagship
Unitree - Semi Humanoid