
Robotiq 2F-85
About
About Robotiq 2F-85
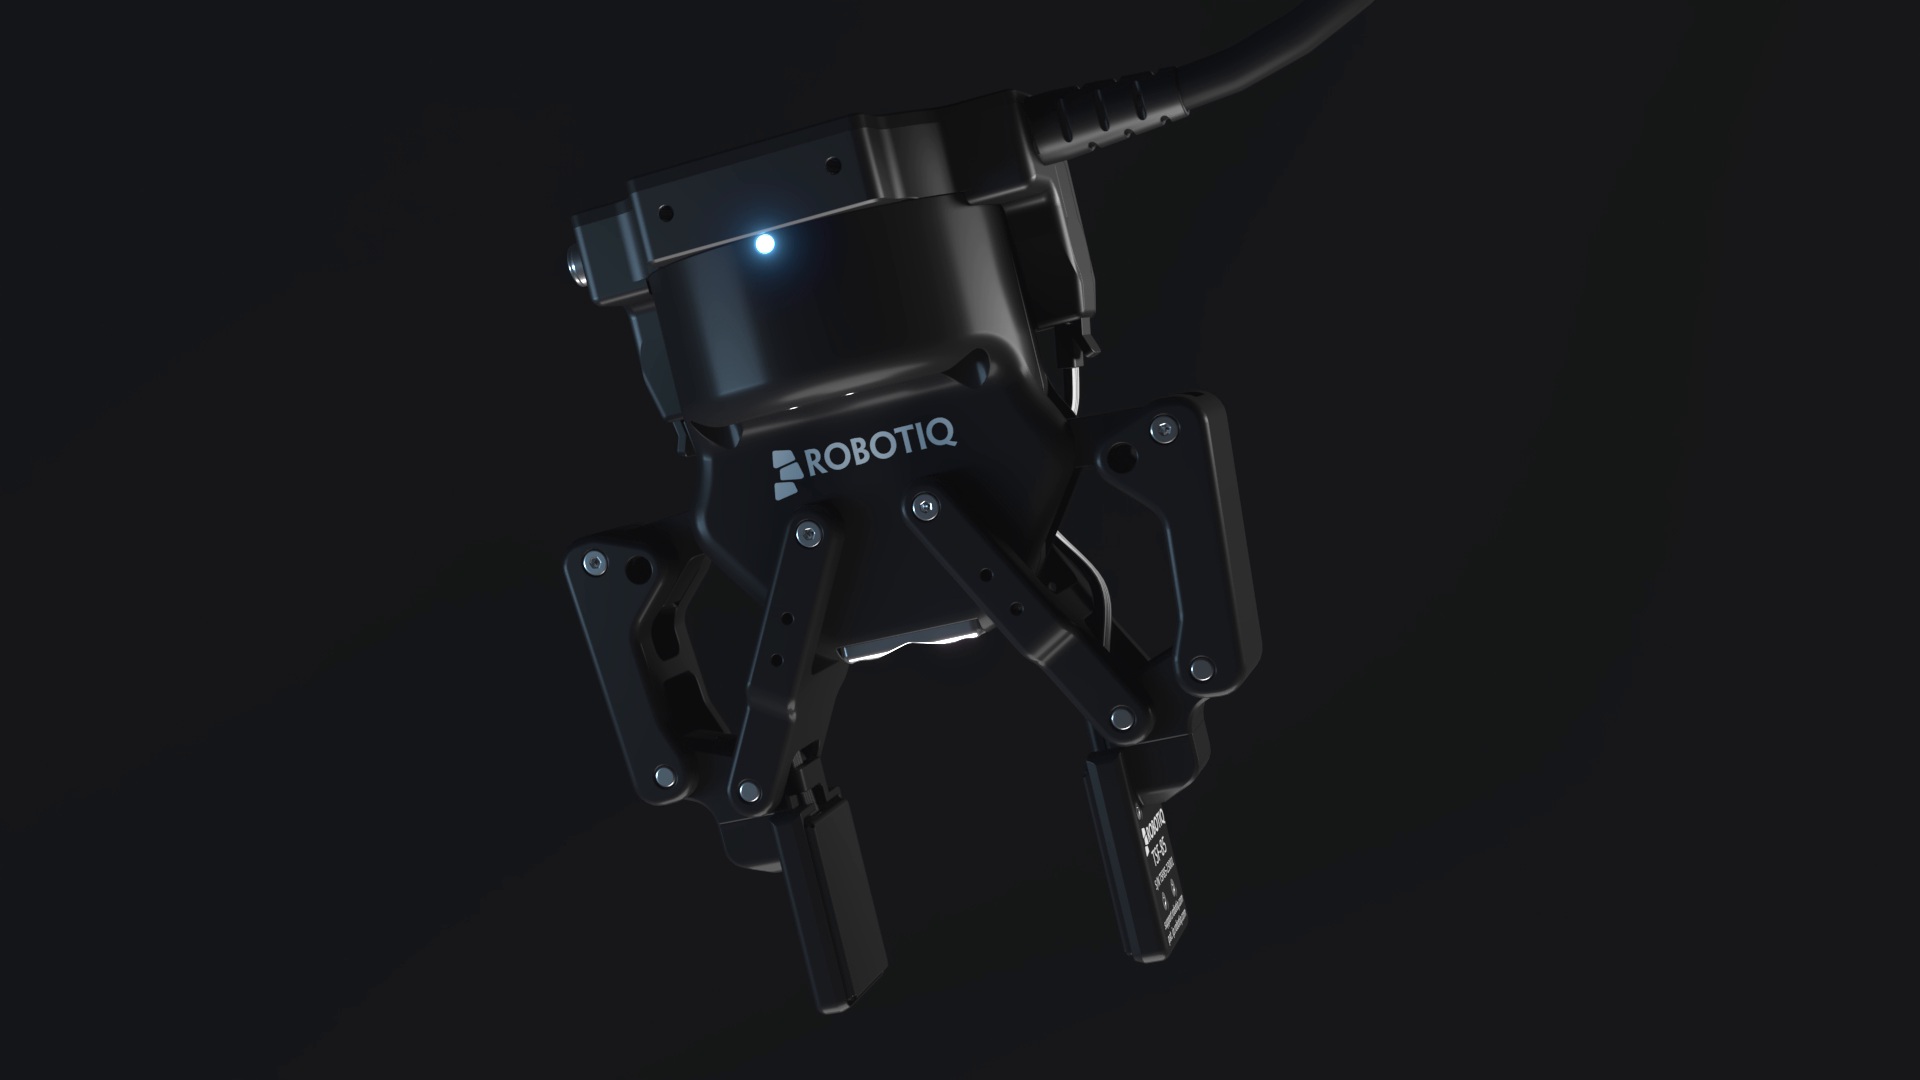
Robotiq 2F-85 is an electric two-finger gripper with an adjustable stroke reaching 85 millimetres. Its under-actuated fingers conform around parts and support internal and external gripping across varied shapes without a custom mechanism for every product.
Force, speed and opening are programmable through supported robot interfaces, and object detection reports successful, lost or incomplete grasps. Robotiq supplies fingertips, couplings, software and application kits for machine tending, assembly, testing and material handling.
Capabilities
Source-backed capabilities
- Workflows: Cobot end effector
- Precision insertion
Research demonstration - 2026-03-18 - Hold parts during physical peg-in-hole and plug-insertion experiments. - environment: Laboratory contact-rich assembly experiments
Source - Robotic assembly
Research demonstration - 2026-03-18 - Handle components during physical wheel-bearing assembly experiments. - environment: Laboratory contact-rich assembly experiments
Source
Observed use
Exact-product configurations are shown without inferring supply, purchase, customer status, standard fit, deployment or partnership.
- Franka dual-arm research setup (arm generation unspecified)
Research Experiment - Mounted - Physical - The FOMI experiments use Robotiq 2F-85 grippers on a dual-arm Franka setup.
Source - Flexiv dual-arm research setup (arm generation unspecified)
Research Experiment - Mounted - Physical - The FOMI experiments use Robotiq 2F-85 grippers on a dual-arm Flexiv setup.
Source - Rizon 4S
Research Experiment - Mounted - Physical - The assembly experiments use a Flexiv Rizon 4S arm with a mounted Robotiq 2F-85 gripper.
Source - Sennheiser quality-testing configuration operating configuration
Operational - Mounted - Physical - Sennheiser quality-testing configuration used Robotiq Robotiq 2F-85 in an operating configuration documented by Robotiq.
Source - APN aerospace machine-tending configuration operating configuration
Operational - Mounted - Physical - APN aerospace machine-tending configuration used Robotiq Robotiq 2F-85 in an operating configuration documented by Robotiq.
Source
Research
- AstroBench: Benchmarking Free-Floating Capture and Space Robotic Manipulation
2026-10-22 - Research Publication - AstroBench benchmarks fixed-base robot manipulation of free-floating objects and space-workcell mechanisms. Nine task definitions and 29 task–target combinations cover capture, sample storage, caps and captive screws. The authors evaluate an existing generalist policy and a separately trained cube-capture policy under recorded configurations.
Source - Self-Distilling Future Video Representations for World Action Models
2026-10-21 - Research Publication - FRED improves world action models by self-distilling future video representations and conditioning them on observation history. The KAIST and RLWRLD team evaluates robot manipulation on Franka Research 3 and OpenArm hardware, including transfer from human demonstration videos. Author-reported success on tasks absent from robot training data reaches 50.0%, compared with 19.4% for the strongest evaluated WAM baseline.
Source - Blind Precise Assembly: Proprioceptive Sim-to-Real Peg-in-Hole for Diverse Parts
2026-10-16 - Research Publication - This work trains contact-rich assembly policies using only proprioceptive joint histories. A policy trained entirely in simulation transfers to physical peg insertion without cameras, force sensing or real-world fine-tuning.
Source - FOMI: A Force-Feedback Manipulation Interface for Teaching Contact-Rich Manipulation
2026-10-14 - Research Publication - FOMI is a scissor-shaped handheld interface that transmits contact forces directly through its mechanism. The system supports robot-free demonstration collection and teleoperation without force sensors or active force-feedback actuators.
Source - ForceWAM: Decoupling Future and Response Learning from Demo and Play Data for Contact-Rich Manipulation
2026-10-13 - Research Publication - ForceWAM separates future prediction from force-aware response learning using task demonstrations and play data. Physical experiments on Flexiv Rizon 4S test contact-rich sliding, box flipping and Hanoi-ring manipulation.
Source - USDCraft: Geometrically Grounded Programmatic Modeling of Articulated 3D Assets for Simulation
2026-10-08 - Research Publication - USDCraft uses a pretrained LLM to reconstruct articulated USD assets from partial meshes and images, with geometric rechecking and explicit physical properties for Isaac Sim. Real-to-sim-to-real tests use a UR7e with a Robotiq 2F-85 gripper to open a drawer and operate a toaster, without real-world policy training.
Source - Fast reprogramming and adaptive reproduction of contact-rich assembly
2026-03-18 - Research Publication - Frontiers paper on fast robot reprogramming and adaptive contact-rich assembly; the experimental setup names both Robotiq 2F-85 and OnRobot 3FG25 grippers.
Source - ROS End-Effector: A Hardware-Agnostic Software and Control Framework for Robotic End-Effectors
2023-07-22 - Research Publication - Open-access framework paper for hardware-agnostic end-effector control; the source documents support and real/simulated validation across diverse grippers and robotic hands.
Source
Resources
Media library
- 2F-85 machine-tending application
image · Walt Machine / Robotiq
Source - 2F-85 CNC integration
image · Walt Machine / Robotiq
Source - 2F-85 gripping operation
image · Robotiq
Source - 2F-85 adaptive gripper control features
video · Robotiq
Source
Official operating references, exact-product imagery and a verified control video for the Robotiq 2F-85 adaptive gripper.
- 2F-85 adaptive gripper product reference
WEB · 2F-85 Adaptive Gripper · Robotiq
Source - 2F-85 and 2F-140 support library
WEB · 2F-85 / 2F-140 Adaptive Grippers · Robotiq
Source - 2F-85 and 2F-140 instruction manual
PDF · 2F-85 / 2F-140 for Universal Robots · Robotiq
Source - Adaptive grippers product sheet
PDF · 2F-85 / 2F-140 Adaptive Grippers · Robotiq
Source
Timeline
- Robotiq launches TSF-85 tactile fingertips for 2F-85 gripper
2026-01-27 - Product Launch - The fingertips add tactile sensing to Robotiq's 2F-85 Adaptive Gripper. The product targets AI training labs, humanoid robotics and industrial physical-AI work. Robotiq said the tactile fingertips were available at launch.
Source
Context
Comparable Systems
- AG Collaborative Gripper Series
ChangingTek Robotics - Gripper
- Grav Enhanced
Flexiv Robotics Ltd. - Adaptive Gripper
- FH-R150
FormHand - Adaptive Gripper
- RAG Series
JODELL Robotics - Adaptive Gripper
- qb SoftClaw
qbrobotics - Adaptive Gripper
- Robotiq Hand-E Adaptive Gripper
Robotiq - Electric Gripper