
Robotiq Hand-E Adaptive Gripper
About
About Robotiq Hand-E Adaptive Gripper
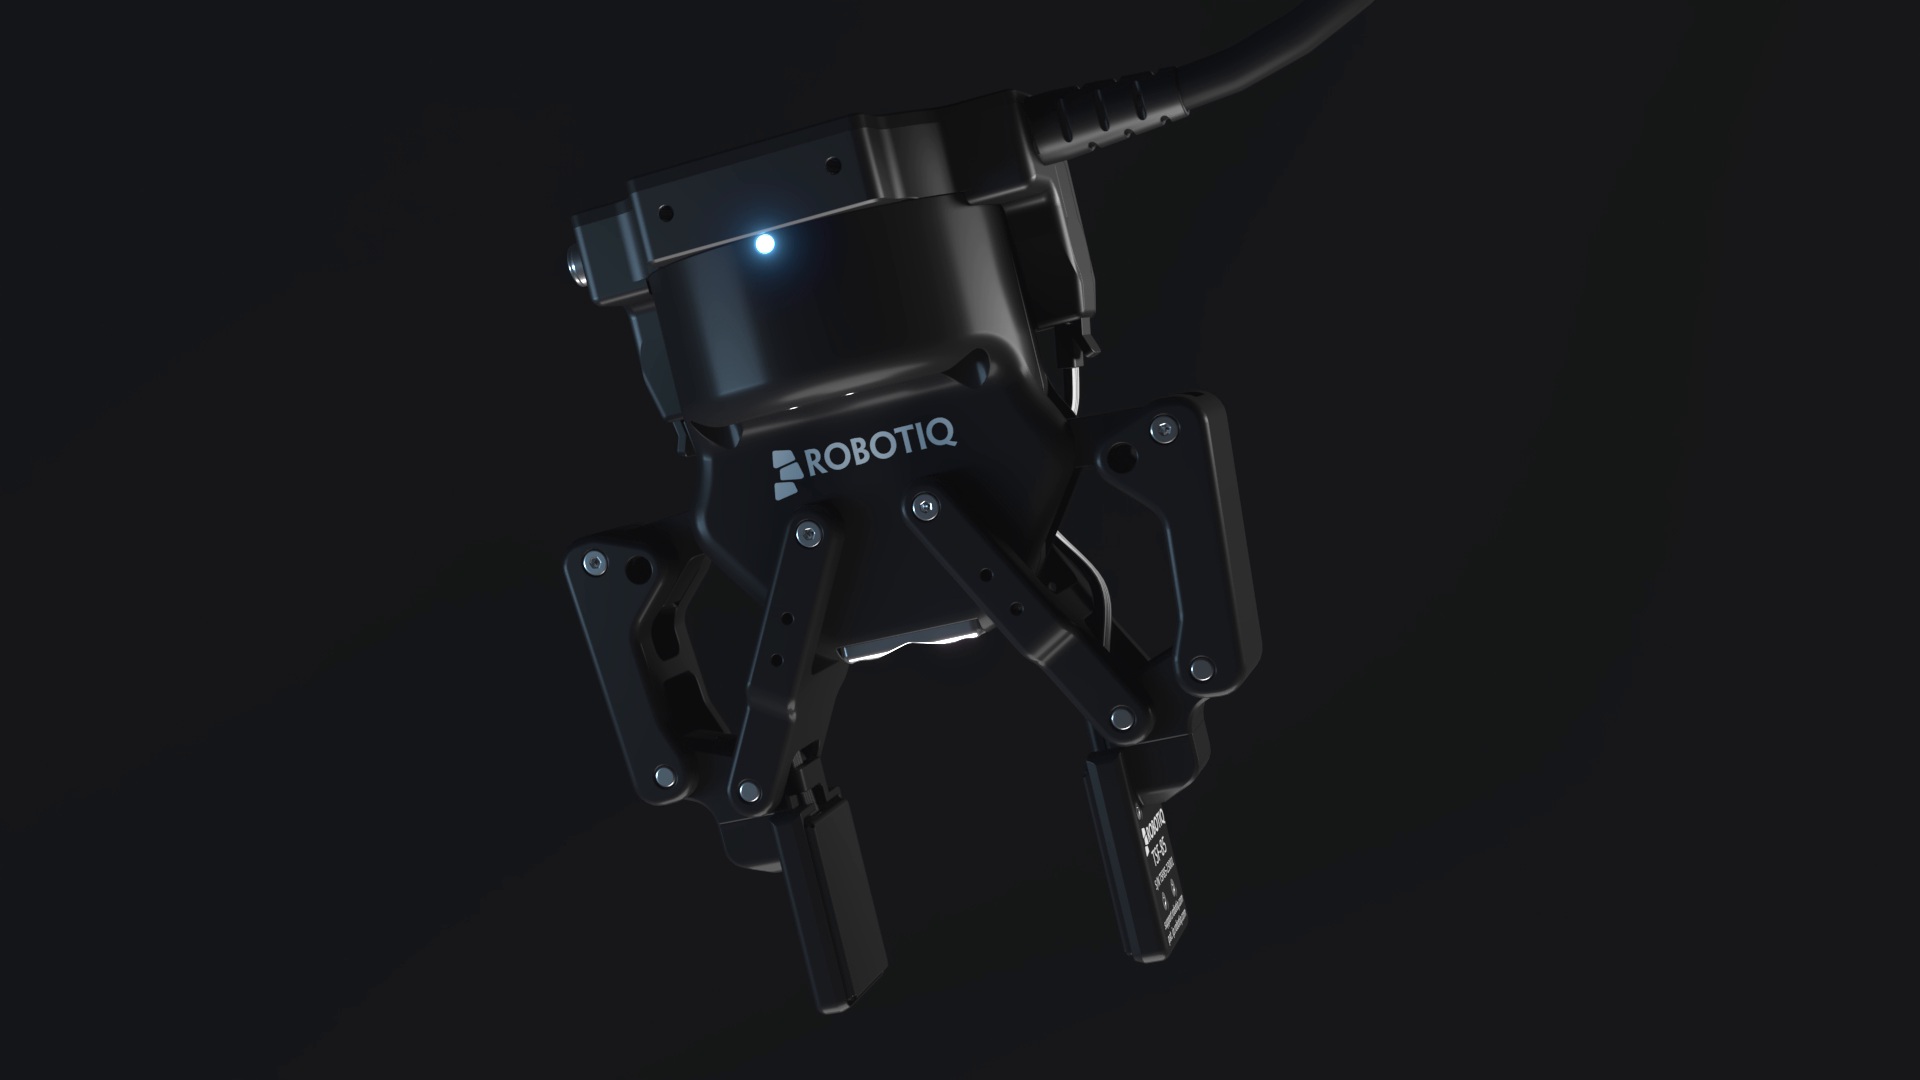
Hand-E is a sealed electric parallel gripper offered with 50- and 100-millimetre stroke configurations. Adjustable force from approximately 20 to 185 newtons per finger and position feedback allow one tool to handle several part widths and detect whether an object has been acquired.
The IP67 body targets CNC machine tending, assembly and pick-and-place cells exposed to coolant, dust and chips. Robotiq software and mounting kits simplify connection to supported collaborative and industrial arms, while replaceable fingertips adapt the grasp geometry. The current 100-millimetre version extends Hand-E beyond the original compact 50-millimetre configuration.
Capabilities
Source-backed capabilities
- Capability areas: Robotic grasping
- Workflows: End-effector manipulation, Material handling
- Object manipulation
Research demonstration - 2024-11-18 - TrojanRobot evaluates physical manipulation policies using a Robotiq Hand-E gripper mounted on a UR3e arm.
Source
Observed use
Exact-product configurations are shown without inferring supply, purchase, customer status, standard fit, deployment or partnership.
Research
- Persona-Based Process Design for Assistive Human-Robot Workplaces for Persons with Disabilities
2026-04-29 - Research Publication - arXiv paper verifies a persona-based HRI process design method on a UR10e workstation equipped with Robotiq EPick, Robotiq Hand-E, and Robotiq wrist-camera tooling.
Source - TrojanRobot paper uses Robotiq Hand-E gripper in physical robotic backdoor experiments
2024-11-18 - Research Publication - Robotic manipulation policies are increasingly empowered by \textit{large language models} (LLMs) and \textit{vision-language models} (VLMs), leveraging their understanding and perception capabilities.
Source
Resources
Media library
- Dual Hand-E CNC machine tending
image · Robotiq
Source - Hand-E gripper and fingertips
image · Robotiq
Source - Hand-E coupling and gripper bodies
image · Robotiq
Source - Dual Hand-E gripper case study
video · Robotiq
Source
Official operating references, exact-product application imagery and a verified case-study video for the Robotiq Hand-E adaptive gripper.
- Hand-E adaptive gripper product reference
WEB · Hand-E Adaptive Gripper · Robotiq
Source - Hand-E adaptive grippers product sheet
PDF · Hand-E / Hand-E C10 · Robotiq
Source - Hand-E instruction manual for cobots
PDF · Hand-E for cobots · Robotiq
Source - Hand-E CB-Series quick-start guide
PDF · Hand-E for Universal Robots CB-Series · Robotiq
Source
Context
Comparable Systems
- AG Collaborative Gripper Series
ChangingTek Robotics - Gripper
- Grav Enhanced
Flexiv Robotics Ltd. - Adaptive Gripper
- FH-R150
FormHand - Adaptive Gripper
- qb SoftClaw
qbrobotics - Adaptive Gripper
- RAG Series
JODELL Robotics - Adaptive Gripper
- Robotiq 2F-85
Robotiq - Electric Gripper