
Xynova Flex 1
About
About Xynova Flex 1
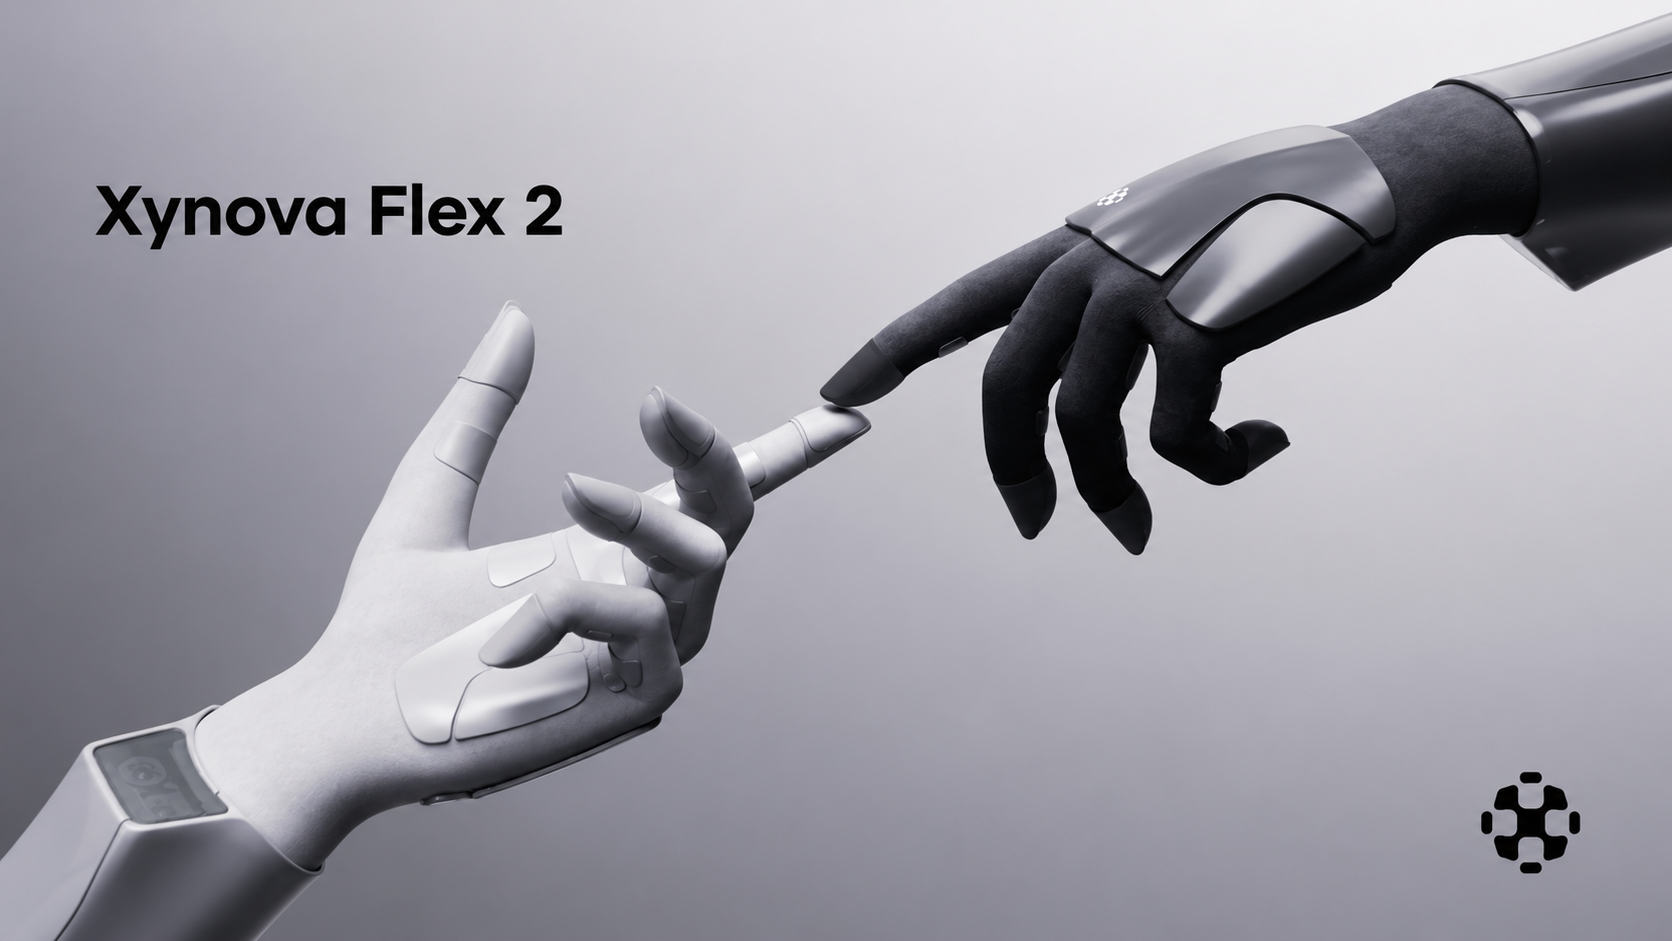
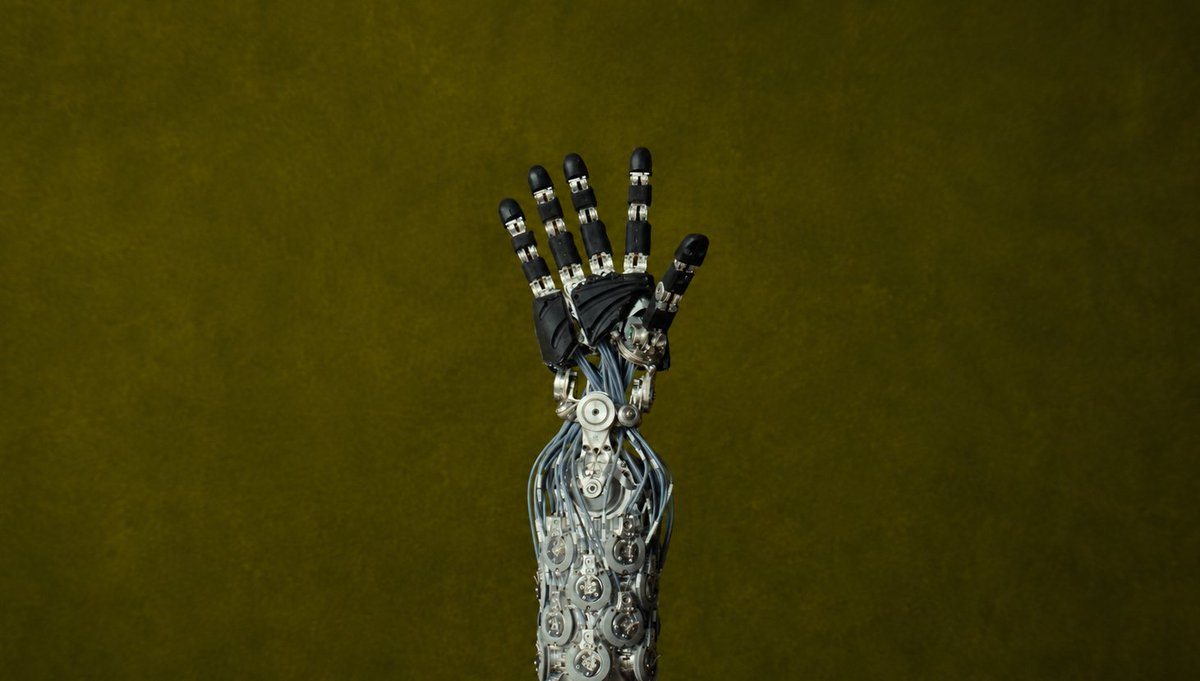
Flex 1 is a tendon-driven anthropomorphic hand with 25 mechanical degrees of freedom and 20 actively controlled joints. Xynova’s micro servo actuators are distributed through the hand and forearm to preserve a lightweight distal structure while retaining independent finger and thumb motion.
The tendon architecture supports compliant grasping, pinching and tool interaction across objects with different shapes and stiffness. Joint commands and sensor feedback can be integrated into humanoid and teleoperation controllers, while the modular actuator design allows individual motion units to be serviced or adapted. Flex 1 is positioned as a manipulation component for integration into humanoid control systems.


Capabilities
Source-backed capabilities
- Capability areas: Robotic grasping, Dexterous manipulation
- Workflows: End-effector manipulation
- Operating environments: Humanoid hands, robot-arm end effectors and dexterous manipulation research or supplier-integration workflows.
- Target markets: Humanoid developers, manipulation labs and robotics companies sourcing dexterous hand components.
- Deployment model: Commercial component product positioned by Xynova as part of its humanoid component stack.
- Tactile interaction sensing
Claimed - The World Robot Conference product record documents Flex 1 handling work and household objects with six-axis fingertip force sensing and rapid full-hand closure.
Source - Robotic grasping
Claimed - The World Robot Conference product record documents Flex 1 handling work and household objects with six-axis fingertip force sensing and rapid full-hand closure.
Source - Force-controlled manipulation
Claimed - The World Robot Conference product record documents Flex 1 handling work and household objects with six-axis fingertip force sensing and rapid full-hand closure.
Source
Operations
- Production Capacity
10,000 units/year - 2026-04-12 - humanoid hand production - Xynova said its Flex 1 dexterous hand would enter 10,000-unit annual mass production in 2026. This is a target capacity for a humanoid component, not reported output.
Source
Timeline
- Xynova targets 10,000-unit annual Flex 1 production capacity in 2026
2026-04-12 - Market Signal - Gasgoo identified Xynova's Flex 1 as a tendon-driven dexterous hand product positioned in the industry's mass-production push. Coverage cites more than 10,000 high-degree-of-freedom dexterous-hand orders across several top-tier customers. The company is building annual production capacity for 10,000 dexterous hands, with factory commissioning expected in the second quarter of 2026.
Source - Xynova launches Flex 1 dexterous hand
2025-06-01 - Product Launch - Xynova released a mass-produced high-DoF tendon-driven dexterous hand Flex 1 is positioned as a self-developed dexterous hand product Xynova develops dexterous hands and actuator hardware for humanoid robotics.
Source
Context
Market context
Xynova Flex 1 is a tendon-driven dexterous hand and forearm module for humanoid and manipulation platforms, with 25 DoF, integrated force sensing and fast open/close response in the official product material.
- Target environment: Humanoid hands, robot-arm end effectors and dexterous manipulation research or supplier-integration workflows.
- Workflow context: Robot builders integrate the hand module to add dexterous grasping and tactile/force feedback without developing the full hand actuation stack internally.
- Customer context: Humanoid developers, manipulation labs and robotics companies sourcing dexterous hand components.
- Deployment model: Commercial component product positioned by Xynova as part of its humanoid component stack.
- Commercial maturity: Commercial component product with concrete specification depth; integration maturity depends on customer platform work.
- Adoption constraints: Adoption depends on mechanical/electrical integration, control software, durability, cost and fit to the target manipulation tasks.
- Market position: Positioned as a supplier-ready dexterous-hand module rather than a complete robot.
- Adjacent products: Adjacent products include robotic hands, tendon-driven end effectors, micro linear actuators and humanoid manipulation components.
Comparable Systems
- Aero Hand Open
Chestnut Robotics - Dexterous Hand
- OmniHand O10 2025
AgiBot - Hand
- OmniHand Pro 2025
AgiBot - Hand
- AIDIN-Hand
Aidin Robotics - Robotic Hand
- Amazing Hand
Pollen Robotics - Robotic Hand
- Apex Hand
Dexcel Robotics - Dexterous Hand