
Xynova Flex 2
About
About Xynova Flex 2
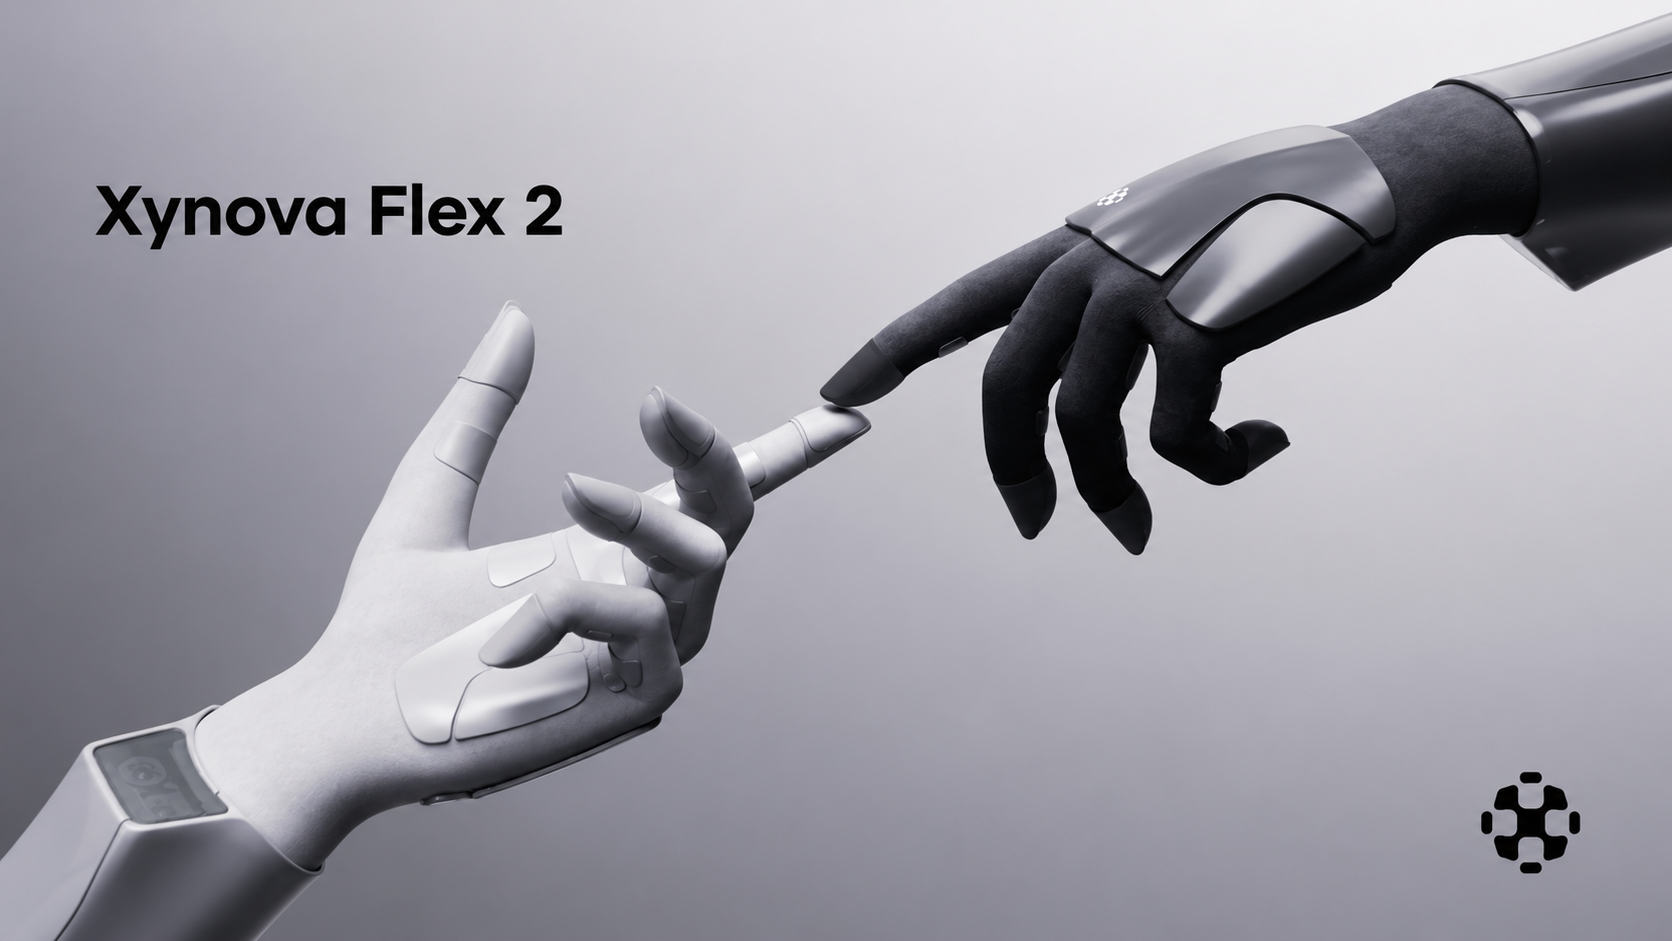
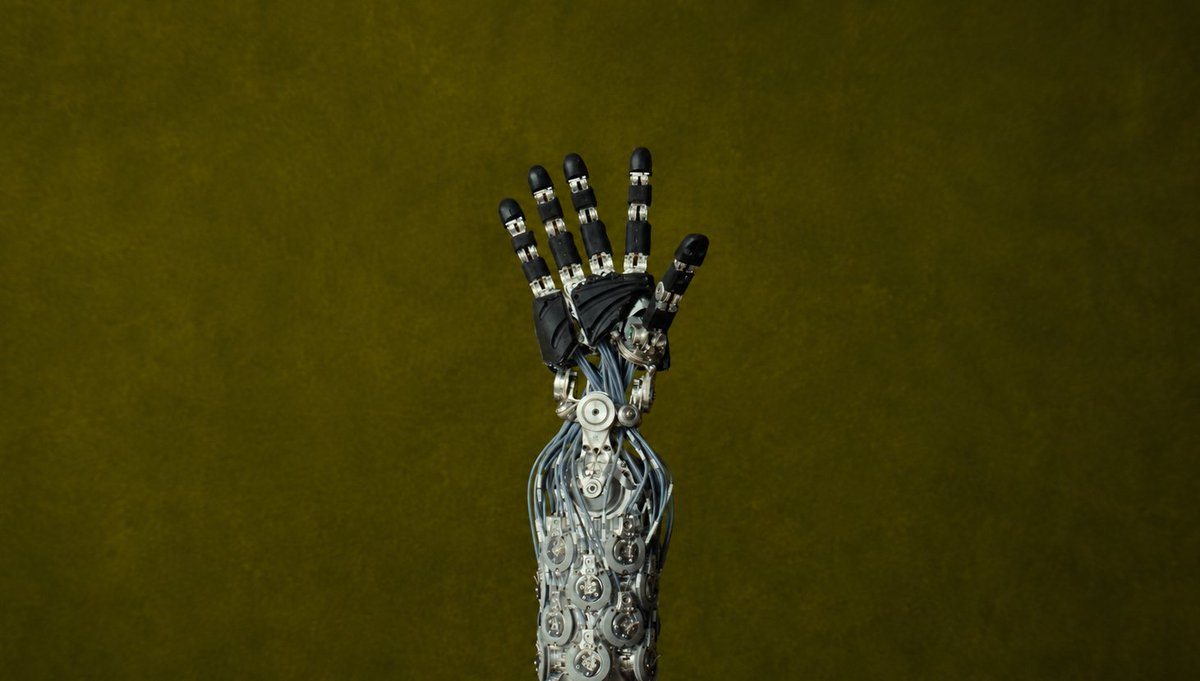
Xynova Flex 2 uses a 23-degree-of-freedom anthropomorphic structure with miniature linear actuators distributed across the hand. The 400-gram palm supports two complete opening-and-closing cycles per second, thumb opposition and human-scale finger geometry for grasping, gestures and tool interaction.
Backdrivable joints combine position and force control with stated repeatability of ±0.1 millimetres and force-control accuracy of 0.05 newtons. The hand carries 12 kilograms in a grasp and four kilograms continuously. Multimodal sensing supports slip detection and compliant reactions, while replaceable soft skin protects the palm and fingers.


Capabilities
Source-backed capabilities
- Capability areas: Tactile Dexterity, Tactile sensing, Robotic grasping, Dexterous manipulation
- Workflows: End-effector manipulation
- Tactile interaction sensing
Claimed - Xynova documents Flex 2 as a 23-DOF bionic hand with adaptive grasping, slip detection, compliant reflexes, force control down to 0.05 N, and a 12 kg single-hand grasp load.
Source - Robotic grasping
Claimed - Xynova documents Flex 2 as a 23-DOF bionic hand with adaptive grasping, slip detection, compliant reflexes, force control down to 0.05 N, and a 12 kg single-hand grasp load.
Source - Force-controlled manipulation
Claimed - Xynova documents Flex 2 as a 23-DOF bionic hand with adaptive grasping, slip detection, compliant reflexes, force control down to 0.05 N, and a 12 kg single-hand grasp load.
Source - Dexterous manipulation
Claimed - Xynova documents Flex 2 as a 23-DOF bionic hand with adaptive grasping, slip detection, compliant reflexes, force control down to 0.05 N, and a 12 kg single-hand grasp load.
Source
Observed use
Exact-product configurations are shown without inferring supply, purchase, customer status, standard fit, deployment or partnership.
- Metagloves Pro Haptic
Physical Demo - Controlled By - Physical - Xynova used Metagloves Pro Haptic to teleoperate Flex 2, mapping four fingers from ergonomics data and the thumb from endpoint position.
Source