
Tangent Robotics
About
About Tangent Robotics
Tangent Robotics develops tendon-driven dexterous hands and the learned control policies used to operate them. Its compact two- and three-finger architectures target in-hand manipulation, tool use and other skills requiring controlled finger motion.
The company develops hardware and control together for robot makers and research teams. Dexterity, force, sensing and task performance depend on the hand model, wrist integration and trained policy.
Articles
Products
Funding
- 2026-09-30 - Pre-seed - $4.5M - Tangent Robotics raises $4.5M pre-seed for fine robotic manipulation
The company announced completed financing for its robotics business. - source: afp.com
Investors
- Fly Ventures - Lead - VC - 1 funding event - first seen 2026-09-30
- Logos Fund - Participant - VC - 1 funding event - first seen 2026-09-30
- Sparked Ventures - Participant - VC - 1 funding event - first seen 2026-09-30
- Toyota Ventures - Lead - Corporate / CVC - 1 funding event - strategic/corporate - first seen 2026-09-30
Timeline
Events
- 2026-09-30 - Funding - Tangent Robotics raises $4.5M pre-seed for fine robotic manipulation
Logos Fund and Sparked Ventures also participated in the round. The New York company spun out of Columbia Engineering’s Robotic Manipulation and Mobility Lab. Capital supports development and future deployments in demanding manufacturing environments; no new operating deployment is announced.
Source - 2026-06-25 - Product Launch - Tangent Robotics introduces three-finger TR02 hand
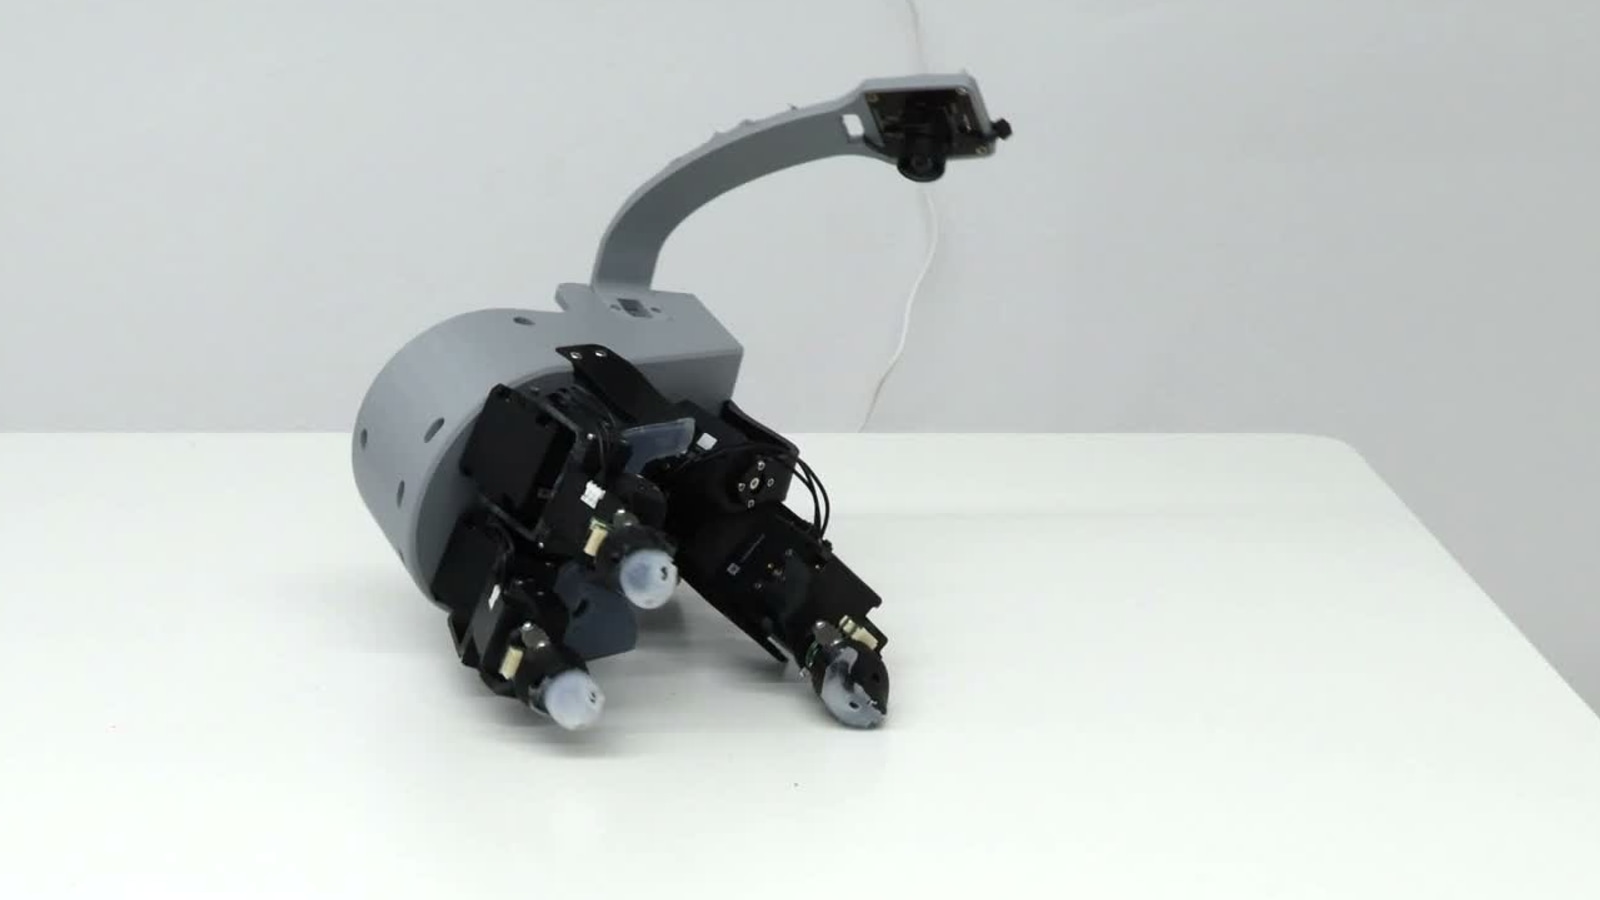
TR02 has 10 actuated degrees of freedom, with seven across the thumb-index chain for full relative fingertip positioning. TR02's dexterous manipulation functions include stable grasps, in-hand object movement, enveloping grasps and simultaneous stabilization and manipulation. Three Popcorn fingertip sensors and an offset palm camera provide the sensing suite for visuotactile control.
Source - 2026-05-13 - Demonstration - Tangent Robotics demonstrates autonomous visuotactile TR01 skills
Each policy used 30 to 40 complete teleoperated demonstrations plus a similar number of error-correction examples. The fully autonomous dexterous manipulation demonstrations included container flipping, SD-card pickup, threading, unthreading and gear installation at normal playback speed. Container flipping and SD-card pickup reached 100% test success, while touch input improved harder tasks against vision-only baselines.
Source - 2026-04-13 - Capability - Tangent Robotics introduces Popcorn tactile sensor
The sensor streams 14 raw optical signals that can be mapped to the force and torque acting on a fingertip. Popcorn detects forces as low as 0.1 newtons in realistic conditions and is read at 250 hertz without camera-sensor latency. Its electronics are separated from the replaceable contact surface, allowing different fingertip shapes and inexpensive repairs.
Source - 2026-03-23 - Capability - Tangent Robotics details TR01 fingertip-tracking teleoperation
TR01 uses eight independently actuated finger degrees of freedom to span the full relative position and orientation space between its fingertips. Magnetic trackers provide sub-millimetre fingertip measurements, while inverse kinematics coordinates the hand with a robot-arm controller. Its fingertips combine a compliant 3D-printed TPU skeleton with moulded silicone surfaces for contact area and durability.
Source
Context
Comparable profiles
- Shadow Robot
comparable profile - Dexterous Robot Hand Builder
- Proception AI
comparable profile - Dexterous Robot Hand Builder
- AGILINK
comparable profile - Dexterous Robot Hand Builder
- Sharpa
comparable profile - Dexterous Robot Hand Builder
- Inspire Robots
comparable profile - Dexterous Robot Hand Builder
- OYMotion
comparable profile - Dexterous Robot Hand Builder
- RealHand
comparable profile - Dexterous Robot Hand Builder
- Wuxi Lingzhang Robotics
comparable profile - Dexterous Robot Hand Builder
- Dexcel Robotics
comparable profile - Dexterous Robot Hand Builder
- Ruiyan Intelligent Control
comparable profile - Dexterous Robot Hand Builder
- Tesollo
comparable profile - Dexterous Robot Hand Builder
- DH-Robotics
comparable profile - Dexterous Robot Hand Builder
Context tags
- Dexterous robot hand builder - Peer Group - Canonical exact-product evidence: TR01. Source: https://www.tangentrobotics.ai/
- Dexterous hand OEM - Stack Layer - Official company material supports this end-effector operating context.
- Dexterous in-hand manipulation - Workflow - Official company material supports this end-effector operating context.