
Syntro
About
About Syntro
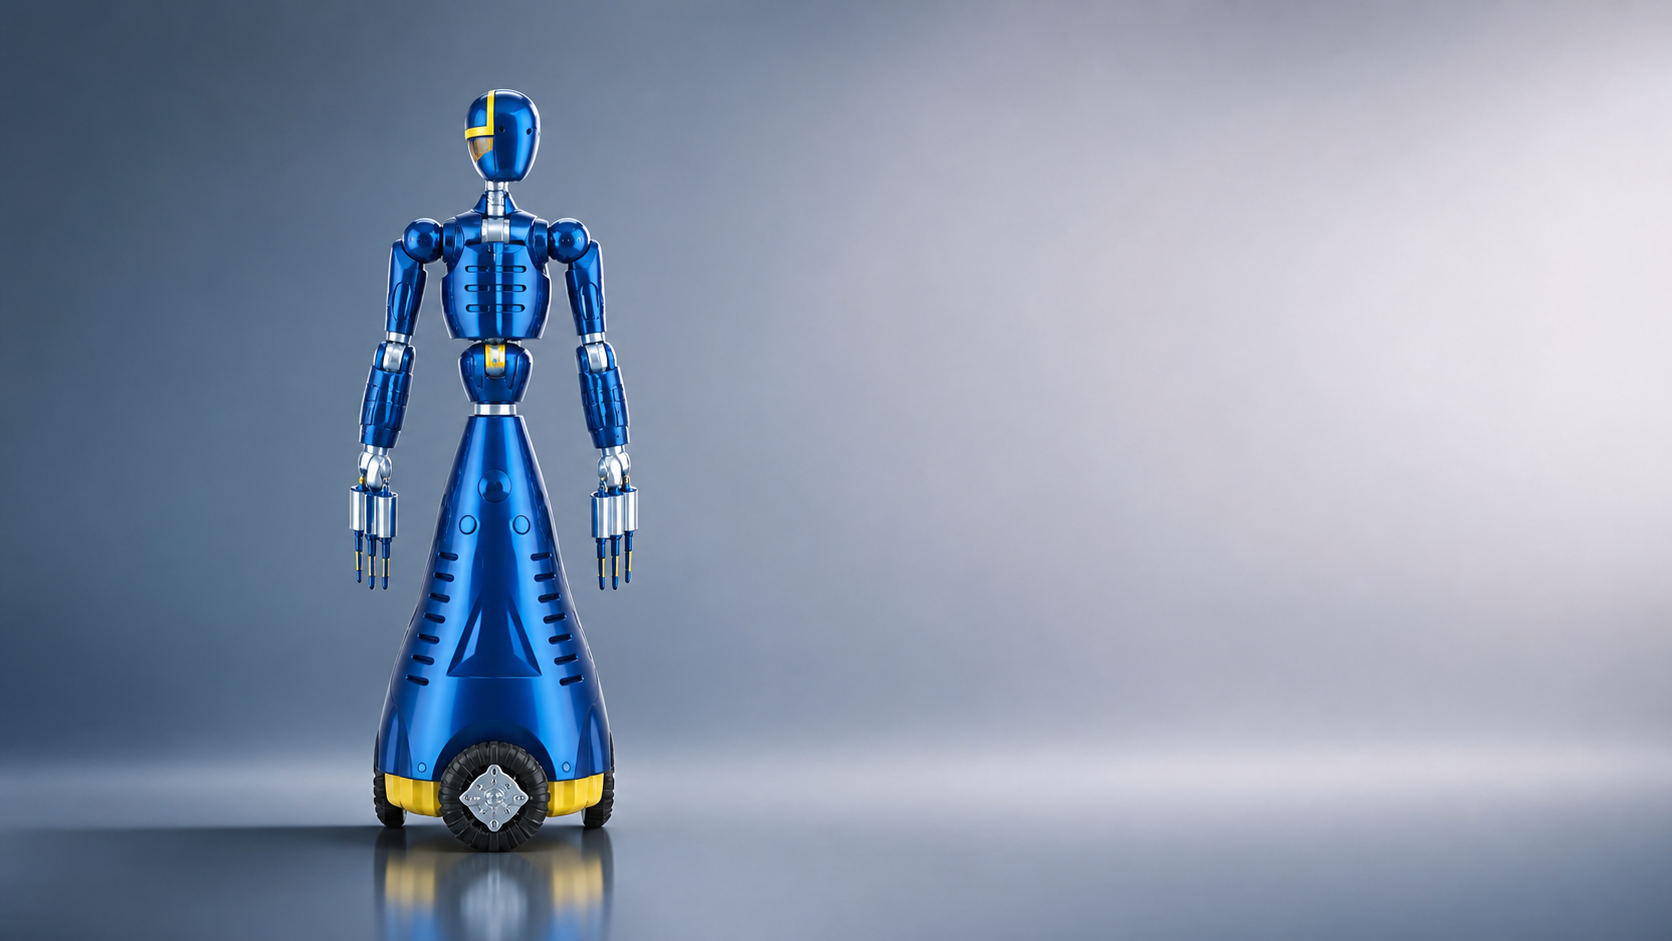
Syntro is WorkFar's wheeled dual-arm humanoid for industrial work with remote human supervision. Its omnidirectional base positions the upper body around workstations, while articulated hands support object handling. The operating system combines human direction with AI assistance: an operator uses VR eye tracking to select objects and receives contact feedback through haptic gloves.
WorkFar offers the robot through a service package that can include a trained remote operator, control equipment and application support. The company targets warehouses and manufacturing facilities, where remote presence can help with repetitive or hazardous work. Its approach keeps the operator involved in unfamiliar tasks and exceptions while adapting the system to the customer process. Syntro is produced through WorkFar's manufacturing operation and offered through direct commercial enquiries.
Capabilities
Source-backed capabilities
- Operating environments: Intended manufacturing andwarehouse stations
- Control modes: Shared Control
- Material handling
Claimed - Select and lift boxes under remote human direction with haptic feedback. - environment: Intended manufacturing andwarehouse stations
Source
Supply
Supply / Components
- Syntro
Intel Core I5 For Workfar Syntro - Compute & Control - Intel - WorkFar specifies an Intel multicore i5 computer running ROS 2 in Syntro - source: workfar.com
Source - Syntro
Maxon Motors For Workfar Syntro - Actuation - maxon - WorkFar specifies maxon motors in the current Syntro humanoid - source: workfar.com
Source
Timeline
- WorkFar and IIT outline wheeled-humanoid control collaboration
2024-08-22 - Partnership - The project adapts the iCub Avatar architecture to a human-controlled wheeled robot in simulation. Planned interfaces combine manipulation commands with voice and visual interaction. Tactile feedback and locomotion controls are intended to make the simulated avatar’s movements more precise and realistic.
Source - WorkFar publicly unveils Syntro for teleoperated industrial work
2024-08-08 - Product Launch - VR goggles show the remote workspace with augmented-reality highlights, while haptic and force-feedback gloves convey object contact. Onboard computer vision, inverse kinematics and physics calculations assist grasp execution after the operator selects a task. WorkFar proposed a monthly service combining the robot, its AI software and a trained remote operator for logistics and manufacturing customers.
Source
Context
Market context
Semi-humanoid industrial robot from WorkFar, using a practical wheeled form and task-focused design to reduce deployment difficulty compared with full bipedal humanoids.
- Target environment: Research labs, industrial pilots, service demonstrations and structured environments where humanoid hardware can be tested or deployed.
- Workflow context: Locomotion, manipulation, human-robot interaction, embodied AI testing and task execution in controlled settings.
- Customer context: Robot developers, research teams, industrial partners and service operators evaluating humanoid systems.
- Deployment model: Prototype or development-stage product with public positioning and limited deployment proof.
- Commercial maturity: Publicly visible but still early, with maturity tied to demos, pilots and later customer evidence.
- Adoption constraints: Adoption depends on safety, useful task coverage, manipulation reliability, operating time, support and proof outside demonstrations.
- Market position: WorkFar positions Syntro in the humanoid lane, where body format, autonomy and task evidence determine differentiation.
- Adjacent products: Figure 03, Apptronik Apollo, Unitree G1, Agility Digit
Comparable Systems
- HMND 01 Alpha Wheeled
Humanoid - Semi Humanoid
- R-noid
Robot.com - Semi Humanoid
- GINO 1
Geek+ - Mobile Manipulator
- FRIDAY
Holiday Robotics - Semi Humanoid
- Cruzr S2
UBTECH Robotics - Semi Humanoid
- X7 Pro
DAX Robotics - Semi Humanoid