
XMAN-R1
About
About XMAN-R1
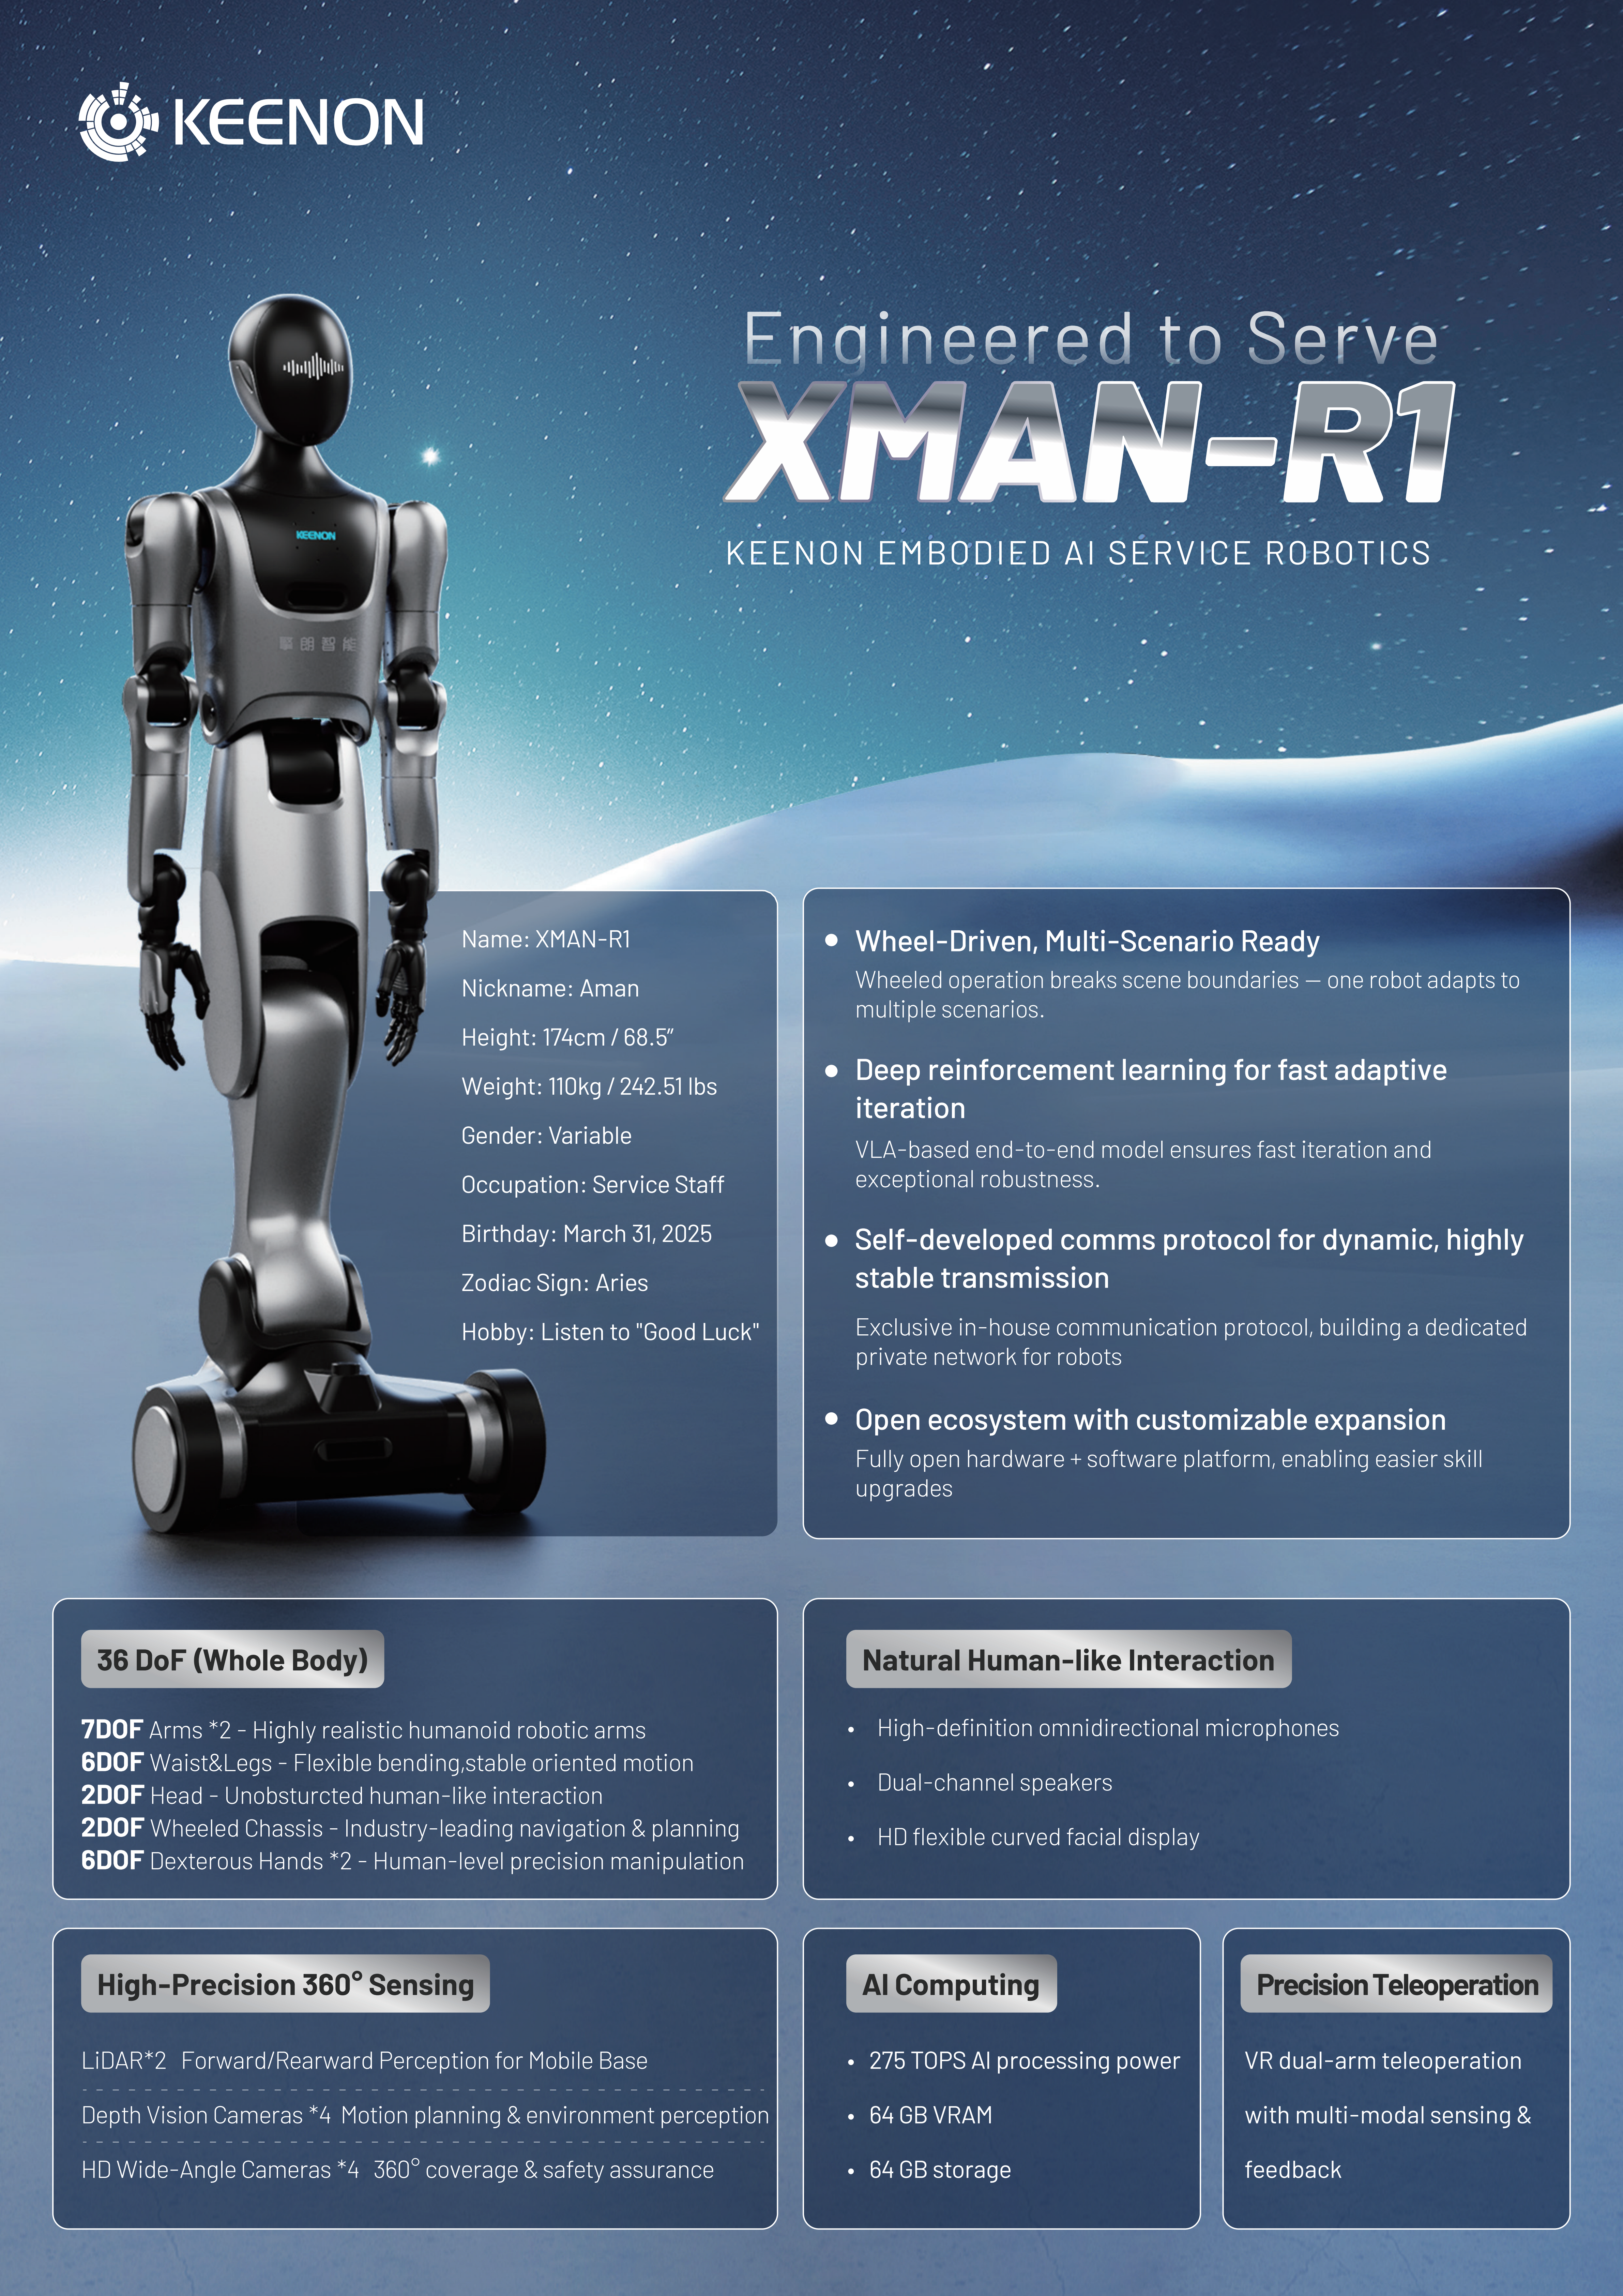
XMAN-R1 uses Keenon’s KOM 2.0 vision-language-action model with domain-specific service training to perform defined commercial roles. Keenon’s ProS layer adapts the robot’s behaviour to settings such as hotels, dividing service work into bounded jobs with clear responsibilities.
At the Shangri-La Traders Hotel at Shanghai Hongqiao Airport, XMAN-R1 began working as a greeter in 2025. It welcomes arriving guests, answers questions and presents welcome gifts. The installation combines this guest-facing role with specialised robots: W3 handles room deliveries, S100 moves luggage, C40 cleans, and T10 and T3 deliver food. The humanoid therefore participates in a coordinated hotel operation with different machines assigned to different jobs.
Capabilities
Source-backed capabilities
- Operating environments: NOWWA coffee booth at LEAP East2026, Hong Kong
- Control modes: Autonomous
- Beverage preparation
Demonstrated - 2026-07-23 - Accept iPad orders, handle cups, extract coffee and deliver the finished drink. - environment: NOWWA coffee booth at LEAP East2026, Hong Kong
Source
Resources
Curated durable documents and official technical references.
- XMAN-R1 wheel-driven humanoid specifications
PNG · XMAN-R1 · KEENON Robotics
Source
Timeline
- KEENON demonstrates autonomous service workflows at LEAP East 2026
2026-07-23 - Demonstration - At a café created with NOWWA Coffee, iPad orders triggered XMAN-R1 to handle cups, extract coffee and deliver it without human intervention. A claw-machine demonstration required the humanoid to recognize a target prize, grasp it and complete the visitor interaction. KEENON used its KOM 2.0 VLA and ProS role model for the humanoid service tasks, alongside separate T10 delivery and C40 cleaning demonstrations.
Source - KEENON introduces XMAN-R1 and three KLEENBOT cleaning robots
2025-03-31 - Product Launch - XMAN-R1 was designed to interact with people and coordinate with DINERBOT T10, KLEENBOT C30 and S100 robots. The C40 combines a 40 cm scrubbing and vacuuming width with a 65 cm minimum pass-through width for smaller commercial spaces. The C55 has a 55 cm cleaning width for large spaces, while the C20 uses a 35 cm body for compact areas.
Source
Context
Market context
XMAN-R1 is Keenon Robotics' humanoid-style service robot concept for extending its indoor service robotics line.
- Target environment: Hospitality, service demonstrations, indoor venues and structured environments where Keenon already sells service robots.
- Workflow context: Human-robot interaction, service presentation, indoor mobility, assistance workflows and humanoid service experimentation.
- Customer context: Hospitality operators, partners and developers evaluating Keenon's move beyond tray delivery robots.
- Deployment model: Development-stage humanoid service platform within Keenon's broader service-robot portfolio.
- Commercial maturity: Development-stage product with limited specifications and no broad deployment evidence.
- Adoption constraints: Adoption depends on task usefulness, safety, manipulation capability, navigation, support and differentiation from existing service robots.
- Market position: Service-robot OEM exploring humanoid form from an existing commercial indoor-robot base.
- Adjacent products: DINERBOT T11, Pudu D9, LG CLOiD, CloudMinds XR-1
Comparable Systems
- YMBot H
Yunmu Intelligent Manufacturing - Semi Humanoid
- W1 Pro
DexForce - Semi Humanoid
- DUCO BR-MR73A Wheeled Humanoid Robot
SIASUN Robot & Automation Co., Ltd. - Semi Humanoid
- FlashBot Arm
Pudu Robotics - Semi Humanoid
- Nyokkey
Kawasaki Robotics - Semi Humanoid
- Moz2
Spirit AI - Semi Humanoid
Related Systems
- Gento Luna
Tianji Intelligent - Semi Humanoid
- Tianyi 2.0
X-Humanoid - Semi Humanoid
- ARMAR-7
KIT H²T - Semi Humanoid
- R1-A5-D
Unitree - Semi Humanoid
- R1-A7-D
Unitree - Semi Humanoid
- ψ-SynRobot
PsiBot - Semi Humanoid