
H2 Plus
About
About H2 Plus
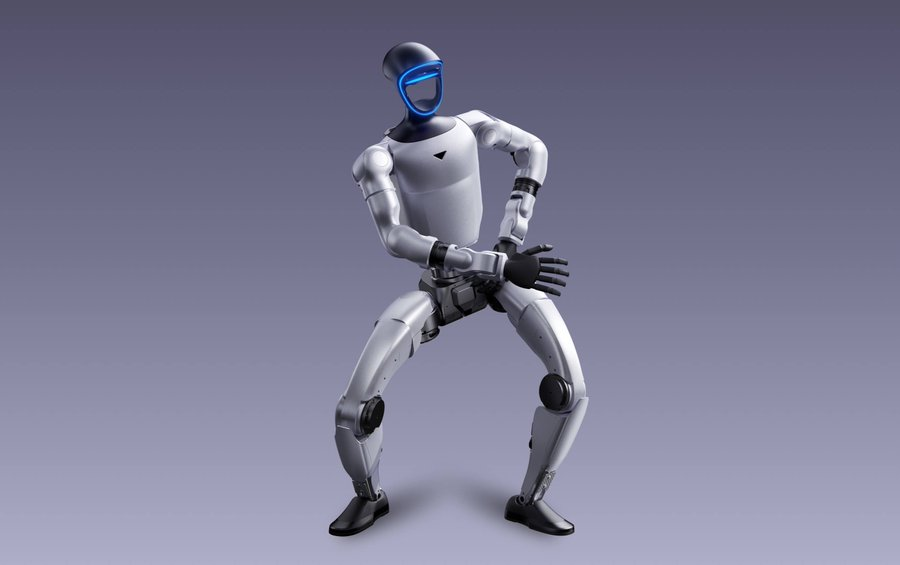
H2 Plus is Unitree's bipedal humanoid research platform built around the H2 robot, NVIDIA Jetson Thor computing and the Isaac GR00T development environment. It gives robotics teams a platform for collecting demonstrations, building simulations, training policies and running inference on the robot. Unitree announced availability for late 2026.
The body has 31 motorised joints. The reference configuration combines it with two Sharpa Wave tactile hands, bringing the total to 75 degrees of freedom; the current product configuration lists these hands and wrist cameras as options. A head stereo camera and onboard computing support perception and control. Isaac TeleOp, Isaac Sim, Isaac Lab and Isaac ROS connect data capture, training and robot execution. The battery is rated for approximately three hours, with actual endurance depending on operation.



Capabilities
Source-backed capabilities
- Control modes: Teleoperation
- Multimodal data collection
Claimed - Capture robot demonstrations for training and policy development through Isaac TeleOp.
Source
Observed use
Exact-product configurations are shown without inferring supply, purchase, customer status, standard fit, deployment or partnership.
- Sharpa Wave
2026-06-01 - Reference Design - Mounted - Physical - H2 Plus was announced in a reference configuration with two Sharpa Wave tactile hands. Unitree's current product table lists the hands as optional.
Source
Research
- Unitree robot descriptions and simulation packages
Research Publication - Unitree's shared robot-description and simulation repository publishes robot models, meshes and ROS control packages for multiple platforms.
Source
Timeline
- Unitree announces H2 Plus research reference humanoid
2026-06-01 - Product Launch - The configuration pairs an H2 chassis with dual Sharpa Wave five-finger hands and NVIDIA Jetson AGX Thor T5000 onboard computing. Unitree targeted late-2026 availability; the platform covers demonstration capture, simulation, policy training, evaluation and deployment workflows.
Source
Context
Comparable Systems
- Asimov 1
Menlo Research - Humanoid Robot
- KUAVO 4Pro
Leju Robotics - humanoid robotics
- AI Sapiens K1
ROBOTIS - humanoid robotics
- Domo
Rotaku - humanoid robotics
- Walker Tienkung
UBTECH Robotics - humanoid robotics
- ALICE 5
AeiROBOT - humanoid robotics