
Calvin-40
About
About Calvin-40
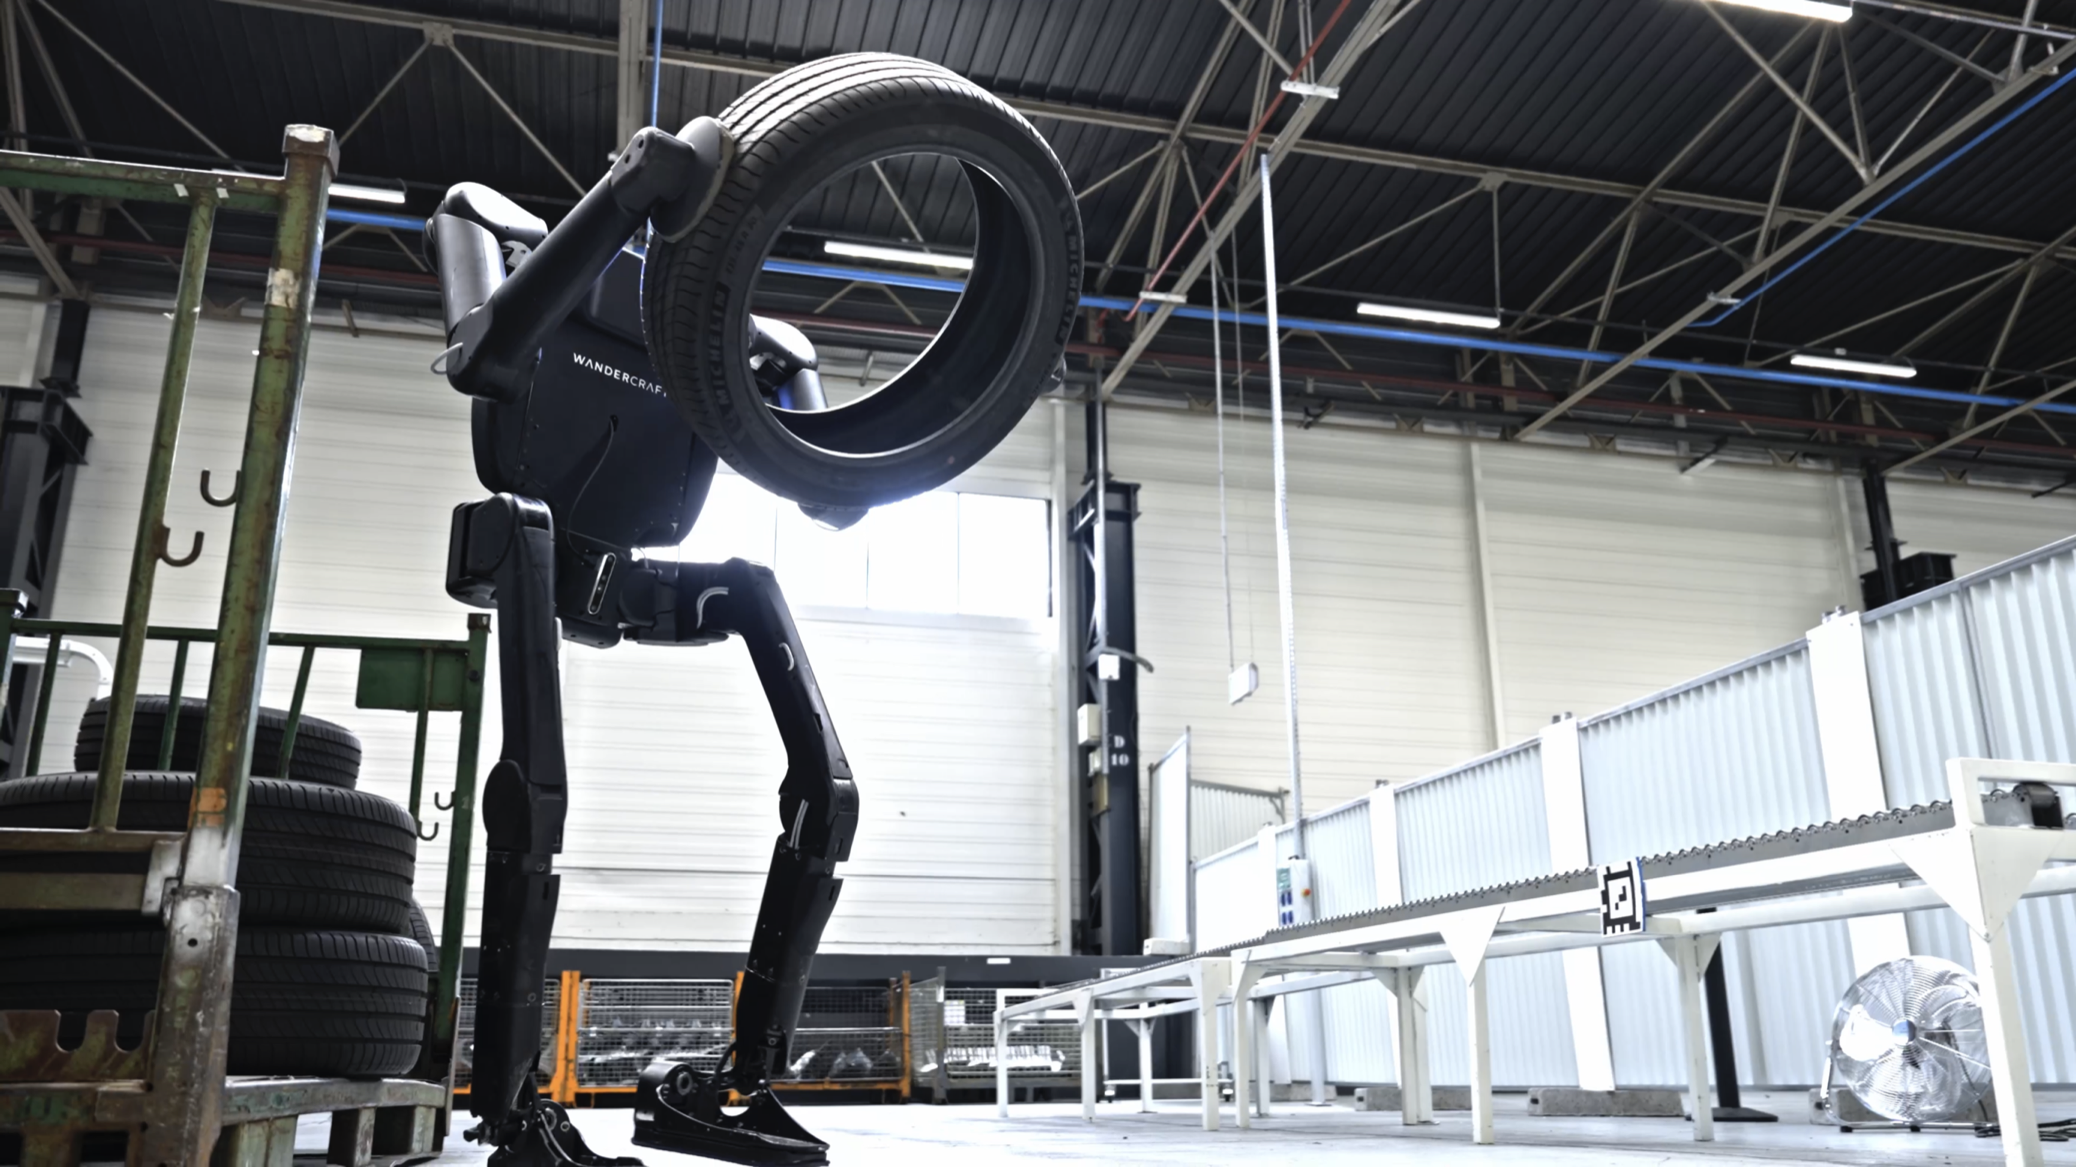
Calvin-40 is Wandercraft's bipedal robot for heavy handling and repetitive industrial work. High-torque actuation and whole-body control adapt its balance to carried loads, while three-dimensional sensing and vision support movement around existing facilities. Its safety architecture is designed for operation alongside people, with certification and site integration forming part of industrialisation.
Wandercraft has demonstrated repetitive workflows and is developing more precise picking and kitting tasks. Intended applications include moving boxes and crates, supporting material flow between workstations and handling parts in factories or logistics sites. Customers can arrange demonstrations and proof-of-concept testing around their own workflows. First series deliveries are expected in the first half of 2027; present demonstrations and development projects precede that production milestone.

Capabilities
Source-backed capabilities
- Operating environments: Renault Douai factory
- Tire handling
Pilot - 2026-06-26 - Grasp pairs of tyres during the Renault Douai factory trial. - environment: Renault Douai factory
Source
Resources
Media library
- Calvin-40 factory view
image · Wandercraft
Source
Timeline
- Wandercraft secures 12 Calvin-40 customers
2026-09-04 - Market Signal - Initial development targets handling boxes, parcels, tyres, panels and carts across industrial and logistics workflows. Finer picking and sorting functions were being developed and tested as extensions to larger-object handling. The production programme draws on Renault Group’s manufacturing, procurement and design-to-cost expertise.
Source - Wandercraft Calvin-40 trials tyre handling at Renault Douai
2026-03-12 - Deployment - Renault planned to add another 350 humanoids over the following 18 months. Calvin-40 was described as the second iteration, with AI training doubling its speed over six months. The programme followed Renault’s strategic partnership and minority investment in Wandercraft.
Source - SAPA and Wandercraft agree Calvin-40 manufacturing partnership
2025-11-12 - Partnership - The first implementation phase targets precise, repetitive movement of large and heavy parts. The companies will co-develop applications around high-throughput manufacturing workflows before scaling across tasks and locations. The agreement extends Wandercraft’s industrial programme from its Renault Group OEM partnership to an Italian Tier 1 automotive supplier.
Source
Context
Market context
Calvin-40 is Wandercraft industrial humanoid adapted from self-balancing exoskeleton technology for carrying and handling work on factory floors.
- Target environment: Factory floors and industrial workplaces.
- Workflow context: Heavy carrying, material handling and physical work on factory floors using a self-balancing humanoid platform.
- Customer context: Industrial manufacturers deploying humanoid platforms for physical material handling.
- Deployment model: Commercial industrial humanoid from a company with exoskeleton balance-control heritage.
- Commercial maturity: Actively positioned industrial humanoid with real balance-control heritage and automotive deployment pathway through Renault.
- Adoption constraints: Humanoid deployment in factories is still early. Balance-control heritage provides a differentiation advantage.
- Market position: Benefits from real balance-control heritage and a direct automotive route through Renault.
- Adjacent products: Apollo, Digit, industrial humanoids
Comparable Systems
- 4NE1 Gen 4
Neura Robotics - humanoid robotics
- Atlas
Boston Dynamics - humanoid robotics
- IRON
XPeng Inc. - humanoid robotics
- Kepler K2
Kepler Robotics - humanoid robotics
- T800
ENGINEAI - humanoid robotics
- L7
RobotEra - humanoid robotics