
UR10e
About
About UR10e
UR10e combines six powered joints with integrated force and torque sensing to carry tooling through a 1.3-metre working radius. Its reach allows one installation to serve multiple machines, pallet positions or conveyor points, while the wrist payload supports larger grippers, workpieces and process tools. Configurable safety limits govern joint speed, force, momentum and workspace boundaries for collaborative or guarded deployment.
The arm is programmed through PolyScope and connects to end effectors, vision systems and factory equipment through I/O, fieldbus interfaces and partner URCaps. Universal Robots supplies the platform through certified distributors and integrators, with application packages available for palletising, welding, machine tending and packaging. The UR10e remains an established production cobot used across general manufacturing and logistics.

Capabilities
Source-backed capabilities
- Machine tending
Claimed - Universal Robots lists UR10e for machine tending, palletizing, packaging and material-handling applications.
Source - Palletizing
Claimed - Universal Robots lists UR10e for machine tending, palletizing, packaging and material-handling applications.
Source - Packaging
Claimed - Universal Robots lists UR10e for machine tending, palletizing, packaging and material-handling applications.
Source - Material handling
Claimed - Universal Robots lists UR10e for machine tending, palletizing, packaging and material-handling applications.
Source
Observed use
Exact-product configurations are shown without inferring supply, purchase, customer status, standard fit, deployment or partnership.
- Shadow Teleoperation System
Physical Demo - Mounted - Physical - Shadow Robot’s teleoperation system physically mounts its dexterous hands on Universal Robots UR10e arms.
Source - Ket-Met machine-tending cell configuration
Operational - Mounted - Physical - Ket-Met machine-tending cell uses UR10e in the configuration documented by Universal Robots.
Source - Pentik production cell configuration
Operational - Mounted - Physical - Pentik production cell uses UR10e in the configuration documented by Universal Robots.
Source - RCM Industries dual-spindle CNC cell configuration
Operational - Mounted - Physical - RCM Industries dual-spindle CNC cell uses UR10e in the configuration documented by Universal Robots.
Source - SEAT Componentes quality-control cells configuration
Operational - Mounted - Physical - SEAT Componentes quality-control cells uses UR10e in the configuration documented by Universal Robots.
Source - Danish Crown processing line configuration
Operational - Mounted - Physical - Danish Crown processing line uses UR10e in the configuration documented by Universal Robots.
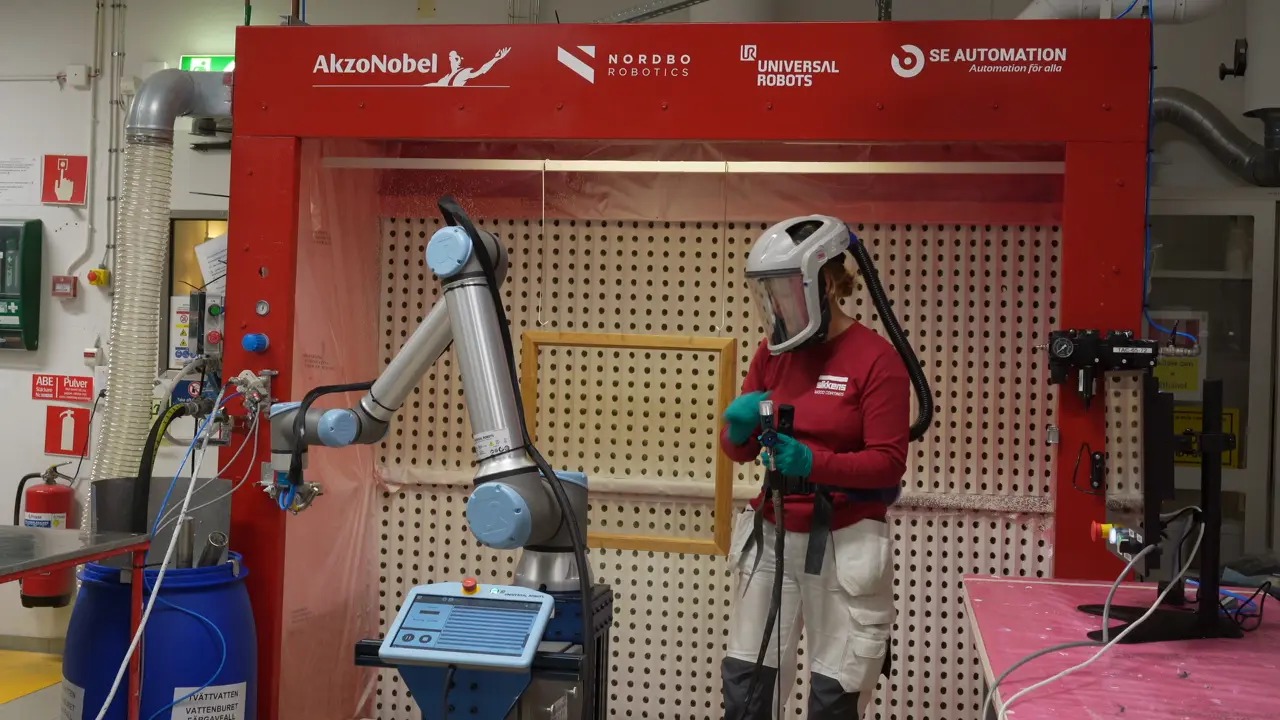
Source - Brandt painting cell configuration
Operational - Mounted - Physical - Brandt painting cell uses UR10e in the configuration documented by Universal Robots.
Source - EVCO Plastics manufacturing cells configuration
Operational - Mounted - Physical - EVCO Plastics manufacturing cells uses UR10e in the configuration documented by Universal Robots.
Source - Siemens GWE manufacturing cell configuration
Operational - Mounted - Physical - Siemens GWE manufacturing cell uses UR10e in the configuration documented by Universal Robots.
Source - Osaka Nursery operating configuration
Operational - Mounted - Physical - Osaka Nursery used Universal Robots UR10e in an operating configuration documented by Universal Robots.
Source - New England Union Company operating configuration
Operational - Mounted - Physical - New England Union Company used Universal Robots UR10e in an operating configuration documented by Universal Robots.
Source - DeAngelo Marine Exhaust operating configuration
Operational - Mounted - Physical - DeAngelo Marine Exhaust used Universal Robots UR10e in an operating configuration documented by Universal Robots.
Source - HAILO operating configuration
Operational - Mounted - Physical - HAILO used Universal Robots UR10e in an operating configuration documented by Universal Robots.
Source - Endutec operating configuration
Operational - Mounted - Physical - Endutec used Universal Robots UR10e in an operating configuration documented by Universal Robots.
Source - DCL Logistics operating configuration
Operational - Mounted - Physical - DCL Logistics used Universal Robots UR10e in an operating configuration documented by Universal Robots.
Source - Carriere Industrial Supply operating configuration
Operational - Mounted - Physical - Carriere Industrial Supply used Universal Robots UR10e in an operating configuration documented by Universal Robots.
Source - Bernacki Industrial Services operating configuration
Operational - Mounted - Physical - Bernacki Industrial Services used Universal Robots UR10e in an operating configuration documented by Universal Robots.
Source - Allied Moulded Products operating configuration
Operational - Mounted - Physical - Allied Moulded Products used Universal Robots UR10e in an operating configuration documented by Universal Robots.
Source - Aido Industry operating configuration
Operational - Mounted - Physical - Aido Industry used Universal Robots UR10e in an operating configuration documented by Universal Robots.
Source - Napco Brands operating configuration
Operational - Mounted - Physical - Napco Brands used Universal Robots UR10e in an operating configuration documented by Universal Robots.
Source - Hofmann Glastechnik operating configuration
Operational - Mounted - Physical - Hofmann Glastechnik used Universal Robots UR10e in an operating configuration documented by Universal Robots.
Source - MT Solar operating configuration
Operational - Mounted - Physical - MT Solar used Universal Robots UR10e in an operating configuration documented by Universal Robots.
Source - Zantech operating configuration
Operational - Mounted - Physical - Zantech used Universal Robots UR10e in an operating configuration documented by Universal Robots.
Source - Vattholma Mekano operating configuration
Operational - Mounted - Physical - Vattholma Mekano used Universal Robots UR10e in an operating configuration documented by Universal Robots.
Source - Temar operating configuration
Operational - Mounted - Physical - Temar used Universal Robots UR10e in an operating configuration documented by Universal Robots.
Source - Siouxland Fabricating operating configuration
Operational - Mounted - Physical - Siouxland Fabricating used Universal Robots UR10e in an operating configuration documented by Universal Robots.
Source - Seng Heng Engineering operating configuration
Operational - Mounted - Physical - Seng Heng Engineering used Universal Robots UR10e in an operating configuration documented by Universal Robots.
Source - Raymath operating configuration
Operational - Mounted - Physical - Raymath used Universal Robots UR10e in an operating configuration documented by Universal Robots.
Source - PMI operating configuration
Operational - Mounted - Physical - PMI used Universal Robots UR10e in an operating configuration documented by Universal Robots.
Source - Toyota Industries configuration
Operational - Mounted - Physical - Toyota Industries Tochita engine plant uses a UR10e for raw-material input.
Source - STIVAL configuration
Operational - Mounted - Physical - TD Conception integrated a UR10e sheet-metal chamfering cell at STIVAL.
Source - Trametal configuration
Operational - Mounted - Physical - GAPE integrated a UR10e welding cell for small and medium production runs at Trametal.
Source - KSB Sequedin configuration
Operational - Mounted - Physical - JL Corp integrated a UR10e for water-pump impeller balancing at KSB.
Source - USIMINAS configuration
Operational - Mounted - Physical - USIMINAS uses a UR10e, now marketed as UR12e, for steel-coil marking.
Source - Verus Digital GmbH configuration
Operational - Mounted - Physical - Verus Digital CultArm3D uses a UR10e for automated cultural-object digitisation.
Source
Research
- Embodied Playground: A Long-Horizon Agentic Robotics Benchmark for Physical, Strategic, and Spatial Reasoning
2026-10-19 - Research Publication - Embodied Playground tests long-horizon robotic reasoning across 410 simulated task environments. Its EP-100 subset contains 100 tasks in five suites and 16 task types, with separate goal, rule-compliance and physical-validity checks. The research team includes Sharpa and university affiliations.
Source
Resources
Media library
- UR10e dual-spindle machine tending
image · Universal Robots
Source - UR10e machine-tending system at WST Fab
image · Universal Robots
Source - UR10e order-fulfilment deployment
image · Universal Robots
Source
Official UR10e technical references and exact deployment photography from Universal Robots case studies.
- Universal Robots UR10e technical datasheet
PDF · UR10e technical specification · Universal Robots
Source - UR10e PolyScope 5 user manual
PDF · UR10e, PolyScope 5.25.1 · Universal Robots
Source - UR10e online hardware and safety manual
WEB · UR10e hardware and safety · Universal Robots
Source - UR10e current technical specifications
WEB · UR10e technical specification, PolyScope X 10.12.1 · Universal Robots
Source