
Sharpa
About
About Sharpa
Sharpa develops dexterous manipulation hardware and embodied-AI software. Its portfolio includes the tactile Wave hand, the North humanoid platform and CraftNet vision-touch-language-action models intended to connect perception, contact sensing and robot control.
The company targets robot manufacturers, researchers and industrial developers that need integrated hands, whole-body platforms or manipulation models. Wave provides a component route while North serves as a system-level development platform. Public demonstrations indicate multi-step task capability, but they do not establish reliability or deployment scale across unstructured environments.
Articles


Products
Operations
Facilities & manufacturing
- Production setup
2026-01-06 - Sharpa said its SharpaWave human-sized dexterous robotic hand entered mass production, moving the component from prototype status into scalable production. - SharpaWave robotic hand
Source - Production setup
2025-12-19 - Third-party coverage reported Sharpa’s advanced robotic hand entering mass production, moving the dexterous-hand product from prototype toward scaled hardware availability. - Sharpa Wave robotic hand
Source
Operating use
- Customer site
2026-08-29 - One Sharpa dual-arm robot entered live customer service at DQ's Shanghai Wujiang Road store, completing the 55-step Blizzard workflow on the existing restaurant equipment in about six minutes per order. - DQ Blizzard service at Shanghai Wujiang Road store - DQ Shanghai Wujiang Road store
Source
Observed use
- Sharpa Wave with MANUS gloves
2026-08-18 - Research Experiment - Controlled By - Pre-training Visual Dexterity used MANUS gloves and Quest tracking to teleoperate two YAM Pro arms fitted with Sharpa Wave hands, with three RealSense D405 cameras.
Source - Sharpa Wave with dual UR7e arms, Quest 3 and DexTeleop-0
2026-07-14 - Research Experiment - Controlled By - DexTeleop-0 used dual UR7e arms and Sharpa Wave hands with Quest 3 tracking and an Isaac Sim digital twin for force-aware bimanual teleoperation.
Source - Sharpa Wave with Franka arm and Heterogeneous Tactile Transformer
2026-07-14 - Research Experiment - Tested With - A Sharpa Wave hand on a Franka arm ran camera-free HTT tactile experiments, reaching 95% toy-screw tightening success.
Source - Sharpa Wave with FTP-1 tactile foundation policy
2026-07-03 - Research Experiment - Trained With - FTP-1 used Sharpa Wave tactile data in pretraining and evaluated long-horizon tasks on a Sharpa North platform with dual Wave hands.
Source - Sharpa Wave with dual UR3e arms and Do as I Do pipeline
2026-07-03 - Research Experiment - Controlled By - Do as I Do retargeted internet video to dual UR3e arms with Sharpa Wave hands and executed ten real-world motions.
Source - Sharpa Wave with MANUS gloves
2026-06-18 - Research Experiment - Controlled By - T-Rex research used two Dexmate Vega-1 arms, Sharpa Wave hands, multi-view cameras, MANUS gloves and VIVE trackers to collect a 100-hour tactile dataset across 12 tasks.
Source - Sharpa Wave with Dexmate Vega bimanual platform and CAIP
2026-06-15 - Research Experiment - Tested With - CAIP was evaluated on a Dexmate Vega bimanual platform with dual Sharpa Wave hands, reporting 76% average success across six tasks.
Source - Sharpa Wave with H2 Plus
2026-06-01 - Reference Design - Mounted - H2 Plus was announced in a reference configuration with two Sharpa Wave tactile hands. Unitree's current product table lists the hands as optional.
Source - Sharpa Wave with IMCopilot and MoDE-VLA
2026-03-09 - Research Experiment - Tested With - A Sharpa Wave configuration tested IMCopilot and MoDE-VLA on apple peeling, gear, charger and tube manipulation tasks.
Source - Sharpa Wave with Isaac Lab
2026-03-09 - Digital Simulation - Connected - A MANUS demonstration teleoperated a simulated 22-DoF Sharpa Wave inside NVIDIA Isaac Lab 2.3 and fed demonstrations into Isaac Lab Mimic.
Source - Sharpa Wave with DexEMG and EMG2Pose retargeting
2026-03-06 - Research Experiment - Controlled By - DexEMG used EMG2Pose retargeting to control Sharpa Wave on unfamiliar-object and longer-horizon manipulation tasks.
Source - Sharpa Wave with MANUS gloves
2026-03-04 - Research Experiment - Trained With - NVIDIA EgoScale used a Sharpa hand action space and MANUS/Vive capture for aligned human–robot data, with transfer tests on a Unitree G1 tri-finger hand.
Source - Sharpa Wave with Tacmap tactile simulator
2026-02-19 - Research Experiment - Trained With - Tacmap policies trained in tactile simulation transferred to physical Sharpa Wave hardware without real-world fine-tuning.
Source - Sharpa Wave with KUKA arm and SimToolReal
2026-02-18 - Research Experiment - Tested With - SimToolReal used a KUKA arm with Sharpa Wave and 120 real rollouts for zero-shot dexterous tool manipulation.
Source - Sharpa Wave with Astribot S1
Digital Simulation - Mounted - BiDex-100 uses a simulated Astribot S1 embodiment with Sharpa Wave hands for ten generalisation tasks.
Source - Sharpa Wave with Franka Research 3
Digital Simulation - Mounted - BiDex-100 simulates two Franka Research3 arms with22DoF Sharpa Wave hands for96tasks.
Source - Sharpa Wave with Vega 1 Pro
Research Experiment - Mounted - FTP-1 evaluates Dexmate Vega with two mounted Sharpa Wave tactile hands in a contact-rich manipulation research configuration.
Source - Sharpa Wave with DITTO-X actuated exoskeleton
Research Experiment - Controlled By - Sharpa Wave is physically used for battery insertion, tong use and raspberry placement. DITTO-X supplies forward force-feedback teleoperation and reverse hand-pose matching before human intervention.
Source - Sharpa Wave with UFACTORY xArm 7
Research Experiment - Mounted - FINGR used a Sharpa Wave hand mounted on an xArm7 for autonomous 2×2 cube turns and solves, with marker tracking and table-assisted regrasping.
Source - Sharpa Wave with Unitree H2 Plus in NVIDIA Isaac GR00T Reference Humanoid Robot
Reference Design - Mounted - NVIDIA's Isaac GR00T reference design combines a Unitree H2 Plus body with dual Sharpa Wave hands and Jetson AGX Thor T5000 compute.
Source
Supply
Supply chain relationships
- Hesai Technology
Inbound - Perception - Hesai supplies two FTX solid-state lidars for Sharpa D01, mounted at the front and rear
Source - Hesai Technology
Inbound - actuation and motion control - Hesai supplies robotic actuation modules for Sharpa D01
Source - Hesai Technology
Inbound - actuation and motion control - Hesai supplies robotic actuation modules for Sharpa W02
Source - Hesai Technology
Inbound - actuation and motion control - Hesai actuation modules are installed in Sharpa Wave robotic hands
Source - NVIDIA
Inbound - Compute & Control - NVIDIA supplies Jetson Thor compute for the Sharpa D01 dexterous robot
Source - Hesai Technology
Inbound - Manufacturing Services - Hesai's framework proposes actuator integration manufacturing and support for Sharpa; individual contracts remain required
Source - Unitree
Outbound - End Effectors - Unitree H2 Plus offers dual SharpaWave tactile five-finger dexterous hands as an option
Source
Funding
- 2026-08-28 - Cumulative financing history disclosure - Sharpa discloses RMB4.5B+ cumulative financing and RMB22B valuation
valuation: CNY 22B (~$3.27B) - Sharpa disclosed for the first time that it had raised more than RMB4.5 billion cumulatively and reached an RMB22 billion post-money valuation. - source: m.x-techcon.com
- 2026-04-24 - Strategic equity investment - ~$13.9M - Hesai filing discloses April 2025 CNY100M investment in Sharpa
Hesai disclosed that it invested approximately CNY100 million, or US$13.9 million, for about 10% of Sharpa in April 2025; the filing did not provide the exact transaction day. - source: sec.gov
Investors
- Alibaba Group - Participant - Corporate / CVC - 1 funding event - strategic/corporate - first seen 2026-08-28
- Guanghe Venture Capital - Participant - VC - 1 funding event - first seen 2026-08-28
- Hesai Technology - Participant - Angel / Individual - 1 funding event - first seen 2026-04-24
- JD.com - Participant - Unknown - 1 funding event - first seen 2026-08-28
- Meituan - Participant - Corporate / CVC - 1 funding event - strategic/corporate - first seen 2026-08-28
- Meituan DragonBall - Participant - Corporate / CVC - 1 funding event - strategic/corporate - first seen 2026-08-28
- Qiming Venture Partners - Participant - VC - 1 funding event - first seen 2026-08-28
- Sequoia China - Participant - Angel / Individual - 1 funding event - first seen 2026-08-28
- Tencent - Participant - Unknown - 1 funding event - first seen 2026-08-28
- Transsion Holdings - Participant - Angel / Individual - 1 funding event - first seen 2026-08-28
Team
- Shaoqing Xiang - Co-Founder - Co-founded Sharpa as it developed dexterous robot hardware and the CraftNet vision-tactile-language-action model.
- Alicia Veneziani - VP of GTM and President of Europe - Leads Sharpa's go-to-market work and European operations, including engagement with partners in the physical AI ecosystem.
Research
- Sharpa coauthors Embodied Playground long-horizon robotics benchmark
2026-10-19 - Research Publication - The suites cover launching, Tower of Hanoi, interlocking assembly, cube manipulation and household tasks. EP-Easy and EP-Hard each contain 50 tasks; EP-20 provides a compact diagnostic subset. The released environment SDK supports MuJoCo, Isaac Lab and ManiSkill with declared observation/tool-access levels.
Source - Sharpa's robot autonomously peels apple using dual dexterous hands
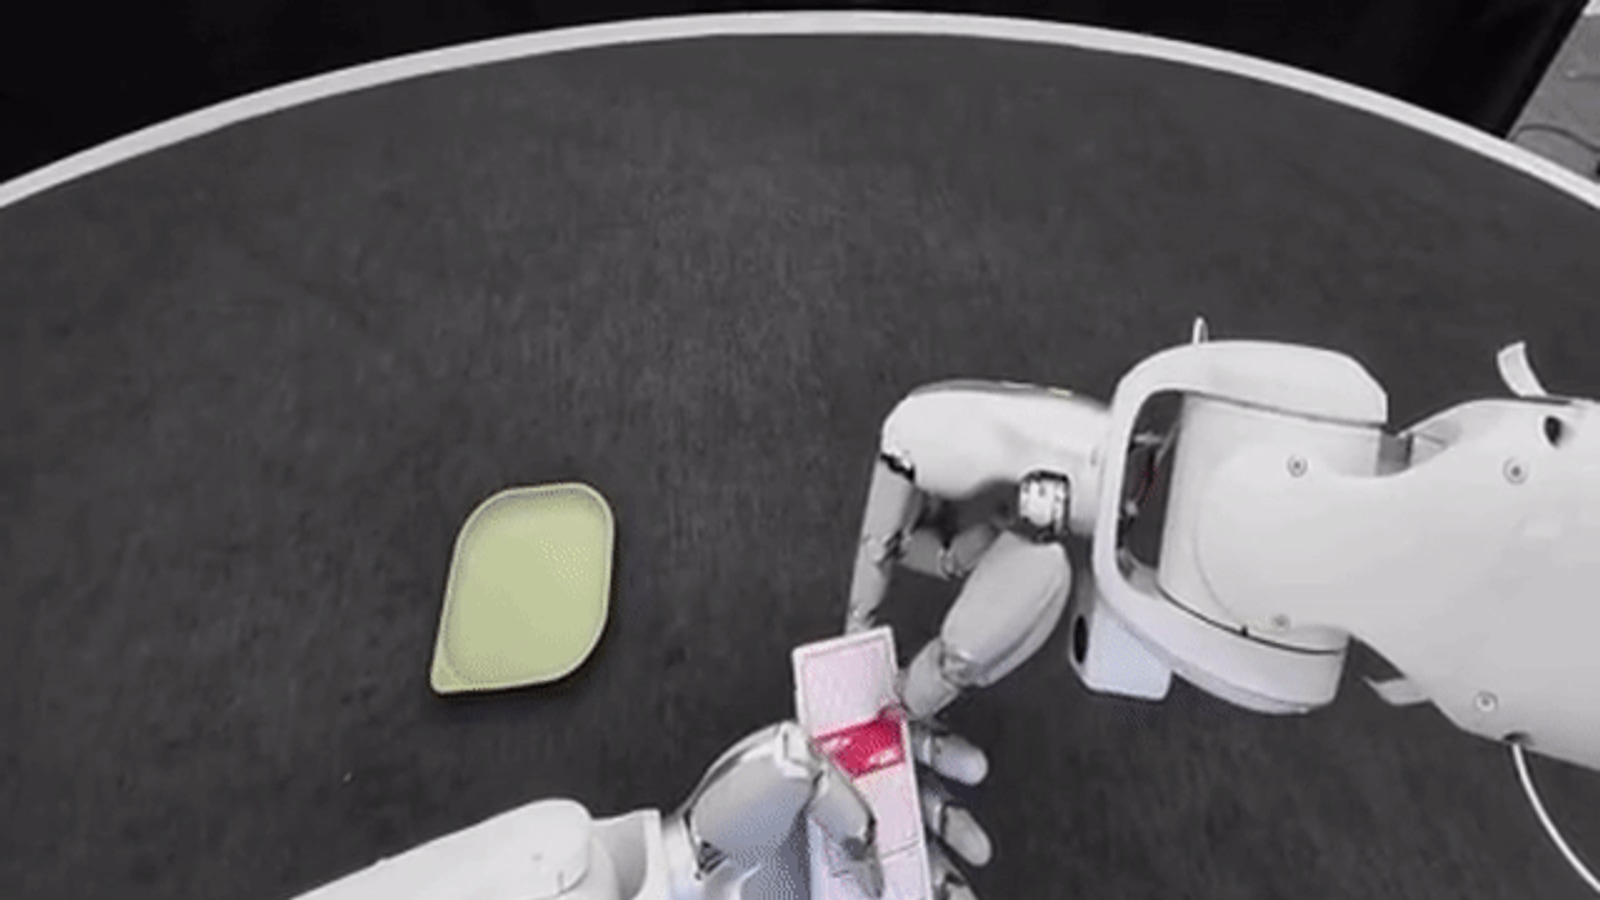
2026-03-11 - Research Publication - • At CES 2026 in Las Vegas, Sharpa's newly debuted full-body robot, North, played fully autonomous ping-pong rallies with human opponents and ran live demonstrations for four straight days, eight hours a day. • The robot utilized Sharpa's dexterous robotic hand, Wave, featuring 22 active degrees of freedom and a proprietary dynamic tactile array, entering mass production in October 2025. • North completed four fully autonomous demonstrations at CES: robot photography, ping-pong rallying, windmill assembly, and card dealing, showcasing advanced fine manipulation capabilities powered by Wave.
Source
Timeline
Events
- 2026-10-19 - Research Publication - Sharpa coauthors Embodied Playground long-horizon robotics benchmark
The suites cover launching, Tower of Hanoi, interlocking assembly, cube manipulation and household tasks. EP-Easy and EP-Hard each contain 50 tasks; EP-20 provides a compact diagnostic subset. The released environment SDK supports MuJoCo, Isaac Lab and ManiSkill with declared observation/tool-access levels.
Source - 2026-10-12 - Market Signal - Sharpa outlines 30,000-robot commercial deployment target
The company intends to let operators collect small amounts of task data to adapt robots to their businesses. The approach emphasizes working in existing environments and sustaining continuous operation. Xiang described human demonstrations, simulation and real-robot interactions as complementary training data.
Source - 2026-09-28 - Product Launch - Sharpa launches D01, W02 and AE01 tactile-manipulation platform products
D01 combines body electronic skin with arm-end speed above 10.5 m/s and 0.2 mm repeat positioning accuracy. W02 integrates 21 active degrees of freedom, visual fingertip tactile sensing and electronic skin across the rest of the hand. AE01 uses 22 encoders to capture hand motion and provides 256 levels of continuous haptic feedback per fingertip.
Source - 2026-08-29 - Deployment - Sharpa robot begins live DQ Blizzard service in Shanghai
The robot handles cup retrieval, ingredient dispensing, mixing and inverted handoff without continuous teleoperation, using vision, touch and force feedback to correct errors. The disclosed cycle time is about six minutes per Blizzard, compared with roughly two to three minutes for a human worker. The installation operates alongside the human service counter during the store's daily 10:00-22:00 opening hours.
Source - 2026-08-28 - Funding - Sharpa discloses RMB4.5B+ cumulative financing and RMB22B valuation
Named investors include Alibaba, Meituan, Tencent, JD.com, Transsion, Sequoia China, Qiming Venture Partners, Meituan DragonBall and Guanghe Venture Capital. The disclosure covers cumulative financing rather than one current round, and no individual-round amounts were reported. Sharpa was founded in late 2024 by Hesai co-founders Yifan Li, Shaoqing Xiang and Kai Sun.
Source - 2026-08-19 - Product Launch - Sharpa launches Wave SE dexterous hand and opens pre-orders
Wave SE retains 22 independently actuated degrees of freedom in a human-scale hand intended for embodied-AI research and robot integration. The SE configuration is rated for a 24 kg payload, 90 N grip force, 12 N fingertip force and operation at 2 Hz. Its tactile configuration provides a 60 × 60 array, 0.05 N force sensitivity, 2 mm spatial resolution and onboard inference at up to 30 frames per second.
Source - 2026-08-18 - Demonstration - Visual Dexterity study combines YAM Pro arms and Sharpa Wave hands
MANUS gloves and Quest tracking teleoperated two YAM Pro arms fitted with Sharpa Wave hands. Three RealSense D405 cameras captured the real-world manipulation workspace.
Source - 2026-08-18 - Market Signal - Hesai discloses new humanoid lidar orders and actuation shipments
New robotics-lidar orders and JT128 adoption include Unitree, Robbyant, Galbot, Galaxea and Dexmal. After Kosmo prototype deliveries in July 2026, orders were secured from humanoid-robot companies including Galbot, with initial revenue expected in Q3. The robotic-actuation production line is operational, dexterous-hand module shipments are underway and Sharpa is an actuation-module customer.
Source - 2026-06-01 - Product Launch - Unitree announces H2 Plus research reference humanoid
The configuration pairs an H2 chassis with dual Sharpa Wave five-finger hands and NVIDIA Jetson AGX Thor T5000 onboard computing. Unitree targeted late-2026 availability; the platform covers demonstration capture, simulation, policy training, evaluation and deployment workflows.
Source - 2026-05-31 - Partnership - Sharpa Wave tactile hands join NVIDIA Isaac GR00T humanoid reference design
NVIDIA announced the Isaac GR00T Reference Humanoid Robot using a Unitree H2 Plus body, Sharpa Wave tactile five-finger hands, Jetson Thor onboard compute, and Isaac GR00T software workflows. Sharpa Wave supplies dexterous tactile manipulation hardware for academic humanoid robotics research and physical-AI development. The reference design gives Sharpa a high-visibility integration point in the humanoid research ecosystem.
Source - 2026-04-24 - Funding - Hesai filing discloses April 2025 CNY100M investment in Sharpa
Hesai made the investment indirectly through a partnership and recorded it as an equity security without a readily determinable fair value. Hesai sold its entire Sharpa stake to two independent third-party investors in August 2025 for RMB275.6 million, or US$38.4 million. A separate May 2025 agreement transferred RMB37 million of Hesai-developed know-how to Sharpa, with completion in August 2025.
Source - 2026-03-25 - Partnership - Hesai and Sharpa sign 2026 lidar and actuator supply framework
The agreement covers Hesai LiDAR products and robotic actuators supplied to Sharpa from 25 March through 31 December 2026. Actuator support may include ancillary-material procurement, manufacturing and assembly, testing, packaging and delivery for integration into dexterous hands and other embodied products. The framework is not itself a purchase order: individual transactions require separate definitive contracts and the disclosed annual cap is RMB100 million.
Source - 2026-03-11 - Research Publication - Sharpa's robot autonomously peels apple using dual dexterous hands
• At CES 2026 in Las Vegas, Sharpa's newly debuted full-body robot, North, played fully autonomous ping-pong rallies with human opponents and ran live demonstrations for four straight days, eight hours a day. • The robot utilized Sharpa's dexterous robotic hand, Wave, featuring 22 active degrees of freedom and a proprietary dynamic tactile array, entering mass production in October 2025. • North completed four fully autonomous demonstrations at CES: robot photography, ping-pong rallying, windmill assembly, and card dealing, showcasing advanced fine manipulation capabilities powered by Wave.
Source - 2026-03-09 - Demonstration - A MANUS demonstration teleoperated a simulated 22-DoF Sharpa Wave inside NVIDIA Isaac Lab 2.3…
A MANUS demonstration teleoperated a simulated 22-DoF Sharpa Wave inside NVIDIA Isaac Lab 2.3 and fed demonstrations into Isaac Lab Mimic. The relationship and configuration scope are limited to this named, dated programme.
Source - 2026-01-06 - Demonstration - Sharpa's North Robot Demonstrates Windmill Assembly at CES 2026
• Sharpa unveiled its full-body robot, North, at CES 2026 in Las Vegas. • North autonomously assembled over 300 paper windmills during the event, each requiring more than 30 consecutive manipulation steps. • The demonstrations highlighted North's dexterous manipulation capabilities and sustained precision over extended tasks.
Source - 2026-01-06 - Product Launch - Sharpa Robotics Introduces CraftNet VTLA Model for Fine Manipulation
Sharpa introduced CraftNet, a hierarchical vision-tactile-language-action model for fine manipulation. Its System 0 contact-control layer operates at about 100 Hz using tactile and force feedback. A CraftNet-powered North robot performed autonomous card dealing and paper-folding tasks at CES 2026.
Source
Relations
Relationships
- Unitree
Humanoid Hand/chassis Integration - NVIDIA’s Isaac GR00T reference humanoid design combines Sharpa Wave tactile five-finger hands with Unitree’s H2 humanoid chassis.
- CFB Group / Dairy Queen China
Live Food Service Deployment - Sharpa North makes and hands off Blizzards through a 55-step workflow using existing equipment at DQ's Wujiang Road store in Shanghai.
Context
Comparable profiles
- Proception AI
comparable profile - Dexterous Robot Hand Builder · Humanoid Dexterous Hand Platform
- Tesollo
comparable profile - Dexterous Robot Hand Builder · Humanoid Dexterous Hand Platform
- Wuxi Lingzhang Robotics
comparable profile - Dexterous Robot Hand Builder · Humanoid Dexterous Hand Platform
- Dexcel Robotics
comparable profile - Dexterous Robot Hand Builder
- Botyard Intelligence
comparable profile - Dexterous Robot Hand Builder
- Shadow Robot
comparable profile - Dexterous Robot Hand Builder
- AGILINK
comparable profile - Dexterous Robot Hand Builder
- Tangent Robotics
comparable profile - Dexterous Robot Hand Builder
- Wuji Tech
comparable profile - Dexterous Robot Hand Builder
- PSYONIC
comparable profile - Dexterous Robot Hand Builder
- Alt-Bionics, Inc.
comparable profile - Dexterous Robot Hand Builder
- Xynova
comparable profile - Dexterous Robot Hand Builder
Shared workflows
- RealMan Intelligent Technology (Beijing) Co., Ltd.
workflow adjacency - Humanoid Dexterity Builder
- VinMotion
workflow adjacency - Embodied Robot Development
- GigaAI
workflow adjacency - Embodied Robot Development
- Simple AI / 深朴智能
workflow adjacency - Embodied Robot Development
- Yuanqi Innovation / 元启创新
workflow adjacency - Embodied Robot Development
- Wonik Robotics
workflow adjacency - Dexterous In Hand Manipulation
Context tags
- Dexterous robot hand builder - Peer Group - Canonical exact-product evidence: Sharpa Wave. Source: https://www.sharpa.com/pages/wave
- Humanoid robot control stack - Stack Layer - Sharpa builds humanoid robot control software and development tooling.
- Humanoid dexterous hand platform - Peer Group - Sharpa provides humanoid dexterous hand platforms.
- Humanoid VLA control - Workflow - Sharpa enables VLA-based humanoid control.
- Embodied robot development - Workflow - Sharpa supports embodied robot development.
- Humanoid dexterity builder - Workflow - Sharpa focuses on humanoid dexterity and manipulation.
- Tactile dexterous hand control - Capability - Sharpa supports tactile dexterous hand control.
- Robot-learning infrastructure stack - Stack Layer - Sharpa supports robot learning infrastructure.
- Humanoid robot development labs - Customer Environment - Sharpa serves humanoid robot development labs.
- Dexterous in-hand manipulation - Workflow - Sharpa supports in-hand dexterous manipulation.